
The Phenomenon of Micro-Interference in Autonomous Flight Systems
In the intricate world of advanced drone technology, where precision, reliability, and autonomy are paramount, engineers and operators constantly grapple with an array of complex challenges. Among these, a subtle yet potentially disruptive phenomenon known as “chalazion” has garnered increasing attention. In the context of flight technology, a chalazion refers to a localized, often intermittent, and typically minor deviation or impedance within a drone’s sensor data, control algorithms, or electro-mechanical systems. Unlike overt malfunctions or catastrophic failures, a chalazion manifests as a gradual drift, a momentary stutter, or a slight inconsistency that, while not immediately critical, can accumulate or exacerbate over time, leading to degraded performance, reduced accuracy, or unpredictable behavior.
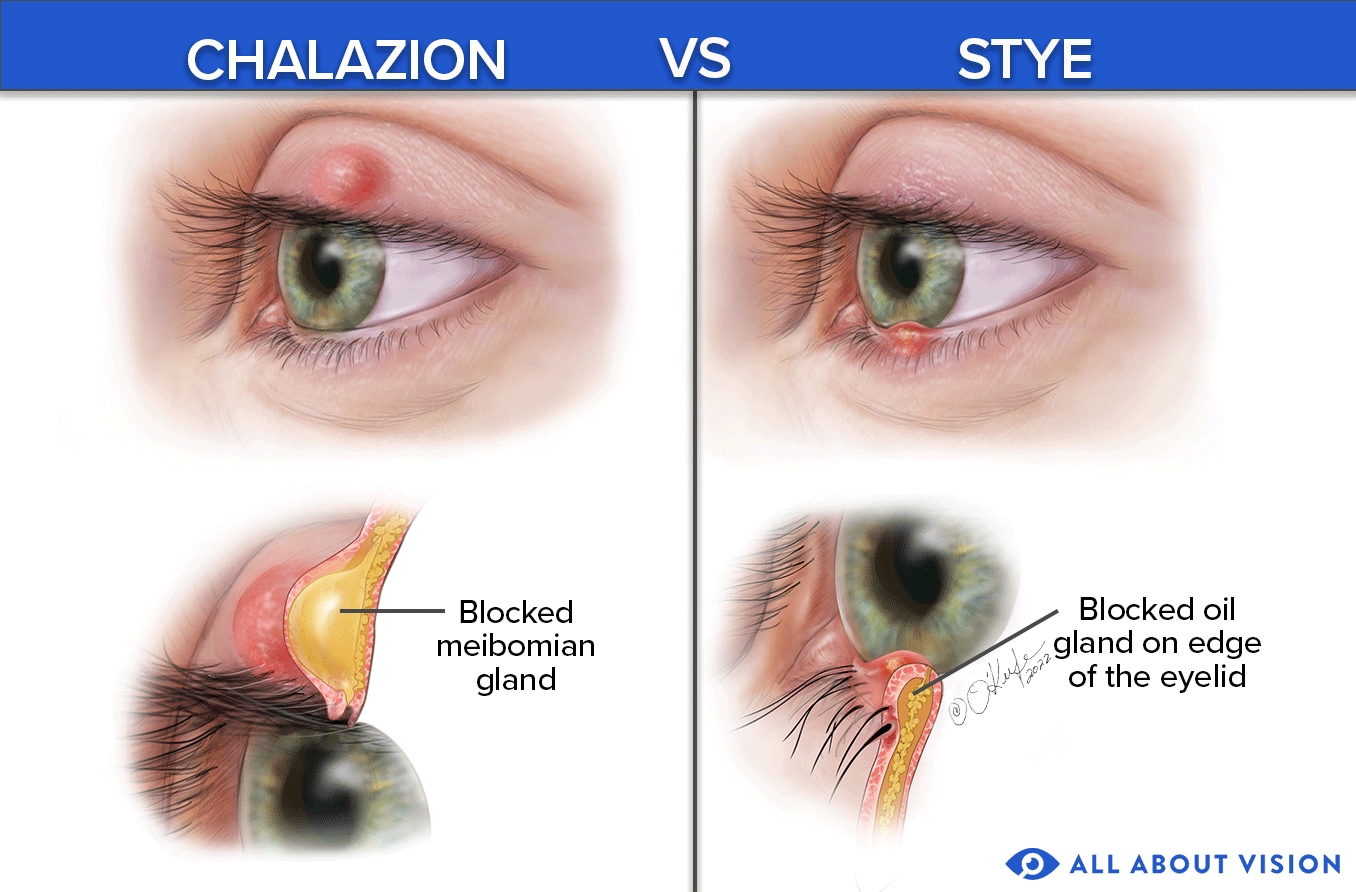
This concept draws a parallel to its namesake in medical science, signifying a small, localized issue that might seem benign initially but can cause discomfort or functional impairment if neglected. In drone flight technology, a chalazion might originate from various sources: minuscule electromagnetic interference affecting a magnetometer, transient data packet loss impacting GPS updates, or microscopic wear in a gimbal bearing introducing imperceptible wobble. The challenge lies in its elusive nature – it is often difficult to detect through standard diagnostics and may only become apparent under specific operational loads or environmental conditions. Understanding and addressing chalazion events is critical for maintaining the integrity and reliability of autonomous flight, particularly in missions demanding high precision, such as mapping, inspection, or delivery.
Understanding Latent Sensor Drift
One of the most common manifestations of a chalazion in flight technology is latent sensor drift. Modern drones rely on an array of sophisticated sensors—Inertial Measurement Units (IMUs) comprising accelerometers and gyroscopes, magnetometers, barometers, and GPS modules—to maintain stable flight and accurate navigation. These sensors, while robust, are susceptible to subtle, uncommanded deviations in their readings over time or due to environmental factors. Latent sensor drift represents a chalazion in its purest form: a gradual, often non-linear change in sensor output that doesn’t correspond to actual physical motion or environmental conditions.
For instance, an IMU’s gyroscope might slowly begin to report a constant, minute rotational velocity even when the drone is stationary, or a magnetometer might show a consistent bias influenced by residual magnetism in nearby components. These drifts, individually small, can be amplified by integration in navigation algorithms. A barometric sensor might experience drift due to temperature fluctuations within the drone’s enclosure, leading to slight inaccuracies in altitude hold. The challenge with latent drift is its insidious nature; it might not trigger immediate error flags because the readings remain within acceptable, albeit shifted, operational parameters. However, over extended flight durations or across multiple missions, these accumulated errors can lead to significant positional inaccuracies, inefficient power consumption due to constant minor corrections, and ultimately, mission failure if not properly compensated for or recalibrated. Advanced flight controllers employ Kalman filters and other estimation algorithms to mitigate some drift, but an unaddressed chalazion can push these compensations beyond their effective limits.
Impact on Real-time Navigation and Positional Accuracy
The direct consequence of an unmanaged chalazion is a degradation in real-time navigation and positional accuracy. Drones execute complex flight paths, maintain precise altitudes, and hold specific positions using a fusion of data from multiple sensors. When one or more of these data streams are subtly corrupted by a chalazion, the drone’s onboard navigation system computes an increasingly erroneous understanding of its own state. For GPS-guided missions, a chalazion in the GPS receiver module—perhaps due to a weak signal lock or multipath interference in specific environments—could cause the reported position to oscillate or slowly wander, even if the drone is attempting to hold a static hover.
Similarly, an IMU chalazion can lead to “toilet bowl effect” in hover, where the drone slowly spirals rather than maintaining a fixed point, or cause the drone to drift unexpectedly during forward flight. In missions requiring centimeter-level accuracy, such as photogrammetry for 3D modeling or precision agriculture, even a small chalazion can render collected data unusable, requiring costly re-flights. For autonomous delivery drones, precise landing capabilities are critical, and a chalazion affecting altitude or lateral positioning sensors could lead to missed targets or unsafe landings. The overall impact extends beyond mere inconvenience, potentially encompassing operational safety risks, increased wear on motors and ESCs due to excessive corrective actions, and a reduced confidence in the drone’s autonomous capabilities. Preventing and resolving these micro-interferences is thus paramount for the evolution and widespread adoption of autonomous aerial systems.
Detection and Diagnostic Methodologies for Chalazion Events
Detecting chalazion events before they escalate into significant operational issues is a cornerstone of proactive drone maintenance and flight safety. Given their subtle and often intermittent nature, specialized diagnostic approaches are essential, extending beyond routine pre-flight checks and standard telemetry monitoring. The focus shifts towards analyzing patterns, deviations from expected norms, and cross-referencing data from redundant systems to pinpoint these elusive anomalies.
Advanced Telemetry Analysis and Anomaly Detection
The first line of defense against chalazion events lies in advanced telemetry analysis. Modern drones continuously log vast amounts of flight data, including sensor readings, motor commands, GPS coordinates, battery status, and control inputs. Analyzing this rich dataset can reveal subtle chalazion patterns that might go unnoticed in real-time flight. Sophisticated data analytics platforms employ machine learning algorithms to establish baselines of normal operational parameters for specific drone models and mission types. These algorithms can then identify statistical outliers, correlations, or persistent micro-deviations that signify a chalazion.
For example, an AI-powered system might detect a minute, consistent increase in vibration frequency reported by an accelerometer under certain motor loads, suggesting a developing imbalance in a propeller or motor bearing – a mechanical chalazion. Similarly, subtle inconsistencies in GPS position fixes during stationary periods, or a slight divergence between accelerometer and barometer-derived altitude estimates, could flag an incipient sensor chalazion. Visualizing telemetry data through specialized tools can also highlight these phenomena, making trends and anomalies more apparent to human operators. The key is to move beyond simple threshold alarms and towards a more nuanced, predictive analysis that can identify problems before they manifest as critical failures.
Predictive Maintenance and Pre-flight Calibrations
Predictive maintenance strategies are inherently designed to counter chalazion events. Instead of replacing components on a fixed schedule or after failure, predictive maintenance leverages data analytics to anticipate when a component might start exhibiting chalazion-like behavior and recommends intervention beforehand. This could involve periodic, rigorous calibration of all flight-critical sensors. For instance, an IMU might require recalibration to nullify accumulated drift, or a compass might need re-calibration to compensate for changes in the drone’s magnetic environment or the installation of new accessories.
Pre-flight calibrations are fundamental to mitigating the immediate impact of chalazion. Before each mission, especially those requiring high precision, a comprehensive calibration routine should be performed. This includes:
- IMU Calibration: Ensuring accelerometers and gyroscopes provide accurate readings across all axes.
- Compass Calibration: Correcting for magnetic interference to ensure accurate heading.
- Barometer Calibration: Setting a precise home altitude reference.
- Gimbal Calibration: Removing any mechanical biases or initial drift in camera stabilization.
While these calibrations do not address the root cause of a chalazion, they reset the system’s baseline, effectively clearing any accumulated micro-errors and providing a fresh start for the flight. Regular, scheduled maintenance checks also involve physical inspections for micro-cracks in frames, subtle loose connections, or slight propeller imbalances that could contribute to chalazion. By combining advanced telemetry analysis with disciplined predictive and preventative maintenance, operators can significantly reduce the incidence and impact of these subtle flight system anomalies.
Mitigation Strategies and Future-Proofing Flight Integrity
Addressing chalazion events is not merely about detection but about implementing robust mitigation strategies that enhance the overall resilience and integrity of drone flight systems. These strategies range from architectural design choices to advanced software algorithms, all aimed at minimizing the impact of subtle errors and ensuring consistent, reliable performance.
Redundancy in Sensor Architectures
One of the most effective strategies for mitigating chalazion is the implementation of redundancy in sensor architectures. Instead of relying on a single sensor for critical data, drones with redundant systems incorporate multiple identical or complementary sensors. If one sensor begins to exhibit chalazion-like behavior—such as intermittent drift or minor data inconsistencies—its readings can be cross-referenced and validated against those from its redundant counterparts.
For example, many professional drones feature dual IMUs or GPS modules. If one IMU shows a slight drift, the flight controller can compare its output with the secondary IMU. Discrepancies can then be resolved through voting algorithms, Kalman filters that prioritize the most consistent data, or even by temporarily isolating the compromised sensor if the deviation is significant. Similarly, combining GPS with other navigation aids like GLONASS, Galileo, or even visual odometry cameras provides a more robust positional estimate, making the overall navigation system less susceptible to a chalazion in any single component. This architectural redundancy ensures that a subtle anomaly in one part of the system doesn’t compromise the entire flight, providing an essential layer of fault tolerance and data integrity. While adding complexity and cost, the enhanced reliability and safety often outweigh these drawbacks for critical applications.

Adaptive Control Algorithms and Self-Correction Protocols
Beyond hardware redundancy, advanced software solutions play a pivotal role in mitigating chalazion. Adaptive control algorithms are designed to continuously monitor the drone’s performance and adjust its control parameters in real-time to compensate for subtle changes or anomalies. These algorithms can detect deviations from expected flight dynamics—even those caused by a chalazion—and automatically tweak motor outputs, PID (Proportional-Integral-Derivative) loop gains, or navigation filter settings to maintain optimal performance.
For instance, if a chalazion causes a slight imbalance in a propeller, leading to increased vibration and minor instability, an adaptive control system might detect this and subtly adjust motor speeds to counteract the effect, maintaining a smoother flight. Similarly, if a barometer begins to drift, an adaptive system might integrate more heavily with other altitude sensors (like ultrasonic or lidar) or use a model-based prediction to maintain accurate altitude.
Self-correction protocols take this a step further by enabling the drone to perform internal diagnostic routines and re-calibration without human intervention. These protocols can:
- Auto-recalibration: Periodically trigger short, internal calibration sequences for sensors during stable flight segments.
- Data Fusion Optimization: Dynamically adjust the weighting of different sensor inputs in the navigation filter based on their real-time estimated accuracy. If a sensor shows signs of chalazion, its contribution to the overall solution might be temporarily reduced.
- Anomaly Reporting: Automatically flag potential chalazion events for post-flight analysis and maintenance scheduling, even if the flight itself was successfully completed due to adaptive compensation.
By integrating adaptive control algorithms with robust self-correction protocols, drone flight technology can effectively manage chalazion events, maintaining high levels of stability, accuracy, and reliability even in the face of subtle, evolving internal imperfections. This proactive approach is fundamental to the continued advancement and trustworthiness of autonomous aerial systems in increasingly demanding applications.