
The Quest for Micro-Adhesion in Autonomous Systems
The capabilities of unmanned aerial vehicles (UAVs) have expanded dramatically, yet a significant frontier remains in their ability to interact with complex environments beyond simple flight and observation. One critical challenge, metaphorically akin to understanding “what put on spider bite,” is the development of robust, reversible, and highly precise adhesion mechanisms. Just as a spider expertly navigates and secures itself to diverse surfaces, future drones require innovative solutions to perch, cling, and even manipulate objects in ways that defy conventional flight dynamics. This pursuit is not merely about landing; it’s about enabling drones to act as static observers, temporary communication relays, or even mobile repair units in environments unsuitable for continuous flight.
Bio-Inspired Grippers and Perching Mechanisms
The natural world offers a profound blueprint for solving complex engineering problems. Spiders, geckos, and insects possess extraordinary abilities to adhere to surfaces ranging from smooth glass to rough rock, often utilizing arrays of microscopic structures that generate powerful van der Waals forces, capillary action, or mechanical interlocks. Translating these biological marvels into drone technology involves designing grippers and perching mechanisms that can emulate such precision and strength.
Researchers are actively developing “bio-inspired” adhesion technologies for drones. These often involve arrays of microscopic polymer hairs, or “fibrillar adhesives,” designed to maximize contact area at the nanoscale. Unlike traditional suction cups, these dry adhesives maintain effectiveness across a wider range of temperatures and pressures, and critically, they are designed for reversible attachment without leaving residue. Early prototypes demonstrate drones equipped with such grippers capable of perching on vertical walls, undersides of beams, and even irregularly textured surfaces. This technology moves drones beyond transient observation, allowing them to conserve battery by switching to a static mode, conduct long-duration surveillance, or act as temporary anchors for sensor deployment in hard-to-reach locations. The essence of “what put on spider bite” here is the integration of these sophisticated, localized gripping technologies onto a mobile platform, transforming its operational paradigm.
Material Science for Enhanced Surface Interaction
Beyond mere gripping, the surface interaction capabilities of drones are being revolutionized by advancements in material science. The “what put on spider bite” question extends to coatings and intelligent skins that allow drones to subtly interact with their environment. These materials aren’t just for adhesion; they can provide improved friction, reduce wear, or even enable localized data collection.
Consider the development of smart materials that can change their adhesive properties on demand, perhaps through electrical signals or temperature variations. Electro-adhesion, for instance, uses electric fields to create temporary adhesive forces, offering precise control over attachment and detachment. This enables a drone to “bite” onto a surface with varying degrees of strength, suitable for delicate sampling or more robust anchoring.
Furthermore, advanced composites and metamaterials are being explored for structural components that can flex, adapt, or even self-heal localized damage, much like a living organism recovers from a minor injury. For a drone operating in challenging environments, a small impact or abrasion—a “spider bite” to its surface—could compromise its integrity. Novel self-healing polymers and coatings are designed to automatically repair minor cracks and punctures, extending the operational lifespan and reliability of the UAV without manual intervention. This innovation dramatically enhances drone resilience, allowing for sustained missions in environments where physical contact or minor impacts are unavoidable.
Precision Sensing and Localized Interaction
The ability to “put on spider bite” also extends to a drone’s capacity for highly localized, pinpoint sensing and interaction. Traditional drone sensors gather data from a broad area, but many critical applications demand intimate, precise interaction with specific points or surfaces. This necessitates a shift towards integrating micro-sensors and localized effectors that can mimic the nuanced, directed capabilities found in natural systems.
Mimicking Arachnid Sensory Acuity
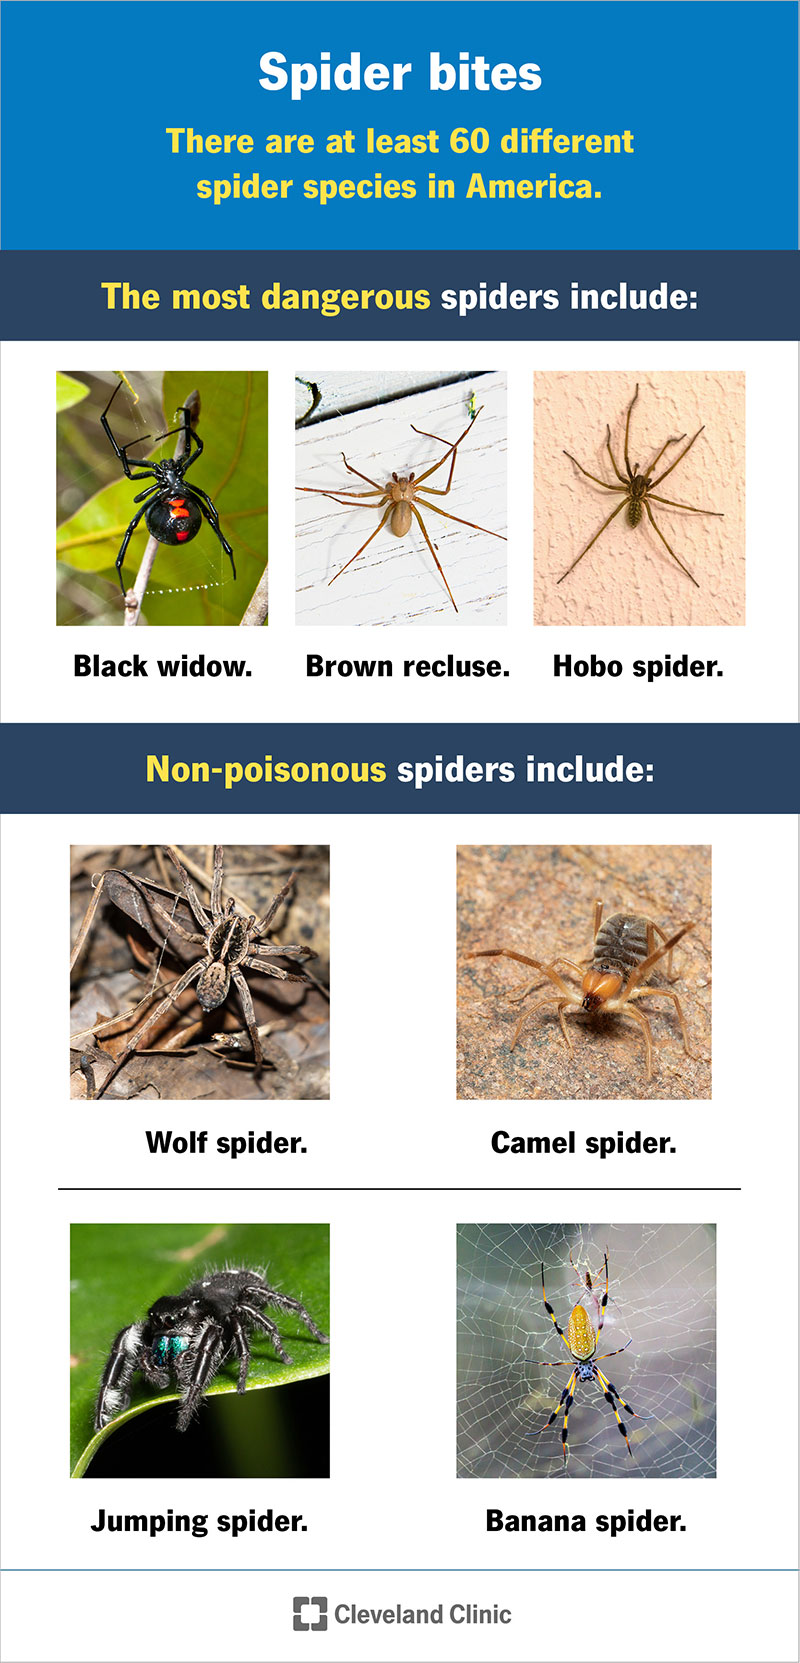
Spiders possess an exquisite array of sensory organs that allow them to detect subtle vibrations, chemical cues, and air currents with incredible precision. Translating this arachnid sensory acuity to drone technology involves developing highly localized and sensitive sensor arrays. Imagine a drone equipped with micro-electromechanical systems (MEMS) that can detect specific chemical residues on a surface, measure minute temperature variations at a contact point, or even sense structural integrity through localized acoustic feedback.
These “spider-bite” sensors could be integrated into landing gear, inspection probes, or manipulators, enabling drones to perform tasks requiring intimate contact. For environmental monitoring, a drone could perch on a plant leaf and use its localized sensors to analyze surface moisture, pest presence, or pollutant deposition with unprecedented detail. In infrastructure inspection, such sensors could detect micro-fractures in concrete or corrosion beneath paint layers by making direct, localized contact, providing data far more granular than visual inspection alone. This level of detail empowers drones to move beyond broad surveillance to highly targeted diagnostics and analysis, revealing hidden issues at a microscopic level.
Distributed Sensor Networks for Environmental Analysis
The concept of a “spider bite” can also represent a discrete data point within a larger network. Rather than a single drone acting as a monolithic data collector, future systems envision swarms of smaller, specialized drones, each capable of deploying or acting as a node in a distributed sensor network. Each drone, perhaps equipped with a bio-inspired micro-gripper, could “bite” onto a surface and become a temporary or semi-permanent sensor node.
Consider a scenario where a fleet of micro-drones is deployed to map a contaminated area. Each drone could carry a specific chemical sensor and, upon detecting a target contaminant, “perch” at that exact location, forming a localized sensor node. The collective “bites” of these drones would then create a highly detailed, real-time map of contaminant distribution. This distributed approach provides greater redundancy, scalability, and granularity compared to single-platform sensing. Moreover, the ability to latch onto various surfaces allows these temporary nodes to be placed optimally for data collection, overcoming line-of-sight or power limitations often faced by ground-based sensors.
Future Implications for Drone Autonomy and Versatility
The innovations encapsulated by “what put on spider bite”—from bio-inspired adhesion to precision micro-sensing—are foundational to the next generation of drone autonomy and versatility. These technologies move UAVs beyond predictable flight paths and remote observation, empowering them with a more intimate, tactile, and adaptive interaction with their environment.
Future drones will be capable of performing complex manipulation tasks, delicate sampling, and long-duration, power-efficient static observation. This will unlock applications in fields ranging from environmental science and precision agriculture to infrastructure maintenance and disaster response. Imagine drones that can not only identify a damaged solar panel but also perch on it to perform a localized repair, or micro-UAVs that can enter a collapsed building, cling to debris, and deploy micro-sensors for survivor detection.
The integration of advanced materials, bio-inspired robotics, and sophisticated AI algorithms will enable drones to autonomously assess a situation, choose the optimal “bite” (whether it’s an adhesive grip, a sensory probe, or a micro-manipulation), and execute it with precision. This represents a paradigm shift from drones as mere flying cameras to highly intelligent, multi-functional robotic agents capable of complex, localized interaction. Understanding “what put on spider bite” ultimately defines the critical technologies that will allow drones to seamlessly blend into, manipulate, and gather unprecedented insights from the physical world.