
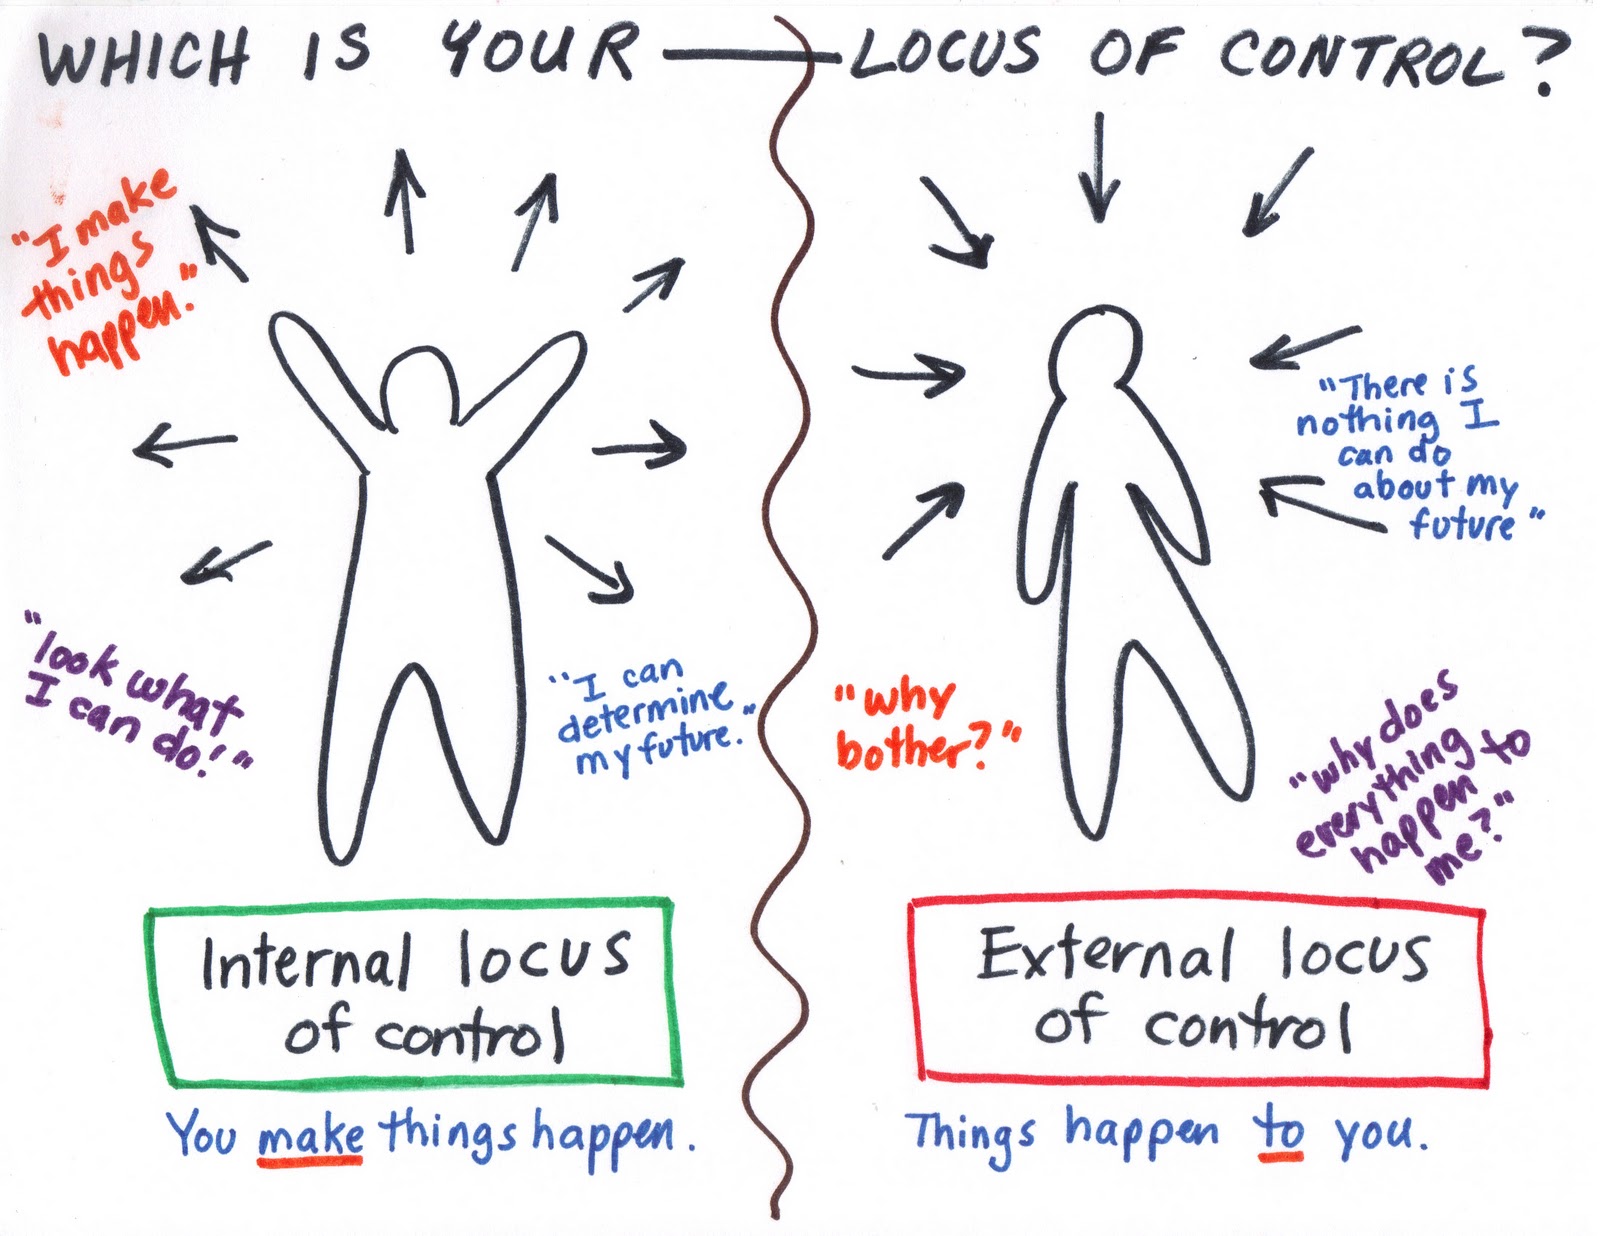
The psychological concept of “locus of control” typically refers to the degree to which individuals believe they have control over the outcomes of events in their lives. An internal locus of control suggests a belief in personal agency, while an external locus of control attributes outcomes to external forces like fate or luck. While traditionally applied to human psychology, this framework offers a powerful lens through which to examine the evolving landscape of advanced drone technology, particularly within the realm of Tech & Innovation. When discussing drones, the “locus of control” shifts from an individual’s psychological trait to the operational dynamics of intelligent systems: where does the primary decision-making authority and operational direction reside? Is it within the human pilot’s commands, the drone’s pre-programmed algorithms, an onboard AI, or a combination thereof? Understanding this distribution of control is fundamental to comprehending the capabilities, limitations, and future trajectory of autonomous flight and AI-driven drone applications.

Conceptualizing Locus of Control in Autonomous Systems
In the context of drone technology, the locus of control delineates the primary source of initiation and guidance for flight operations and mission execution. It’s not about the drone having a psychological belief, but about the architectural design and operational reality of who or what holds the reins. As drones transition from mere remote-controlled vehicles to increasingly intelligent, self-aware systems, this locus has become more complex and distributed.
Internal vs. External Control in Drone Operations
An external locus of control in drone operations traditionally rested firmly with the human pilot. Every stick input, every command to ascend, descend, yaw, or pitch originated from an external human operator. The drone acted primarily as an extension of the pilot’s will, executing explicit instructions without significant internal interpretation or autonomous decision-making. This paradigm characterizes early remote-controlled aircraft and many hobbyist drones today, where precise human input dictates almost every movement and action. The intelligence, problem-solving, and adaptive responses reside almost entirely outside the drone, within the pilot.
Conversely, an internal locus of control emerges as drones integrate more sophisticated onboard processing, sensors, and artificial intelligence. Here, the drone system itself takes on a significant, often primary, role in decision-making and execution. This internal control can manifest through pre-programmed flight paths, advanced navigation algorithms, real-time sensor fusion for obstacle avoidance, or sophisticated AI models designed for tasks like target tracking, environmental mapping, or autonomous inspection. In these scenarios, the drone is not merely reacting to external commands but is actively interpreting its environment, processing data, and making choices based on internal programming and learned behaviors. The shift towards internal control promises greater efficiency, precision, and the ability to operate in environments where constant human oversight is impractical or impossible.
The Spectrum of Autonomy and Control Delegation
The reality of modern drone operations rarely aligns perfectly with a purely internal or external locus of control; instead, it exists on a continuous spectrum of autonomy. This spectrum illustrates the gradual delegation of decision-making authority from human to machine:
- Human-in-the-Loop: The human pilot retains ultimate control and can intervene at any moment. While some functions might be automated (e.g., GPS hold), critical decisions still require human approval. This represents a strong external locus of control.
- Human-on-the-Loop: The drone system operates largely autonomously, but a human monitor oversees its performance and can intervene if necessary. The system takes initiative, but human supervision acts as a safety net. Here, the locus of control is shared, leaning towards internal for routine tasks but external for oversight.
- Human-out-of-the-Loop: The drone operates fully autonomously, making all decisions without human intervention after initial mission programming. This is the most profound shift towards an internal locus of control, where the system is designed to handle complex situations independently.
Understanding where a particular drone system lies on this spectrum is critical for defining operational protocols, safety measures, and regulatory frameworks.
AI-Driven Features and the Dynamic Locus of Control
The advent of Artificial Intelligence has dramatically reshaped the locus of control in drone technology, creating dynamic and often fluid distributions of agency between human and machine. AI empowers drones to move beyond simple automation to genuine autonomy, where systems can perceive, reason, and act in complex, unpredictable environments.
AI Follow Mode: Human Intent Meets Machine Execution
AI Follow Mode exemplifies a fascinating interplay of internal and external control. The human operator initially provides the “intent” – selecting a subject to follow. However, the execution of that intent, and all the micro-decisions involved, falls squarely within the drone’s internal AI. The drone’s algorithms take over, using computer vision and sensor data to:
- Identify and Track: Continuously recognize the target, even amidst distractions or changing backgrounds.
- Maintain Optimal Distance and Angle: Dynamically adjust its position relative to the subject, often incorporating cinematic principles for optimal framing.
- Navigate Obstacles: Autonomously detect and avoid trees, buildings, or other impediments in its flight path, all while maintaining tracking.
- Compensate for Movement: Adjust its speed and trajectory to match the subject’s movement, whether a person running, a car driving, or a boat sailing.
In this scenario, the initial high-level command (follow this subject) originates externally, but the complex, real-time control loop and tactical decision-making process are entirely internal to the drone’s AI. The locus of control is shared and dynamically distributed, with the AI interpreting and executing the higher-level human goal through its own internal processing capabilities.
Obstacle Avoidance and Reactive Autonomy
Sophisticated obstacle avoidance systems represent another compelling manifestation of an internal locus of control. Drones equipped with multi-directional vision sensors, LiDAR, or radar can autonomously detect objects in their path and take immediate, corrective action without direct human input. When a drone deviates from its planned trajectory to circumvent an unforeseen tree or building, the decision to alter course, and the precise maneuvers required, are generated and executed entirely by its internal software and hardware.
This “reactive autonomy” showcases an internal locus of control that prioritizes safety and mission success. While the overall mission parameters might have been externally set by a pilot, the immediate, critical decisions to prevent a collision are made by the drone’s onboard intelligence. This capability not only enhances safety but also enables drones to operate in more complex, dynamic environments, reducing the cognitive load on the pilot and allowing for more ambitious autonomous missions like inspection of complex industrial structures or navigating dense urban environments.
Operational Implications for Pilots and Systems
The shift in the locus of control, from entirely external to increasingly internal, carries significant implications for human pilots, system design, and the operational paradigms of drone technology. It necessitates new ways of thinking about human-machine interaction, trust, and responsibility.
Trust, Oversight, and Human-Machine Teaming
As the locus of control moves internally, the role of the human pilot evolves from direct manipulator to supervisor, monitor, and mission planner. This demands a high degree of trust in the autonomous system. Pilots must trust that the drone’s internal algorithms will perform reliably, make sound decisions, and operate safely. Building this trust requires transparent AI models, robust testing, and clear communication from the drone system about its status and intentions.
“Human-machine teaming” emerges as a critical operational concept. Rather than humans merely controlling machines, the emphasis shifts to collaboration, where both entities contribute unique strengths. The human provides strategic direction, ethical judgment, and adaptability to unforeseen circumstances, while the drone’s internal control excels at rapid data processing, precise execution, and tireless performance. This symbiotic relationship requires interfaces that allow humans to easily monitor system performance, understand its decision-making logic, and intervene effectively when necessary. The human becomes the ultimate arbiter, even if the daily tasks are handled by the machine.
Accountability and Decision-Making in Autonomous Flight
Perhaps the most profound implication of a shifting locus of control lies in the realm of accountability. When a human pilot is in full control, accountability for errors or incidents is clear. However, when a drone’s internal AI makes decisions that lead to an undesirable outcome (e.g., a collision during an autonomous flight, or failure to capture critical data), determining the locus of accountability becomes complex.
Questions arise: Is the programmer responsible for the algorithm’s flaws? The manufacturer for the system’s design? The operator for failing to adequately supervise? Or even the regulatory body for certifying the autonomous system? Addressing these questions is paramount for the widespread adoption of highly autonomous drone systems. It necessitates comprehensive regulatory frameworks, clear legal definitions of responsibility, and robust incident investigation protocols that can trace the decision path back to its source, whether internal (AI algorithm) or external (human input). This challenge underscores the need for ethical AI design and transparent system architectures that allow for post-event analysis and learning.
Future Trajectories: Evolving Locus of Control
The journey towards greater autonomy and internal control in drone technology is ongoing. Future developments will continue to push the boundaries of what these systems can achieve independently, further blurring the lines of control and demanding innovative approaches to design, regulation, and human interaction.
Self-Learning Systems and Adaptive Control
The next evolution of internal locus of control will come from self-learning systems, particularly those incorporating machine learning and reinforcement learning. These drones will not only execute pre-programmed tasks but will also learn from their experiences, adapt to new environments, and refine their operational strategies over time. A drone performing long-term infrastructure inspection, for example, might autonomously learn optimal flight paths, identify emerging patterns of damage, and even predict maintenance needs, all through continuous data analysis and self-correction.
This adaptive control means the locus of control becomes even more deeply embedded within the drone’s dynamic, evolving intelligence. The initial human programmer provides the learning framework and objective functions, but the specific tactical decisions and refined operational behaviors are generated internally by the system’s ongoing learning process. This promises unprecedented efficiency and capability but also introduces new layers of complexity in understanding, verifying, and regulating system behavior.

Regulatory Frameworks and Human-Centric Design
As the locus of control increasingly shifts towards internal, autonomous systems, regulatory bodies worldwide are grappling with the challenges of safe integration. Establishing frameworks for certifying autonomous systems, defining operational limits, and ensuring public safety requires a deep understanding of how these systems make decisions and how humans interact with them. Regulations will need to evolve beyond traditional “pilot-in-command” models to accommodate shared and distributed control.
Simultaneously, human-centric design principles will become even more crucial. Even with a highly internal locus of control, human operators will remain vital for strategic oversight, emergency intervention, and ethical decision-making. Future drone systems must be designed with intuitive interfaces, clear communication protocols, and transparent decision-making processes to foster trust and enable effective human-machine collaboration. The goal is not to remove humans from the loop entirely, but to empower them to focus on higher-level tasks, leveraging the autonomous capabilities of drones to achieve previously unattainable feats.