
In the rapidly evolving landscape of Unmanned Aerial Vehicles (UAVs), commonly known as drones, terms like “starvation” might initially evoke thoughts of biological deprivation. However, within the intricate world of drone technology, particularly in the realm of Tech & Innovation, “starvation” takes on a crucial, entirely different meaning. It refers to a critical system state where a process, component, or resource within a drone is perpetually or repeatedly denied access to the resources it needs to function correctly, efficiently, or at all. This technical starvation can have profound implications for a drone’s performance, reliability, and especially its advanced capabilities, such as autonomous flight, AI-driven operations, mapping, and remote sensing. Understanding and mitigating starvation is paramount for developing robust and intelligent drone systems.

Understanding Resource Starvation in UAVs
Drones are complex integrated systems, comprising multiple sensors, processors, communication modules, and actuators, all vying for limited resources. When one critical element fails to receive adequate access to these shared resources, it enters a state of starvation. This can manifest in several key areas:
Computational Starvation
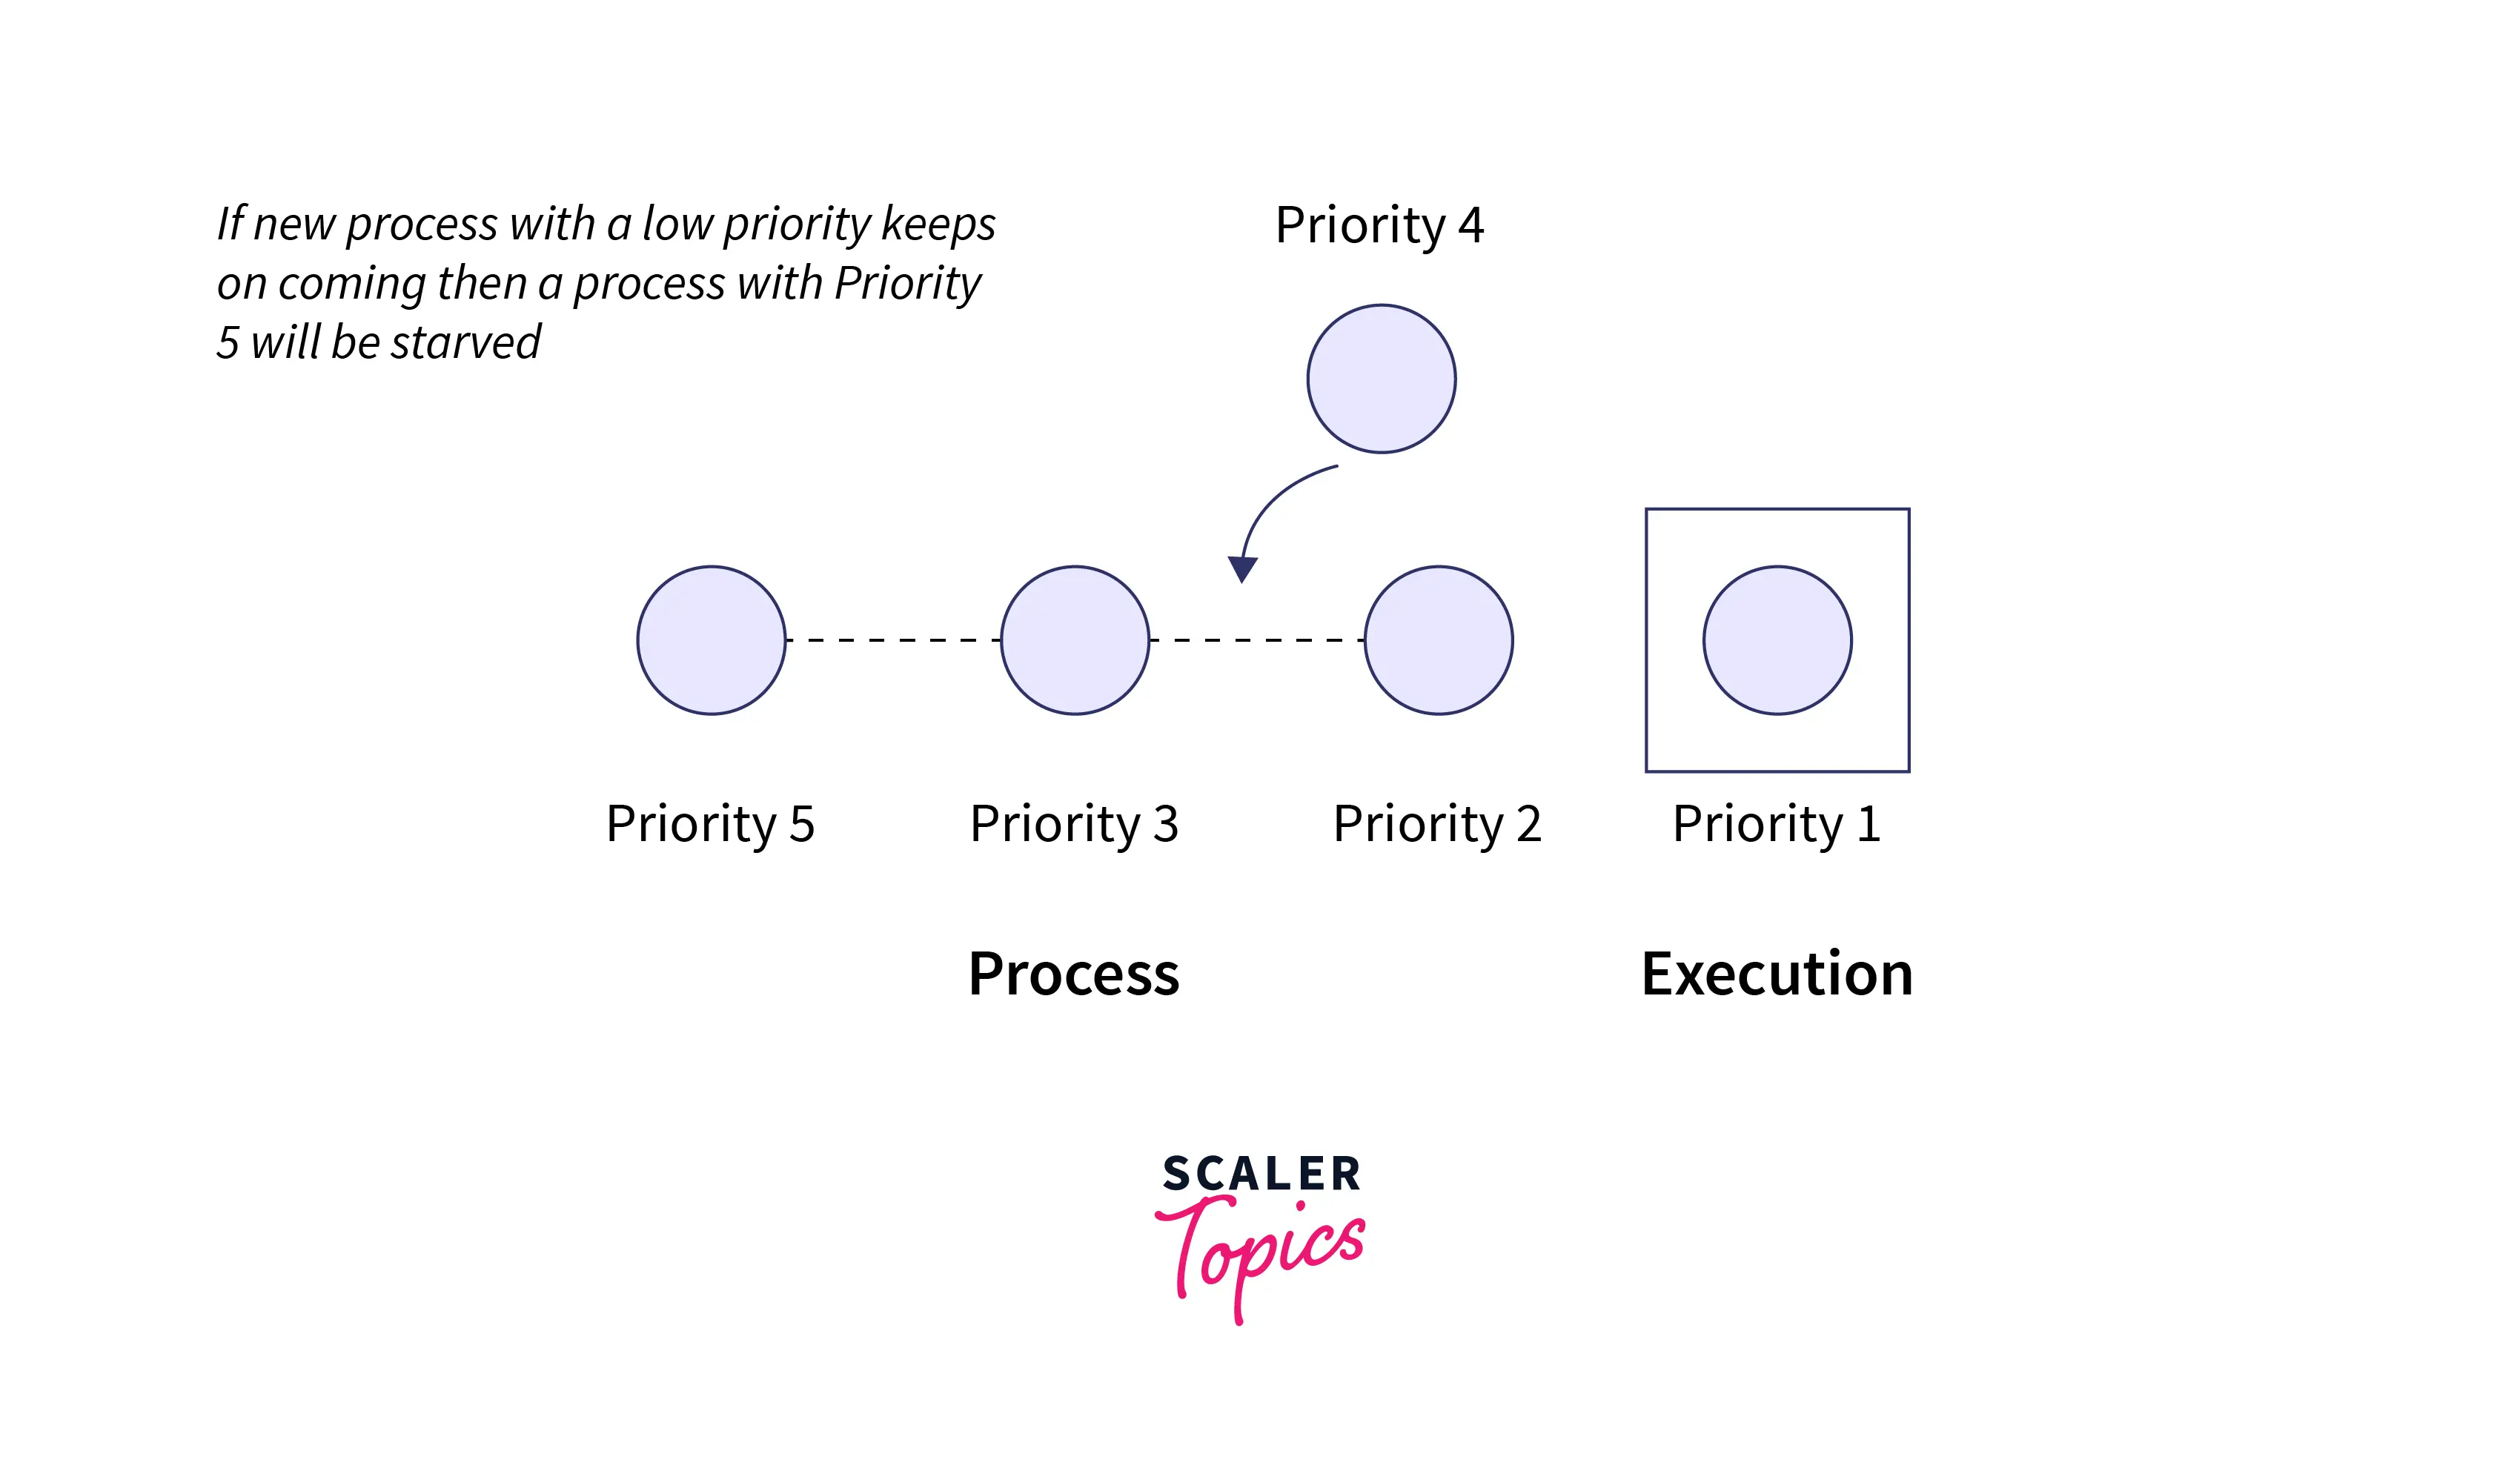
Modern drones, especially those leveraging AI for tasks like object recognition, obstacle avoidance, or sophisticated navigation, require significant computational power. A drone’s onboard flight controller and companion computers have finite processing units (CPUs, GPUs, FPGAs) and memory. Computational starvation occurs when a vital process, perhaps a real-time navigation algorithm or an AI inference engine, is consistently preempted or delayed by other, potentially less critical, tasks. For instance, if a high-priority video encoding task consumes an excessive amount of CPU cycles, the flight stabilization algorithm might not get its necessary share, leading to instability or even a crash. Similarly, memory-intensive operations can exhaust available RAM, forcing other processes to slow down or fail due to insufficient working space. In autonomous operations, where split-second decisions are often required, even minor computational delays caused by starvation can result in mission failure or hazardous situations.
Data and Bandwidth Starvation
Drones are data-centric machines. They constantly acquire data from numerous sensors (GPS, IMUs, LiDAR, cameras, thermal imagers), process it, and often transmit it to ground stations or other airborne units. Data and bandwidth starvation manifest when a component cannot send or receive the necessary amount of data within a given timeframe. This can occur due to:
- Bus contention: Multiple sensors or peripherals trying to communicate simultaneously over a shared data bus (e.g., I2C, SPI, CAN) can lead to delays for some components.
- Network congestion: In drones that rely on wireless communication for telemetry, command and control, or payload data transmission, a saturated wireless channel can starve critical control packets or live video feeds. This is particularly problematic for FPV (First Person View) systems where low latency is crucial.
- Sensor data backlog: If a high-resolution camera generates data faster than the onboard processor can handle or store it, frames might be dropped, or sensor readings delayed, leading to incomplete or outdated situational awareness. For mapping or remote sensing missions, this can result in gaps in data collection or inaccurate maps.
Power Starvation
Batteries are the lifeblood of most drones, and efficient power distribution is critical. Power starvation occurs when a specific component or subsystem doesn’t receive the stable and sufficient electrical power it requires. This might not mean a complete power cut, but rather voltage sags, current limitations, or intermittent supply issues. For example, if a high-draw payload (like a powerful gimbal camera or a LiDAR scanner) suddenly activates, it could temporarily pull too much current, starving other sensitive components like the flight controller’s microprocessors, potentially causing brownouts, reboots, or erratic behavior. Poor power management, faulty wiring, or inadequate power conditioning can all contribute to power starvation, leading to unpredictable system shutdowns or malfunctions in crucial electronic modules.
Implications for Drone Performance and Reliability
The ramifications of starvation extend far beyond mere inconvenience; they directly impact a drone’s operational capabilities and safety, especially as drones become more autonomous and undertake more complex missions.
Degraded Autonomy and Navigation
Autonomous flight relies heavily on timely and accurate data from GPS, IMUs, barometers, and vision systems, processed by sophisticated algorithms. Computational or data starvation can severely impair these functions. If the navigation system is starved of processor cycles, it might fail to update the drone’s position and velocity estimates quickly enough, leading to drift, inaccurate path following, or even loss of control. Obstacle avoidance systems, which often demand real-time processing of sensor data, become ineffective if starved, increasing the risk of collisions. AI Follow Mode, a key innovation, requires continuous, low-latency processing of visual data; starvation here can lead to jerky movements, loss of target, or a complete failure to track.
Sensor and Payload Malfunctions
Drones are often equipped with specialized payloads for various applications. Thermal cameras, multi-spectral sensors, or advanced optical zoom lenses require dedicated resources for data acquisition, processing, and storage. Starvation can manifest as:
- Data corruption or loss: Incomplete sensor readings or dropped frames for imaging payloads.
- Reduced performance: A thermal camera might operate at a lower refresh rate, or an optical zoom lens might respond slowly.
- Complete failure: A sensor might cease to function if its power supply or data link is consistently interrupted.
- Inaccurate data: For scientific remote sensing or precision agriculture, even minor delays in sensor data processing can lead to misinterpretation of environmental conditions.
Communication Loss
The command and control link is fundamental for safe drone operation. Starvation of bandwidth on the communication channel can lead to delayed command reception, lost telemetry data, or a complete loss of signal (LoS). In Beyond Visual Line of Sight (BVLOS) operations, where the drone relies entirely on radio communication, a starved link can be catastrophic. Live FPV feeds, essential for many advanced maneuvers and inspections, become laggy or pixelated under bandwidth starvation, making precise control impossible and increasing the risk of accidents.
Mitigating Starvation: Strategies for Robust Drone Design
Addressing starvation requires a holistic approach to drone system architecture, focusing on intelligent resource management and robust engineering practices.
Intelligent Resource Scheduling
At the core of preventing computational and data starvation lies sophisticated operating system design and intelligent resource schedulers. These systems prioritize critical tasks (e.g., flight control, emergency protocols) over less urgent ones (e.g., data logging, auxiliary sensor calibration). Real-time operating systems (RTOS) are often employed in flight controllers to guarantee execution times for critical processes. Techniques like dynamic frequency scaling for processors, smart buffer management for data streams, and quality-of-service (QoS) protocols for network communications ensure that essential functions always receive the necessary share of resources, even under heavy load. Future innovations in this area include AI-driven resource managers that can predict system demands and dynamically reallocate resources based on mission profiles and environmental conditions.
Redundancy and Prioritization
Implementing redundancy for critical components and communication links can provide a fallback in case one resource pathway becomes starved. For example, dual IMUs or redundant communication channels ensure that if one fails or is overwhelmed, another can take over. Beyond hardware, careful software design involves prioritizing tasks and data streams. Critical flight control commands or essential sensor data should always have higher priority than non-essential data, ensuring that in resource-constrained situations, vital operations continue uninterrupted. This includes robust error handling and fail-safe mechanisms that can gracefully degrade performance or initiate an emergency landing rather than catastrophic failure.
Advanced Power Management
Preventing power starvation requires meticulous electrical engineering. This includes designing power distribution units (PDUs) with sufficient current capacity, using robust voltage regulators to ensure stable power delivery to sensitive electronics, and implementing intelligent power management systems. These systems can monitor the power draw of various components, dynamically adjust power allocation, and even temporarily disable non-essential payloads if the overall system power budget is exceeded or battery levels drop critically low. Future innovations might include energy harvesting technologies or more efficient battery chemistries, but active power management remains crucial for reliable operation.
The Future of Starvation-Resistant Drones
As drones become more sophisticated, integrating advanced AI, swarming capabilities, and operating in increasingly complex environments, the challenge of preventing starvation will only grow. The future of starvation-resistant drones lies in tightly integrated hardware-software co-design, where resource constraints are considered from the ground up. This involves:
- Distributed computing architectures: Distributing processing loads across multiple, specialized computing units rather than relying on a single central processor.
- Edge AI optimization: Developing highly efficient AI models that can run on resource-constrained onboard hardware, minimizing computational demands.
- Adaptive communication protocols: Networks that can dynamically adjust bandwidth allocation and data rates based on real-time needs and interference.
- Proactive resource monitoring: Systems that can detect early signs of resource contention and predict potential starvation scenarios before they impact performance.
By rigorously addressing computational, data, and power starvation, drone manufacturers and developers can unlock the full potential of these transformative flying machines, ensuring they operate with unprecedented reliability, autonomy, and safety in an ever-expanding array of applications.