
The rapid evolution of drone technology, particularly in areas like autonomous flight, AI-powered features, and advanced remote sensing, relies heavily on sophisticated mathematical models. At the heart of many such computational processes lies a fundamental concept from calculus: the Maclaurin series. Far from being a mere theoretical construct, the Maclaurin series provides a powerful tool for approximating complex functions with simpler polynomials, a capability critical for real-time operations and resource-constrained embedded systems inherent in modern drone innovation.
The Essence of Function Approximation
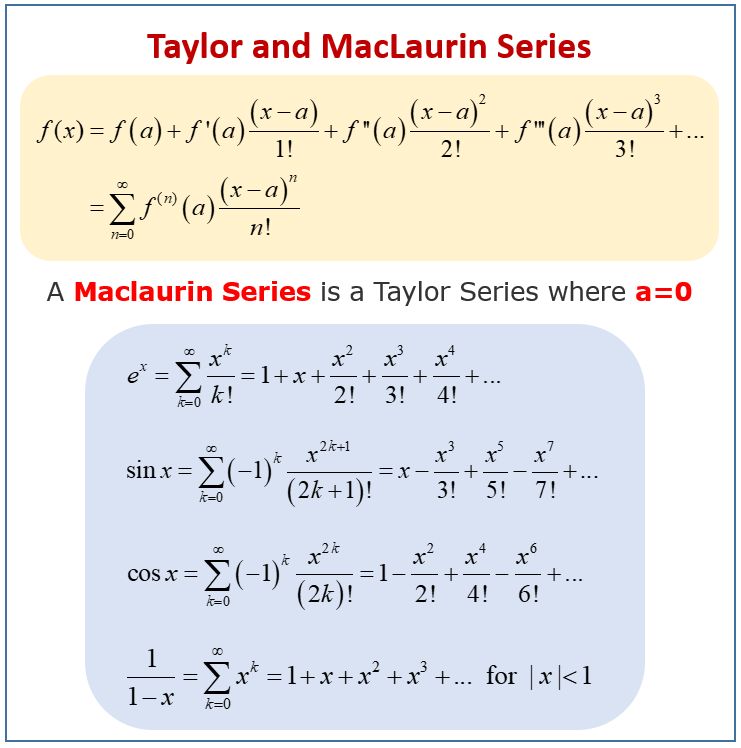
A Maclaurin series is a special case of a Taylor series, where a function is represented as an infinite sum of terms. Each term is calculated from the function’s derivatives at a single point, specifically zero for a Maclaurin series. Its primary purpose is to approximate complex, transcendental, or computationally intensive functions with simpler, more manageable polynomials. This approximation is particularly effective for inputs close to zero, offering a local yet highly accurate representation.

Mathematically, for a function $f(x)$ that is infinitely differentiable at $x = 0$, its Maclaurin series is given by:
$f(x) = f(0) + f'(0)x + frac{f”(0)}{2!}x^2 + frac{f”'(0)}{3!}x^3 + dots + frac{f^{(n)}(0)}{n!}x^n + dots$
Here, $f^{(n)}(0)$ denotes the $n$-th derivative of the function $f(x)$ evaluated at $x = 0$, and $n!$ is the factorial of $n$. By truncating this infinite series to a finite number of terms, we obtain a polynomial that can closely approximate the original function within a certain range. For example, approximating $e^x$ or $sin(x)$ with just a few polynomial terms can yield surprisingly accurate results, especially for small values of $x$. This ability to transform complex functional relationships into simpler polynomial expressions is invaluable for computational efficiency, particularly in systems where processing power and latency are critical considerations.
Maclaurin Series in Autonomous Flight Systems
Autonomous drones navigate, stabilize, and react to their environment in real-time, demanding highly efficient and accurate mathematical computations. The application of Maclaurin series plays a crucial role in making this possible within the confines of on-board processing power.
Real-time Computation and Embedded Systems
Drone flight controllers and navigation units are typically powered by embedded systems with finite computational resources. Complex functions describing aerodynamic forces, sensor characteristics, or environmental interactions are often non-linear and computationally expensive to evaluate precisely. Here, Maclaurin series provide a method to approximate these functions with polynomials. Evaluating polynomials involves only basic arithmetic operations (addition, multiplication), which are significantly faster than calculating transcendental functions (like sines, cosines, exponentials) or performing numerical integrations. This speed-up is essential for maintaining control loop frequencies, processing sensor data, and executing critical decisions within milliseconds, thereby ensuring stable and responsive flight.
Consider the dynamic models governing a drone’s flight. These models involve complex equations of motion that incorporate thrust, drag, lift, and torque. While full non-linear models offer the highest fidelity, they are too demanding for real-time control. By using Maclaurin series, these non-linear dynamics can be linearized or approximated around a specific operating point (e.g., hovering, forward flight). This allows control algorithms to operate on simpler, computationally cheaper models while still maintaining sufficient accuracy for effective flight control.
Control System Design and Optimization
Advanced drone control systems, such as Model Predictive Control (MPC) or Linear Quadratic Regulator (LQR), rely on predictive models of the drone’s behavior. These models often involve differential equations that describe the system’s response to control inputs. For highly non-linear systems, direct solution or real-time simulation can be infeasible.
Maclaurin series enable the linearization of these non-linear system dynamics around an equilibrium point. This transformation simplifies the control problem, allowing the application of well-established linear control theory and algorithms. For instance, in stabilizing a drone, controllers need to react to small deviations from a desired state. Approximating the relevant dynamics with a low-order Maclaurin polynomial around the current operating point provides a robust and computationally efficient way to calculate corrective control actions, contributing to the drone’s remarkable stability and responsiveness. Furthermore, in optimizing flight trajectories or minimizing energy consumption, cost functions or constraints might be non-linear. Approximating these with polynomial forms can make optimization problems solvable in real-time.
Enhancing AI and Machine Learning for Drones
The integration of Artificial Intelligence and Machine Learning (AI/ML) is transforming drone capabilities, from autonomous navigation to intelligent data analysis. Maclaurin series contribute to the efficiency and effectiveness of these advanced algorithms, particularly in areas requiring rapid computation and modeling.
Predictive Modeling and Trajectory Optimization
AI-powered autonomous flight often involves predictive modeling to anticipate future states, plan optimal paths, and avoid obstacles. Machine learning models, especially those operating on edge devices, require efficient processing. Complex relationships learned by neural networks or other AI models can sometimes be simplified or approximated using series expansions for faster inference.
For instance, in path planning for obstacle avoidance, a drone might need to evaluate multiple potential trajectories and select the optimal one based on safety, efficiency, and mission objectives. The mathematical functions describing the cost or feasibility of these paths (e.g., energy consumption, distance to obstacles, flight time) can be complex. Approximating these cost functions with Maclaurin polynomials allows for rapid evaluation and comparison, enabling the drone to make swift, informed decisions about its flight path in dynamic environments. This is particularly relevant for real-time trajectory re-planning when unexpected obstacles appear.
Sensor Data Interpretation and Fusion
Drones are equipped with an array of sensors—IMUs (accelerometers, gyroscopes), GPS, altimeters, vision sensors, LiDAR—each providing data that needs to be accurately interpreted and fused for a coherent understanding of the drone’s state and environment. The raw data from these sensors often needs processing, calibration, and noise reduction.
Sensor response curves, which map physical input to electrical output, are rarely perfectly linear. For example, an accelerometer’s output might drift or scale non-linearly with acceleration. To correct these non-linearities and achieve precise measurements, these response curves can be approximated using Maclaurin series. This allows for accurate sensor calibration and data conversion on-the-fly, essential for robust navigation and control. Furthermore, in sensor fusion algorithms like Kalman filters or Extended Kalman Filters (EKF), the system dynamics or measurement models might be non-linear. While EKFs use Taylor series expansions (a generalization of Maclaurin series) to linearize these models around an estimated state, the underlying principle of approximating complex functions with polynomials for real-time estimation is fundamentally similar. This enables the drone to accurately estimate its position, velocity, and orientation by integrating data from multiple noisy sensors.
Beyond Flight: Mapping and Remote Sensing Applications
The utility of Maclaurin series extends beyond real-time flight control into drone applications for mapping, surveying, and remote sensing, where precision and efficient data processing are paramount.
Geodetic Calculations and Mapping
In high-precision mapping and photogrammetry, drones collect imagery that is then processed to create detailed 2D maps and 3D models. Accurate geospatial positioning requires complex geodetic calculations that account for the Earth’s curvature, varying gravity fields, and map projections. Functions describing these phenomena can be highly complex.
For instance, converting between different geodetic coordinate systems or projecting Earth’s spherical surface onto a 2D map plane often involves intricate trigonometric and exponential functions. Maclaurin series can be employed to approximate these functions, enabling faster and more efficient computation during post-processing or even on-board for real-time geo-referencing. This efficiency is critical when processing vast datasets from large-area surveys, speeding up the generation of highly accurate maps and digital elevation models.
Signal Processing in Remote Sensing
Remote sensing drones capture data across various electromagnetic spectra, from visible light to thermal infrared. The analysis of this data often involves correcting for atmospheric effects, material properties, and sensor characteristics. These corrections are performed using mathematical models that can be computationally intensive.
Functions describing atmospheric attenuation, spectral reflectance of materials, or complex sensor signal transformations can be approximated using Maclaurin series. This allows for rapid and efficient application of correction algorithms, leading to clearer, more accurate, and more interpretable remote sensing data. For instance, in hyperspectral imaging, where hundreds of spectral bands are analyzed, efficiently processing each band’s data using series approximations can significantly reduce the time required to generate actionable insights for agriculture, environmental monitoring, or infrastructure inspection.
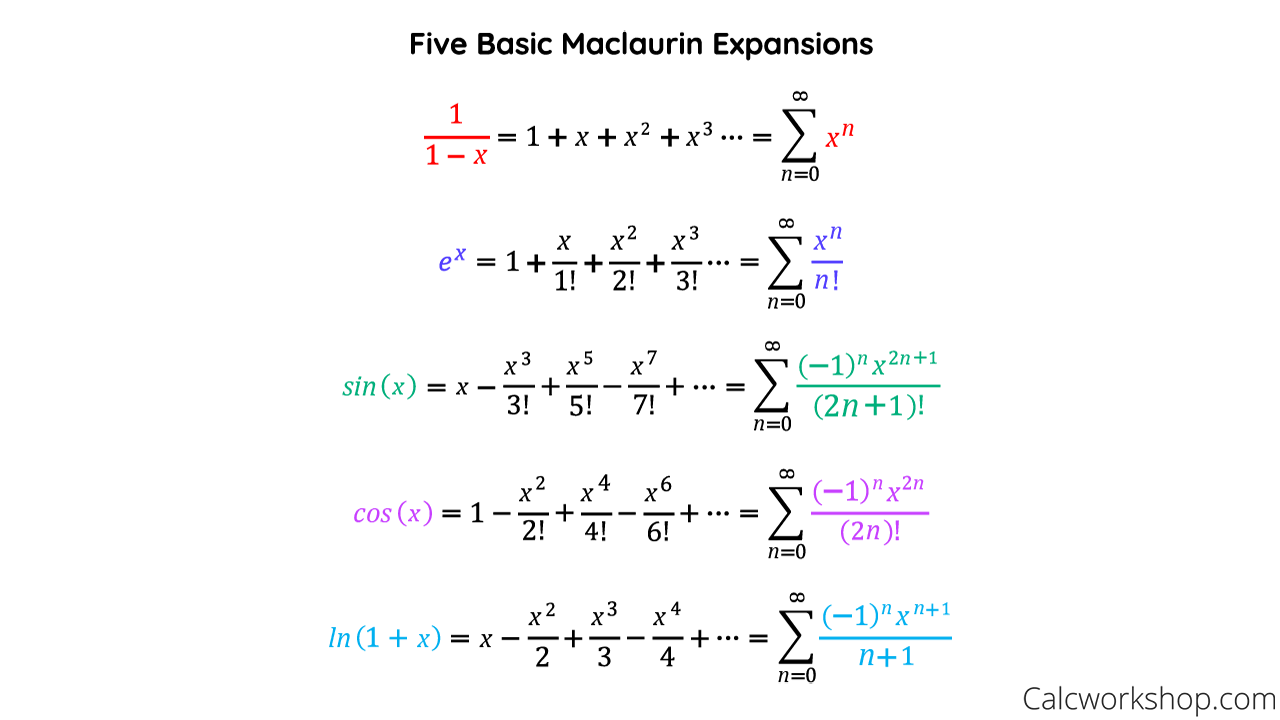
The Precision and Limitations of Polynomial Approximations
While Maclaurin series offer tremendous advantages in computational efficiency, understanding their precision and limitations is key to their effective application in drone technology. The accuracy of a polynomial approximation derived from a Maclaurin series depends directly on two main factors: the number of terms used and the distance of the input value from the expansion point (zero).
Using more terms in the series generally leads to a more accurate approximation over a wider range. However, this comes at the cost of increased computational load, which must be carefully balanced against the real-time processing demands of drone systems. For example, approximating $sin(x)$ with just the first two terms ($x – x^3/3!$) is reasonably accurate for very small $x$, but for larger angles, more terms are needed to maintain acceptable precision. Engineers developing drone software must judiciously select the appropriate number of terms based on the required accuracy for a specific task (e.g., flight stability vs. long-term trajectory prediction) and the available processing power.
Furthermore, Maclaurin series are most accurate near the point of expansion, which is $x=0$. As the input value moves further from zero, the accuracy of the approximation tends to decrease. This is where the more general Taylor series, which can be expanded around any point $a$, offers greater flexibility. However, for many drone applications, particularly those involving small deviations from a nominal operating point (e.g., small pitch/roll angles for stability, minor velocity adjustments), the Maclaurin series provides a perfectly adequate and computationally optimal solution. The “radius of convergence” defines the range over which the infinite series converges to the actual function. Outside this radius, the approximation may diverge entirely. Understanding this fundamental mathematical characteristic is crucial for ensuring the reliability and safety of drone operations that rely on these approximations.
In essence, the Maclaurin series stands as a testament to how fundamental mathematical concepts underpin the most advanced technological innovations. By enabling efficient and accurate function approximation, it empowers drones to achieve unprecedented levels of autonomy, precision, and intelligence.