
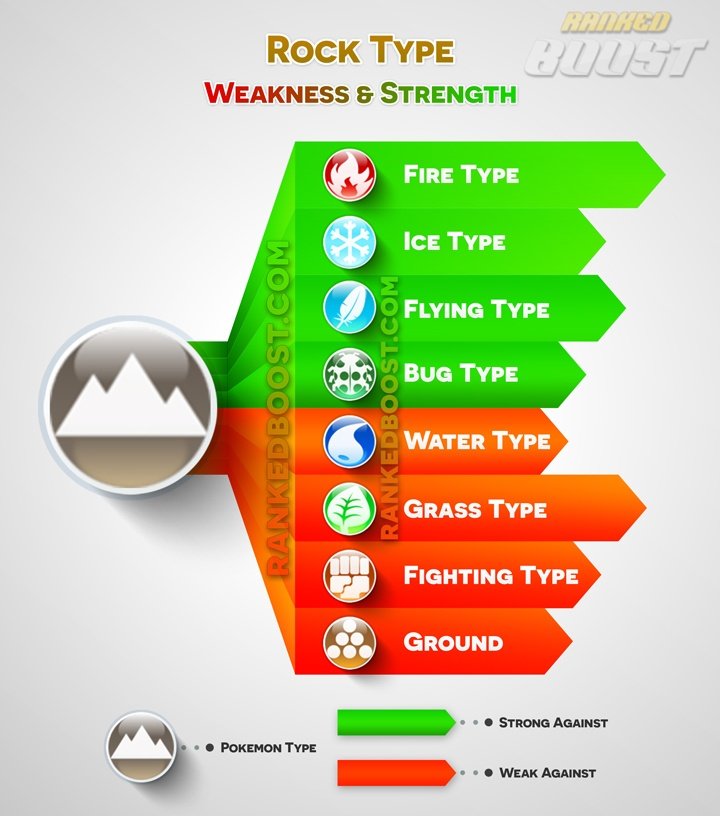
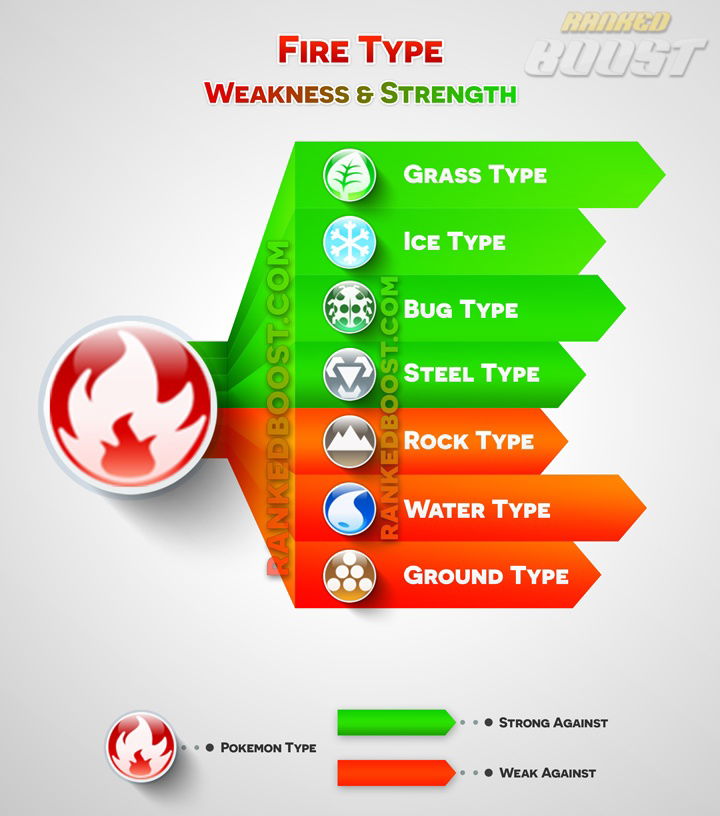
In the demanding world of drone operations, the phrase “what is strong against rock” transcends a simple literal interpretation. It speaks to a drone’s fundamental ability to navigate, operate, and survive in environments dominated by geological formations, from craggy cliff faces and mountainous regions to intricate cave systems and urban canyons. Such environments present significant challenges: unpredictable wind patterns, GPS signal degradation, intricate physical obstacles, and the constant threat of collision. To truly be “strong against rock,” a drone relies not on brute force, but on sophisticated flight technology – a convergence of sensors, processing power, and intelligent control systems designed to perceive, react, and adapt. This article delves into the core flight technologies that empower drones to overcome the formidable challenges posed by rocky and rugged terrain, ensuring mission success and operational safety.
The Imperative of Obstacle Avoidance in Rugged Terrain
Operating near rock formations presents an immediate and undeniable risk of collision. Whether it’s a sudden gust pushing a drone into a cliff face or a navigational error leading to impact with an unseen outcrop, the consequences can be catastrophic. Thus, sophisticated obstacle avoidance systems are the primary line of defense, making a drone “strong against rock” by proactively preventing contact.
Sensor Technologies for Proactive Detection
The foundation of any robust obstacle avoidance system lies in its sensor suite. Different technologies offer unique strengths, and often, their synergistic integration provides the most comprehensive environmental understanding:
- Vision-Based Systems (Stereo Cameras, Monocular Cameras): These systems mimic human sight, capturing visual data to construct 3D maps of the environment. Stereo cameras, with their two lenses, can calculate depth information by comparing disparities between images, much like human eyes. Monocular cameras, while requiring more advanced algorithms (like Structure from Motion or Visual SLAM), can also infer depth and detect obstacles. Their strength lies in identifying various object types, including irregularly shaped rocks, and operating effectively in well-lit conditions. However, performance can degrade in low light, fog, or against uniform textures.
- Ultrasonic Sensors: Emitting sound waves and measuring the time it takes for an echo to return, ultrasonic sensors are excellent for short-range obstacle detection, typically up to a few meters. They are lightweight, inexpensive, and perform well against many surfaces regardless of lighting. Their primary limitation is range and narrow field of view, making them unsuitable for wide-area scanning, but ideal for precise, close-proximity maneuvers near surfaces.
- LiDAR (Light Detection and Ranging): LiDAR systems emit laser pulses and measure the time of flight for each pulse to return after reflecting off an object. This generates highly accurate, dense 3D point clouds of the environment. LiDAR excels in complex, GPS-denied, or low-light conditions, providing precise distance measurements to every rock, tree, or structural element. It’s particularly strong for mapping intricate rocky terrains and enabling precise navigation close to surfaces. However, LiDAR units can be heavier and more expensive than other sensors.
- Radar (Radio Detection and Ranging): Similar to LiDAR but using radio waves, radar can penetrate fog, smoke, and heavy rain more effectively than optical sensors. It’s excellent for longer-range detection, though typically offers lower resolution than LiDAR for environmental mapping. Miniaturized drone radar systems are increasingly being explored for robust all-weather obstacle avoidance, particularly relevant for expansive outdoor operations near large rock formations where visibility might be compromised.
Real-time Path Planning and Rerouting
Raw sensor data is only half the battle. To be “strong against rock,” a drone needs the intelligence to process this data in real-time and dynamically adjust its flight path. Advanced flight controllers utilize sophisticated algorithms to:
- Construct Environmental Maps: Fusing data from multiple sensors to create a continuous, updated 3D model of the surrounding space, highlighting obstacles and free-flight zones.
- Predict Obstacle Trajectories: For dynamic obstacles (though less common with static rocks, crucial in mixed environments), the system can predict their movement.
- Generate Safe Flight Paths: Based on the environmental map, the drone’s processor calculates the optimal, safest path to its next waypoint, avoiding all detected obstacles.
- Execute Dynamic Rerouting: If an unexpected obstacle appears or the environment changes, the system can instantly calculate and execute a new, safe trajectory, veering away from impact points. This dynamic capability is crucial when operating in unpredictable airflows or when navigating through narrow gaps in rock formations.
Integration with Autonomous Flight Systems
The pinnacle of obstacle avoidance is its seamless integration with autonomous flight. AI and machine learning algorithms interpret sensor data with unprecedented speed and accuracy, enabling:
- Intelligent Decision-Making: Rather than merely avoiding, autonomous systems can make more complex decisions, like choosing the best alternative path, identifying potential inspection points on a rock face, or maintaining a specified standoff distance.
- Predictive Avoidance: Advanced algorithms can analyze the drone’s current trajectory and speed, predicting potential future collisions and initiating avoidance maneuvers well in advance, providing smoother and safer flight.
- Adaptive Flight: The drone can learn from its environment, optimizing its avoidance strategies over time for particular types of terrain or obstacles.
Precision Navigation for Complex Environments
Beyond avoiding immediate collision, effective operation in rocky terrain demands a drone’s absolute certainty of its position and orientation. Precision navigation systems are essential for detailed mapping, inspection, and safe return, especially when visual line of sight might be obscured.
GNSS and RTK/PPK for Sub-Centimeter Accuracy
Standard GPS (Global Navigation Satellite System) offers accuracy within a few meters, which can be insufficient for missions requiring close proximity to structures or high-resolution data acquisition.
- RTK (Real-Time Kinematic): This technology uses a base station (on the ground) and a rover (on the drone) to correct GPS signal errors in real-time. By comparing the phase of the satellite signals received by both units, RTK can achieve horizontal accuracy down to 1-3 centimeters, even vertically, crucial for knowing the drone’s precise height relative to a cliff edge.
- PPK (Post-Processed Kinematic): Similar to RTK, PPK records raw GNSS data on the drone and processes it after the flight using data from a nearby base station. This method often yields slightly better accuracy than RTK and is more resilient to momentary signal interruptions during flight, making it ideal for large-scale mapping projects over rugged terrain where continuous real-time correction might be challenging.
These technologies enable drones to execute highly precise flight paths, repeatedly fly the same trajectory for change detection, and accurately geotag acquired data, which is invaluable for geological surveys, construction monitoring, or search and rescue in mountainous regions.
Visual SLAM and Optical Flow
While GNSS-based systems excel outdoors, they are often compromised or unavailable in GPS-denied environments like caves, under dense canopy, or within deep canyons – all common scenarios associated with “rock.”
- Visual SLAM (Simultaneous Localization and Mapping): Utilizing onboard cameras, SLAM algorithms build a map of the environment while simultaneously tracking the drone’s position within that map. As the drone flies, it identifies unique visual features (corners, textures, edges of rocks) and uses these to triangulate its position and refine the map. This allows for robust navigation even without satellite signals, essential for exploring rock shelters or inspecting intricate rock faces up close.
- Optical Flow: A simpler vision-based technique, optical flow sensors measure the movement of ground features beneath the drone. This provides precise velocity information and helps the drone maintain position relative to the ground, especially useful for hovering steadily during inspections of rock formations or landing accurately on uneven surfaces.
Inertial Measurement Units (IMUs) and Magnetometers
These are foundational components for all modern flight control systems, providing the core data for orientation and movement:

- IMUs: Comprising accelerometers and gyroscopes, IMUs measure the drone’s linear acceleration and angular velocity in three dimensions. This data is critical for determining the drone’s attitude (roll, pitch, yaw) and detecting any unintended movements. In turbulent air near rock formations, IMU data is vital for rapid stabilization.
- Magnetometers: These sensors act as digital compasses, providing heading information by detecting the Earth’s magnetic field. While susceptible to magnetic interference from certain rock types or power lines, they are crucial for maintaining directional stability and preventing disorientation, especially during long-range flights or when operating beyond visual line of sight.
Enhanced Stabilization and Control in Challenging Airflows
Rocky landscapes are notorious for generating complex and often violent airflows. Updrafts, downdrafts, wind shear, and turbulence caused by air interacting with uneven terrain can easily destabilize a drone. To be “strong against rock,” a drone must possess exceptional stability and control.
Advanced Flight Controllers and PID Tuning
The “brain” of the drone, the flight controller, runs sophisticated algorithms to interpret sensor data (from IMUs, GPS, etc.) and precisely command the motors.
- PID (Proportional-Integral-Derivative) Control: This control loop mechanism is central to maintaining stability. It constantly adjusts motor thrust based on the drone’s current state (P), accumulated error (I), and rate of change of error (D) to correct deviations from the desired attitude or position. In turbulent conditions, finely tuned PID loops are crucial for rapid, accurate corrections, preventing the drone from being buffeted off course or crashing.
- Adaptive Control Algorithms: More advanced flight controllers incorporate adaptive algorithms that can dynamically adjust PID gains based on changing environmental conditions (e.g., stronger winds, payload changes), further enhancing stability in real-time.
Propeller and Motor Design for High Thrust-to-Weight Ratios
The physical components that generate lift and control are equally vital.
- High Thrust-to-Weight Ratios: Drones designed for challenging environments often feature powerful motors and efficient propellers that can generate significant thrust relative to the drone’s weight. This allows for rapid acceleration, deceleration, and the ability to counteract strong winds and maintain altitude, even when carrying heavier payloads for sensing or delivery.
- Responsive Motors and Propellers: Motors that can change RPM quickly, coupled with propellers designed for aerodynamic efficiency across a range of speeds, enable the flight controller to make swift and precise adjustments to maintain stability against sudden gusts.
Aerodynamic Frame Design
The physical shape of the drone itself plays a role in its ability to resist turbulent air.
- Streamlined Profiles: While many drones prioritize compact size, designs with more streamlined profiles can reduce drag and provide inherent stability against wind, requiring less effort from the flight control system.
- Robust Construction: A strong, rigid frame minimizes flex and vibration, which can interfere with sensor readings and flight stability, crucial for surviving minor impacts or rough handling often associated with operations in rocky areas.
Terrain Following and Adaptive Flight Modes
For missions like mapping, inspection, or environmental monitoring over rugged, rocky terrain, simply avoiding obstacles isn’t enough. The drone must be able to maintain a consistent, safe, and often precise distance from the undulating ground.
Radar and LiDAR Altimetry for Consistent Altitude
Traditional barometric altimeters provide altitude relative to sea level or takeoff point, but not directly to the ground beneath the drone in uneven terrain.
- Radar Altimeters: These sensors emit radio waves downwards and measure the time for the reflection to return, directly indicating the drone’s height above the immediate ground. They are robust in various weather conditions and provide accurate relative altitude data.
- LiDAR Altimeters: Similar to radar but using lasers, LiDAR altimeters can also provide highly accurate height-above-ground measurements, often with greater precision and spatial resolution, crucial for following intricate terrain features like steep rocky slopes.
By integrating these altimeters with the flight controller, drones can maintain a constant, pre-set altitude above the terrain contour, enabling safer and more consistent data acquisition without the risk of impacting sudden upward slopes or flying unnecessarily high over valleys.
Digital Elevation Model (DEM) Integration
For pre-planned missions over known rugged areas, integrating a Digital Elevation Model (DEM) can significantly enhance terrain-following capabilities.
- Predictive Flight Planning: A DEM is a 3D representation of the terrain. By uploading a DEM to the drone’s mission planner, the drone can predict terrain changes along its flight path and pre-compute necessary altitude adjustments. This allows for smoother, more efficient, and safer flights, minimizing surprises for the real-time obstacle avoidance systems.
- Enhanced Safety and Efficiency: Knowing the terrain in advance allows the drone to optimize its flight speed and path, avoiding unnecessary climbs or descents, and ensuring consistent data overlap for mapping applications over complex geological features.
Adaptive Flight Profiles
Beyond simple terrain following, advanced drones can employ adaptive flight profiles that dynamically adjust their behavior based on the complexity of the terrain and mission objectives.
- Automated Speed Adjustment: When flying over very rugged or steep rocky sections, the drone can automatically reduce its speed to allow its sensors and control systems more time to react and make precise adjustments. Conversely, over flatter sections, it can increase speed to cover ground more efficiently.
- Dynamic Standoff Distance: Depending on the mission (e.g., close-up inspection of a rock face vs. broad area mapping), the drone can dynamically adjust its safe standoff distance from terrain features, maximizing data quality while maintaining safety.
- Edge-Aware Flight: For tasks like inspecting cliff faces, drones can utilize algorithms to detect and follow edges, maintaining a consistent offset, which is particularly challenging given the often irregular and unpredictable nature of rock formations.
Ultimately, “what is strong against rock” in the drone world is not a single feature but a robust ecosystem of flight technologies working in concert. It’s the precision of navigation, the vigilance of obstacle avoidance, the resilience of stabilization, and the intelligence of adaptive flight. These advancements ensure that drones can not only survive but thrive in the most challenging and unforgiving geological environments, unlocking new possibilities for exploration, mapping, and monitoring where human access is difficult or dangerous.