
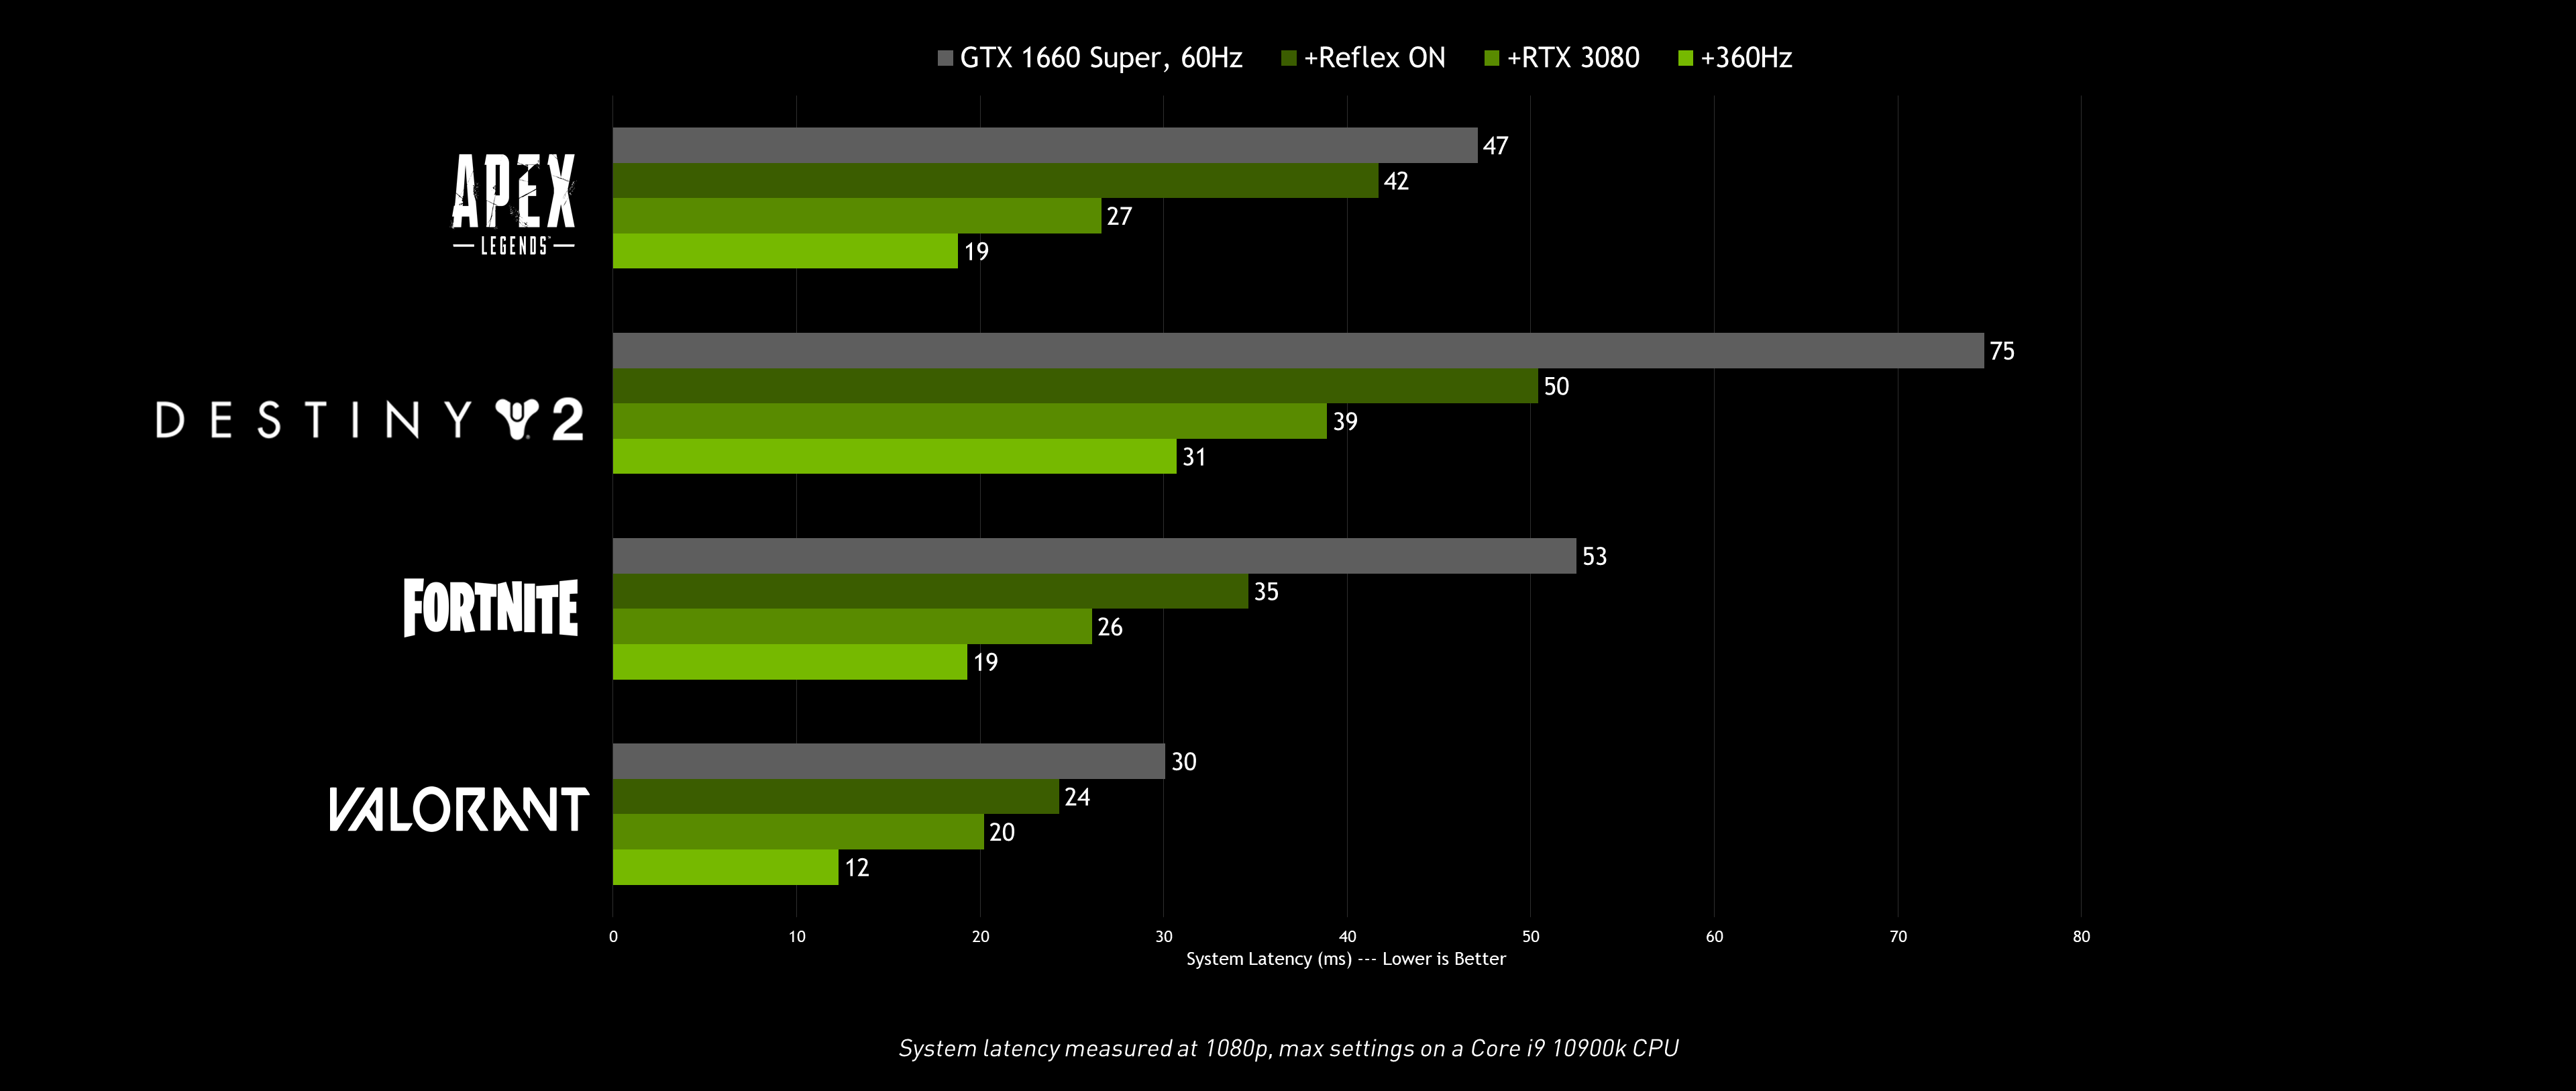
In the rapidly evolving world of drone technology, where precision, responsiveness, and real-time decision-making are paramount, the concept of “low latency” transcends mere convenience to become a fundamental requirement for innovation and operational excellence. While NVIDIA Reflex may be widely recognized for its impact on interactive computing systems beyond the drone sphere, understanding its core principles of latency reduction offers profound insights into the technological imperatives driving the next generation of aerial robotics and intelligent flight systems. At its heart, NVIDIA Reflex represents a sophisticated approach to minimizing system latency – the critical delay between a user input or a sensor’s data acquisition and the system’s visible or actionable response. This end-to-end optimization paradigm holds direct and compelling relevance for the advancement of drone capabilities, from autonomous navigation to precision aerial maneuvers and real-time remote sensing.
The Imperative of Low Latency in Advanced Drone Technology
The performance ceiling of modern drone technology is increasingly defined by its ability to process information and execute commands with minimal delay. In the context of “Tech & Innovation” within the drone ecosystem, latency is not merely an inconvenience; it is a critical limiting factor that dictates safety, operational efficiency, and the feasibility of advanced applications. Every millisecond of delay introduces a gap between the desired state and the actual state of the drone, impacting everything from smooth flight control to the accuracy of AI-driven decisions.
For autonomous flight systems, reduced latency means quicker perception-action loops, allowing drones to respond to dynamic environments with greater agility and precision, avoiding obstacles or adjusting flight paths in fractions of a second. In remote sensing and mapping, real-time data processing and immediate feedback are essential for tasks requiring instant adjustments or critical data acquisition. Even for basic flight stability, the timely processing of sensor data and the precise actuation of control surfaces depend on an extremely low-latency pipeline. As drone technology pushes towards higher levels of autonomy, complex swarm operations, and more demanding industrial applications, innovations focused on mitigating system latency become absolutely indispensable.
NVIDIA Reflex: A Blueprint for Latency Minimization
To truly grasp the significance of low latency in drones, it is instructive to examine pioneering solutions from other advanced computational fields. NVIDIA Reflex stands as a prime example of such an innovation, a suite of technologies engineered to meticulously measure and drastically reduce system latency across complex interactive systems. While not directly a component of current drone hardware, its underlying principles and architectural optimizations serve as an invaluable blueprint for the challenges faced in drone technology.
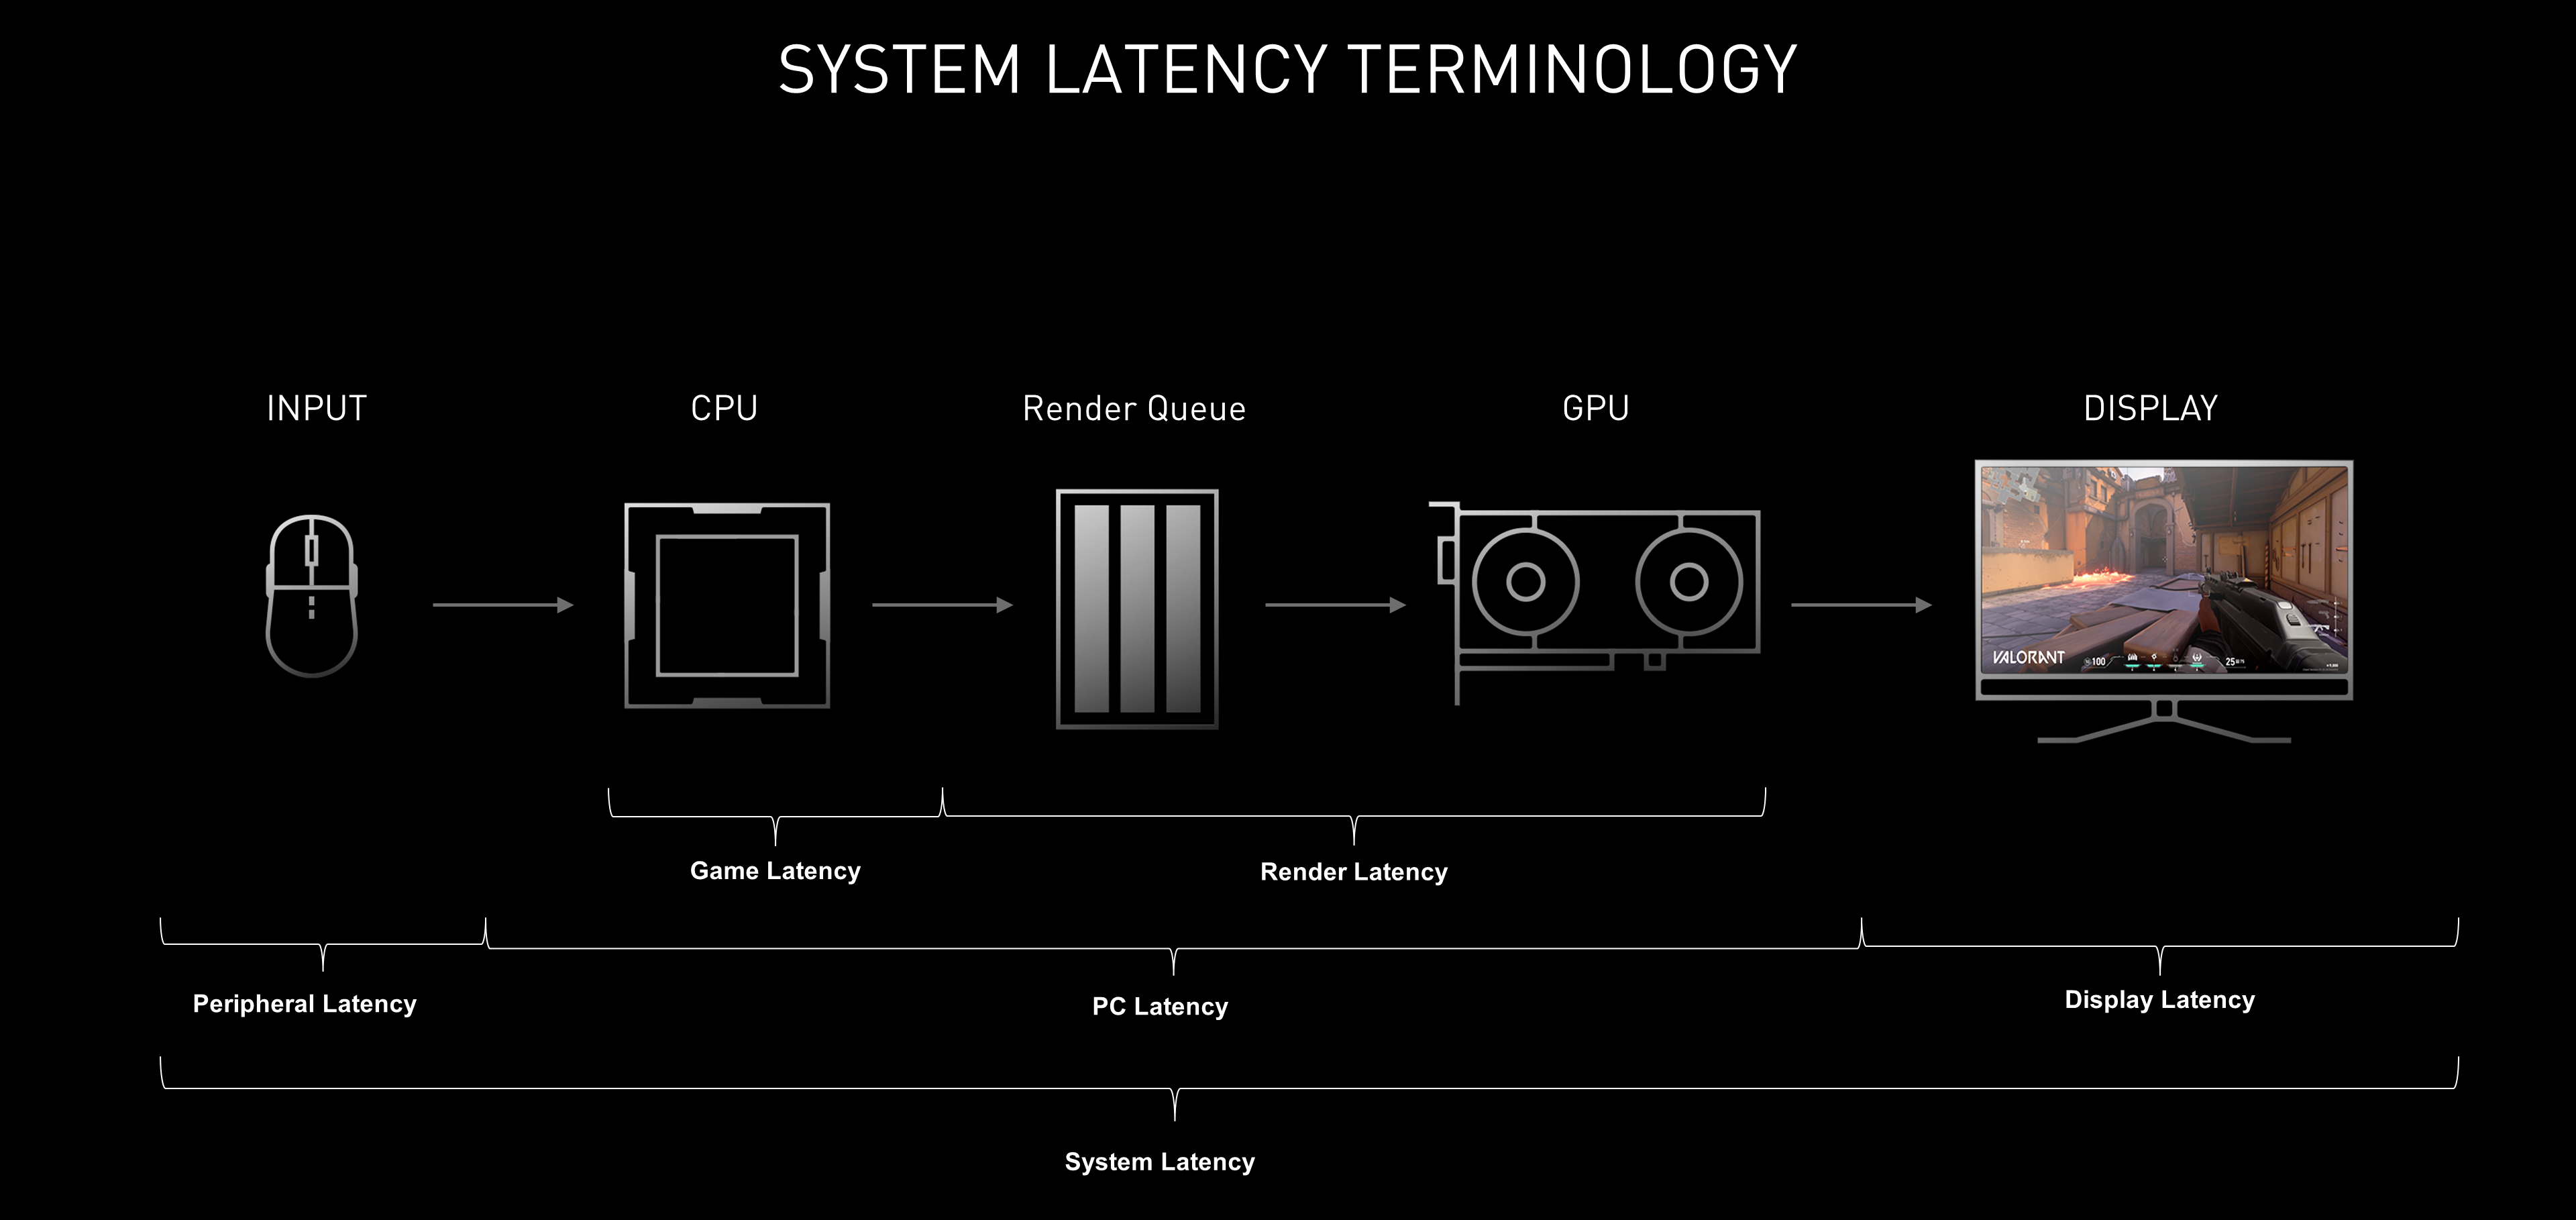
At its core, NVIDIA Reflex targets the total system latency, which can be broken down into several stages:
- Input Latency: The time it takes for an input device (e.g., a controller stick movement, a sensor reading) to register with the system.
- Processing Latency (CPU/GPU): The time the central processing unit and graphics processing unit (or specialized embedded processors in drones) spend processing data, performing computations, and preparing frames or commands.
- Rendering Latency: Specifically within visual systems, the time it takes for the GPU to render a frame.
- Display Latency: The time from when a rendered frame is sent to the display device until it is fully visible.
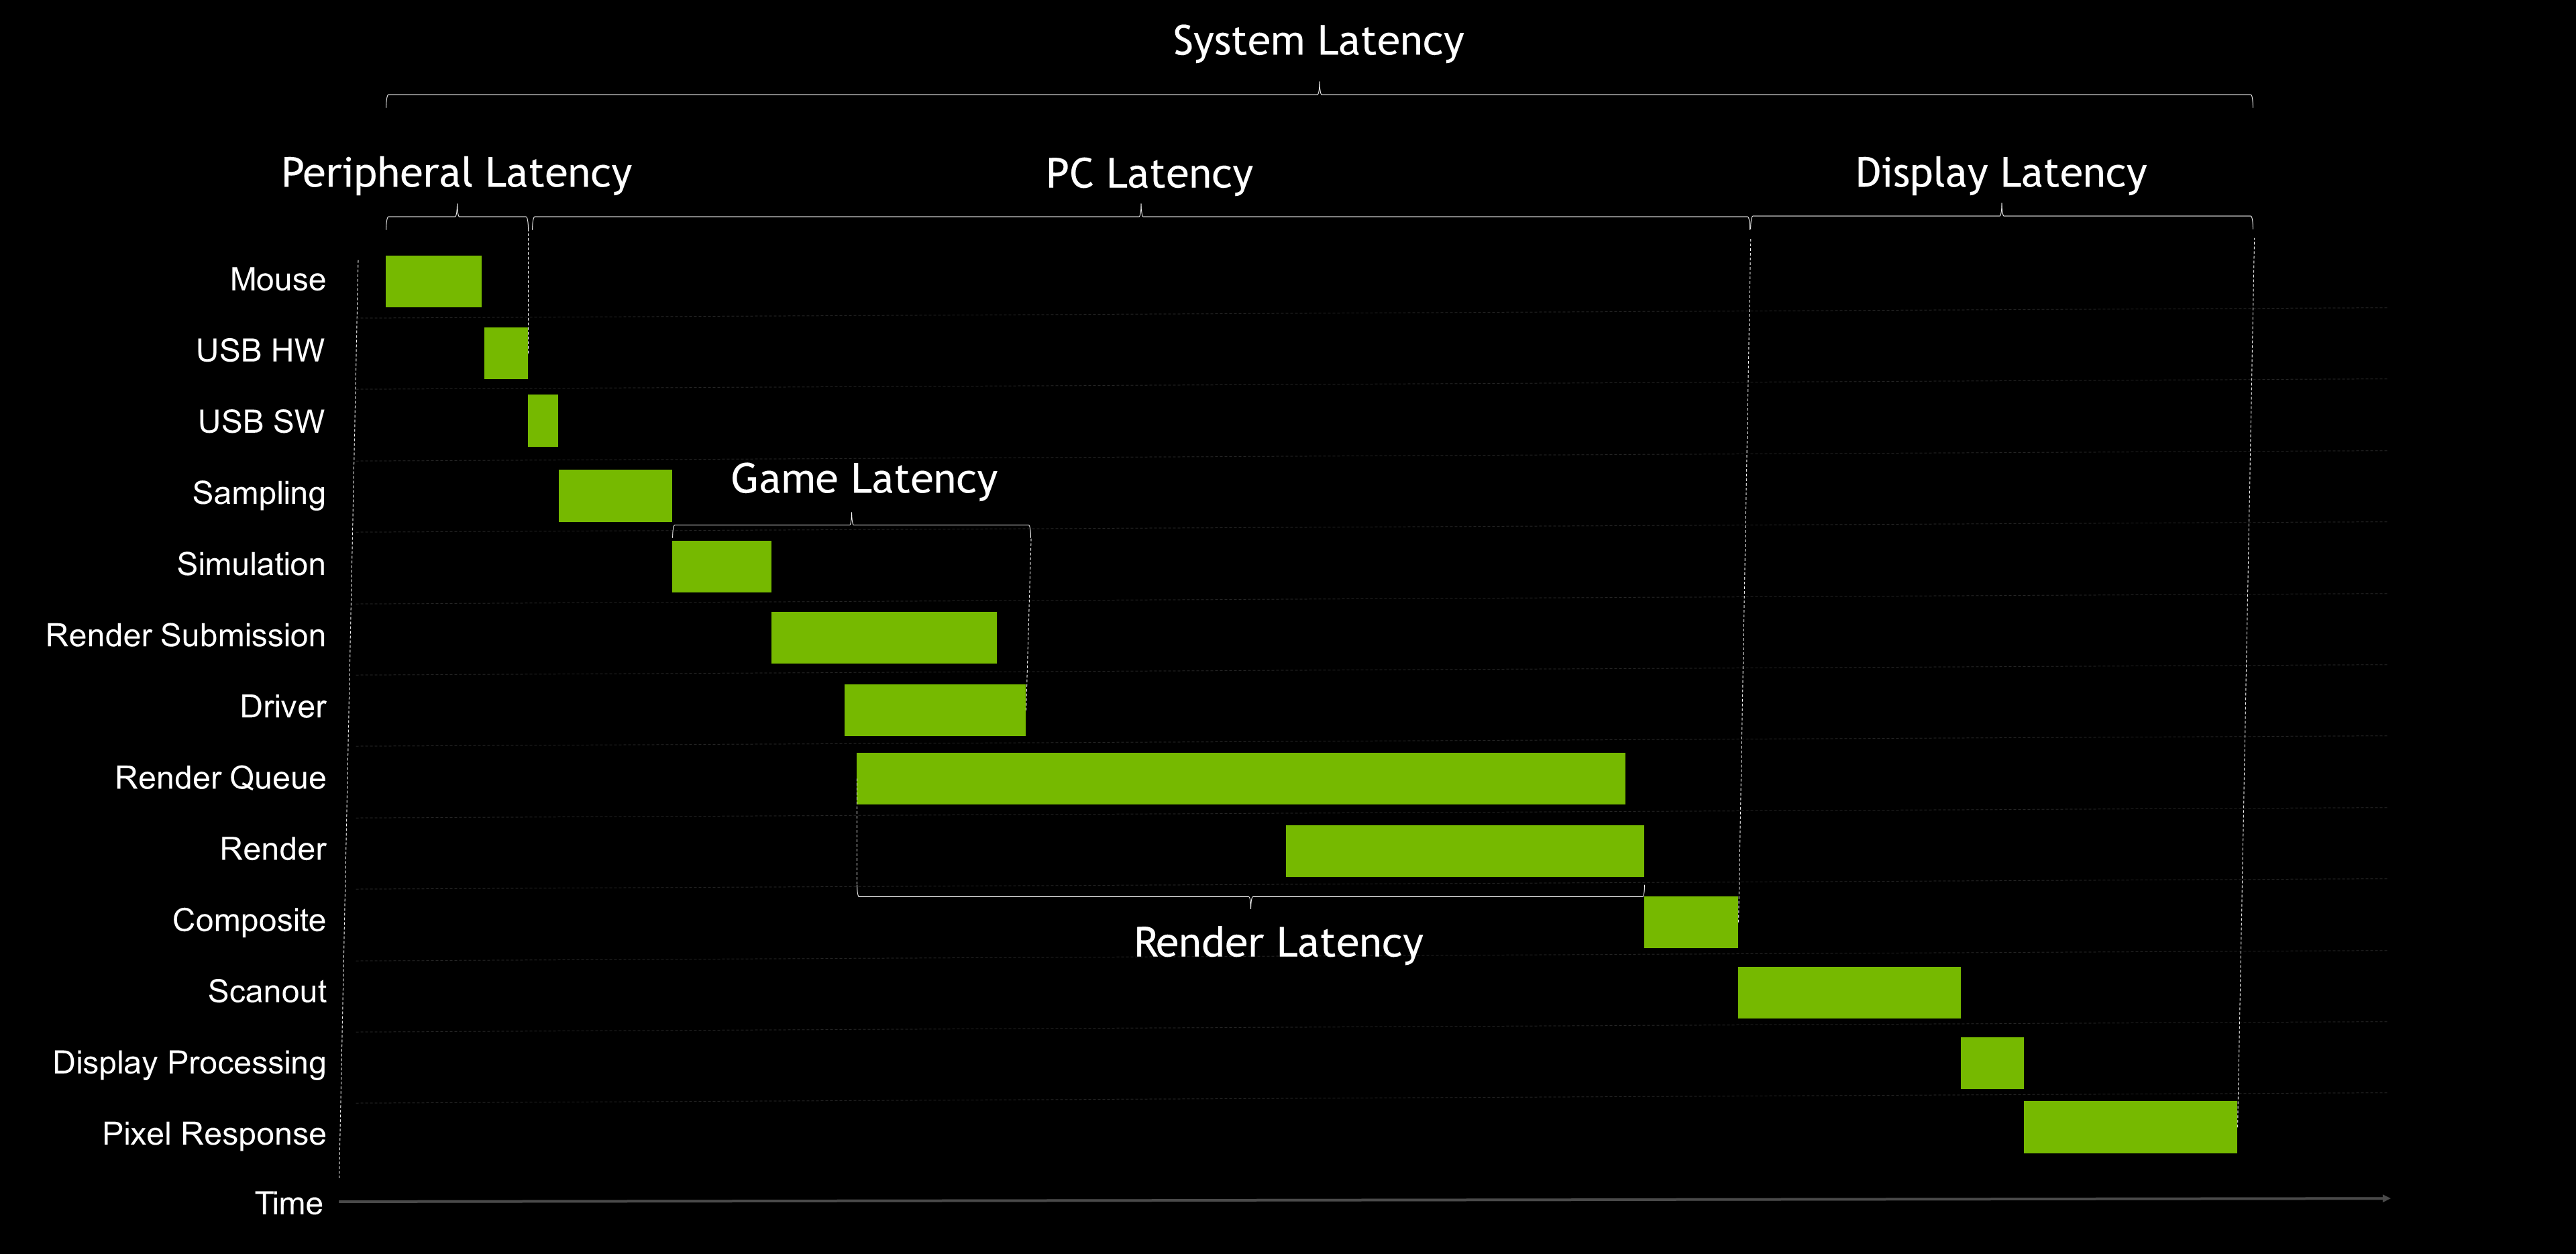
NVIDIA Reflex specifically addresses the processing and rendering latency components by optimizing the pipeline between the CPU and GPU. Traditionally, the CPU might render frames ahead of the GPU, creating a “render queue” that introduces delay. Reflex intelligently synchronizes the CPU and GPU work, dynamically adjusting the render queue to ensure the CPU is not bottlenecking while also preventing it from over-queuing frames. This “just-in-time” rendering approach eliminates unnecessary buffer delays, allowing the system to react more instantaneously to new inputs. Furthermore, it incorporates a low-latency mode that pushes frames through the pipeline more aggressively, minimizing any idle time or buffering. By making the entire system more responsive, Reflex allows for a tighter feedback loop between input and action, a principle that is universally critical for any real-time control system, including advanced drones.
Applying Reflex Principles to Drone Tech & Innovation
The insights garnered from NVIDIA Reflex’s approach to latency reduction are directly applicable to solving analogous challenges within drone technology and innovation:
Real-Time Flight Control and Stabilization
For any drone, maintaining stable flight and executing precise maneuvers requires a continuous, high-frequency feedback loop. This loop involves:
- Sensor Input: Accelerometers, gyroscopes, barometers, and GPS units continuously feed data to the flight controller.
- Flight Controller Processing: The onboard computer (often an embedded system) processes this data to determine the drone’s current orientation, position, and velocity, and then calculates the necessary motor adjustments to achieve the desired state.
- Actuator Output: Commands are sent to the Electronic Speed Controllers (ESCs), which in turn adjust motor speeds.
Any latency introduced at any stage of this pipeline can lead to instability, oscillations, or delayed responses to pilot commands or autonomous instructions. Applying “Reflex-like” principles here means optimizing the real-time operating system (RTOS) scheduling, streamlining sensor data bus communication, and minimizing the computational overhead of control algorithms. Innovating in this area means moving towards tighter integration of flight controller hardware and software, potentially incorporating specialized low-latency processing units that can mirror Reflex’s CPU-GPU synchronization model for sensor-to-actuator responsiveness. The goal is to reduce the time from a physical disturbance (e.g., wind gust) to the drone’s corrective motor action to mere milliseconds, ensuring unparalleled stability and responsiveness.
FPV and Remote Visual Systems
First-Person View (FPV) drones, especially those used for racing or complex cinematic shots, are entirely dependent on ultra-low latency video transmission and display. The pilot’s ability to react to the drone’s environment is directly tied to the timeliness of the video feed. A delay of even tens of milliseconds can mean the difference between clearing an obstacle and crashing.
- Camera Input: The drone’s FPV camera captures the visual scene.
- Video Encoding/Transmission: The video signal is encoded and transmitted wirelessly from the drone to the ground station.
- Video Decoding/Display: The ground station receives, decodes, and displays the video on a screen or goggles.
NVIDIA Reflex’s focus on minimizing “display latency” – the time from when the image is generated to when it appears on screen – directly translates to the FPV challenge. Innovation here involves developing highly efficient video codecs designed for minimal latency, optimizing wireless transmission protocols, and utilizing display technologies with inherently low input lag. Furthermore, future FPV systems could benefit from integrated processing units that manage the video pipeline with Reflex-like efficiency, synchronizing camera capture with encoding and transmission to ensure the freshest possible frame reaches the pilot’s eyes with the least possible delay. This pursuit of “glass-to-glass” low latency is critical for pushing the boundaries of FPV piloting experience and precision.
Autonomous Navigation and AI Perception-Action Loops
The frontier of drone innovation lies in autonomous capabilities, where AI systems perceive the environment, make complex decisions, and execute actions without human intervention. This sophisticated loop demands extreme low latency:
- Sensor Fusion: Data from multiple sensors (LiDAR, radar, cameras, ultrasonic) is collected and fused to create a comprehensive understanding of the environment.
- AI Processing: Onboard AI models (e.g., for object detection, semantic segmentation, path planning, collision avoidance) process this fused data to make decisions.
- Command Generation: Based on AI decisions, flight commands are generated.
- Actuator Execution: Commands are sent to the flight control system and motors.
Each stage in this perception-action loop introduces potential latency. For instance, a delay in processing LiDAR data could mean an autonomous drone detects an obstacle too late to avoid it. The principles of NVIDIA Reflex — streamlining computational pipelines, synchronizing data flow, and optimizing processing queues — are profoundly relevant. Innovating in this space requires specialized edge computing platforms on drones capable of ultra-low-latency AI inference, perhaps leveraging dedicated neural processing units (NPUs) that can process sensor data and execute AI models with minimal delay. Moreover, the integration of these AI decisions with the flight control system must also be optimized for speed, ensuring that the “brain” of the drone can effectively and immediately command its “body.”
The Future Landscape of Low Latency in Drones
The drive for ultra-low latency will continue to be a cornerstone of “Tech & Innovation” in the drone sector. Future advancements will likely involve a multifaceted approach:
- Hardware-Software Co-Design: Just as NVIDIA Reflex optimizes the interplay between CPU, GPU, and software, drone innovators will increasingly design embedded hardware and software together, creating custom architectures tailored for minimal latency across all critical functions.
- Dedicated Low-Latency Pathways: Specialized communication buses and processing cores will emerge, explicitly designed to handle time-critical data and commands, isolating them from less time-sensitive background tasks.
- Edge AI Acceleration: The proliferation of powerful, energy-efficient AI accelerators on the drone itself will allow for real-time processing of complex data without the latency introduced by transmitting data to cloud servers. These accelerators will need to be integrated into the drone’s control loop with Reflex-like efficiency.
- Advanced Networking Protocols: Wireless communication protocols for command and control, as well as video transmission, will evolve to further reduce airtime latency, employing techniques like predictive buffering and adaptive bitrate streaming.
Ultimately, the lessons from innovations like NVIDIA Reflex underscore a universal truth in advanced technology: the relentless pursuit of speed and responsiveness fundamentally expands the realm of what is possible. For drones, achieving ultra-low latency will unlock unprecedented levels of autonomy, precision, and immersive experience, paving the way for safer operations, more efficient applications, and revolutionary capabilities in aerial robotics.