
Data normalization is a critical preprocessing step in data science and machine learning, particularly vital for the sophisticated applications emerging within drone technology and innovation. At its core, normalizing data involves transforming numerical feature values into a standardized range without distorting differences in the ranges of values or losing information. This transformation ensures that each feature contributes approximately proportionately to the outcome, preventing features with larger numerical ranges from dominating those with smaller ranges, thereby leading to more stable and efficient model training.
In the context of advanced drone systems—encompassing AI follow modes, autonomous flight, precise mapping, and remote sensing—the data collected is often heterogeneous. Drones integrate various sensors: GPS for location, accelerometers and gyroscopes for orientation, lidar for depth, cameras for visual data, and sometimes thermal sensors or hyperspectral imagers. Each of these sensors produces data with different scales, units, and distributions. Without normalization, algorithms would struggle to weigh these disparate inputs effectively, potentially leading to suboptimal performance, inaccurate predictions, or even critical system failures in autonomous operations. Normalizing this diverse data stream is not merely a best practice; it is a fundamental requirement for building robust, reliable, and intelligent drone systems capable of performing complex tasks in dynamic environments.
The Fundamental Role of Data Normalization in Drone Technology
The myriad data streams flowing from a modern drone—from navigation data to environmental observations—underscore the necessity of data normalization. This process is pivotal for creating a unified and coherent operational picture, enabling drones to perform sophisticated tasks with unprecedented accuracy and autonomy.
Ensuring Consistency Across Diverse Sensor Inputs
Drones are veritable flying sensor platforms. A single flight can generate data from GPS modules (latitude, longitude, altitude), Inertial Measurement Units (IMUs) providing acceleration and angular velocity, ultrasonic or lidar sensors for distance, and various cameras capturing light intensity, color, and depth. Each of these data types inherently operates on vastly different scales. For instance, GPS coordinates might span a wide geographical range, while IMU readings for angular velocity might fluctuate within a small numerical window. If these raw, unscaled values are fed directly into a decision-making algorithm or a machine learning model, features with larger magnitudes (like GPS coordinates) could inadvertently exert an undue influence on the model’s learning process, effectively overshadowing the critical insights provided by features with smaller scales (like minute changes in angular velocity indicative of impending instability).
Data normalization addresses this by bringing all sensor outputs to a comparable scale. This harmonization ensures that no single sensor type disproportionately sways the interpretation or prediction of a model, allowing algorithms to objectively consider the contributions of all data streams. For autonomous flight, consistent sensor inputs are paramount for precise navigation, stable flight control, and accurate obstacle detection, preventing erratic behavior or misinterpretations that could lead to collisions or mission failures.
Enhancing Machine Learning and AI Performance
The adoption of artificial intelligence and machine learning is transforming drone capabilities, from autonomous inspection to intelligent object recognition. These advanced algorithms, particularly neural networks and support vector machines, are highly sensitive to the scale of input features. Unnormalized data can lead to several challenges:
- Slower Convergence: Optimization algorithms, such as gradient descent, operate by iteratively adjusting model parameters. When features have widely differing scales, the cost function landscape can become elongated and distorted, making it difficult for the optimizer to find the minimum efficiently. Normalization creates a more spherical error surface, enabling faster convergence to optimal solutions.
- Vanishing or Exploding Gradients: In deep learning models, unscaled inputs can exacerbate issues like vanishing or exploding gradients, where gradients either become too small to affect learning or too large, leading to unstable training. Normalization helps stabilize gradient flow, ensuring effective learning across all layers.
- Improved Model Accuracy and Robustness: By leveling the playing field for all features, normalization allows models to learn the true underlying relationships in the data more effectively. This leads to more accurate predictions, better generalization to unseen data, and increased robustness against variations in sensor readings or environmental conditions. For AI follow modes, consistent data ensures the drone accurately tracks its target despite changes in lighting or background. For autonomous mapping, normalized data from various sensors (e.g., visual and lidar) improves the fusion process, resulting in more precise and detailed environmental models.
Methodologies for Data Normalization in Drone Applications
Several techniques exist for normalizing data, each with its own advantages depending on the data distribution, the presence of outliers, and the requirements of the subsequent analytical or machine learning task. Selecting the appropriate method is crucial for optimizing the performance of drone-based AI and autonomous systems.
Min-Max Scaling for Feature Transformation
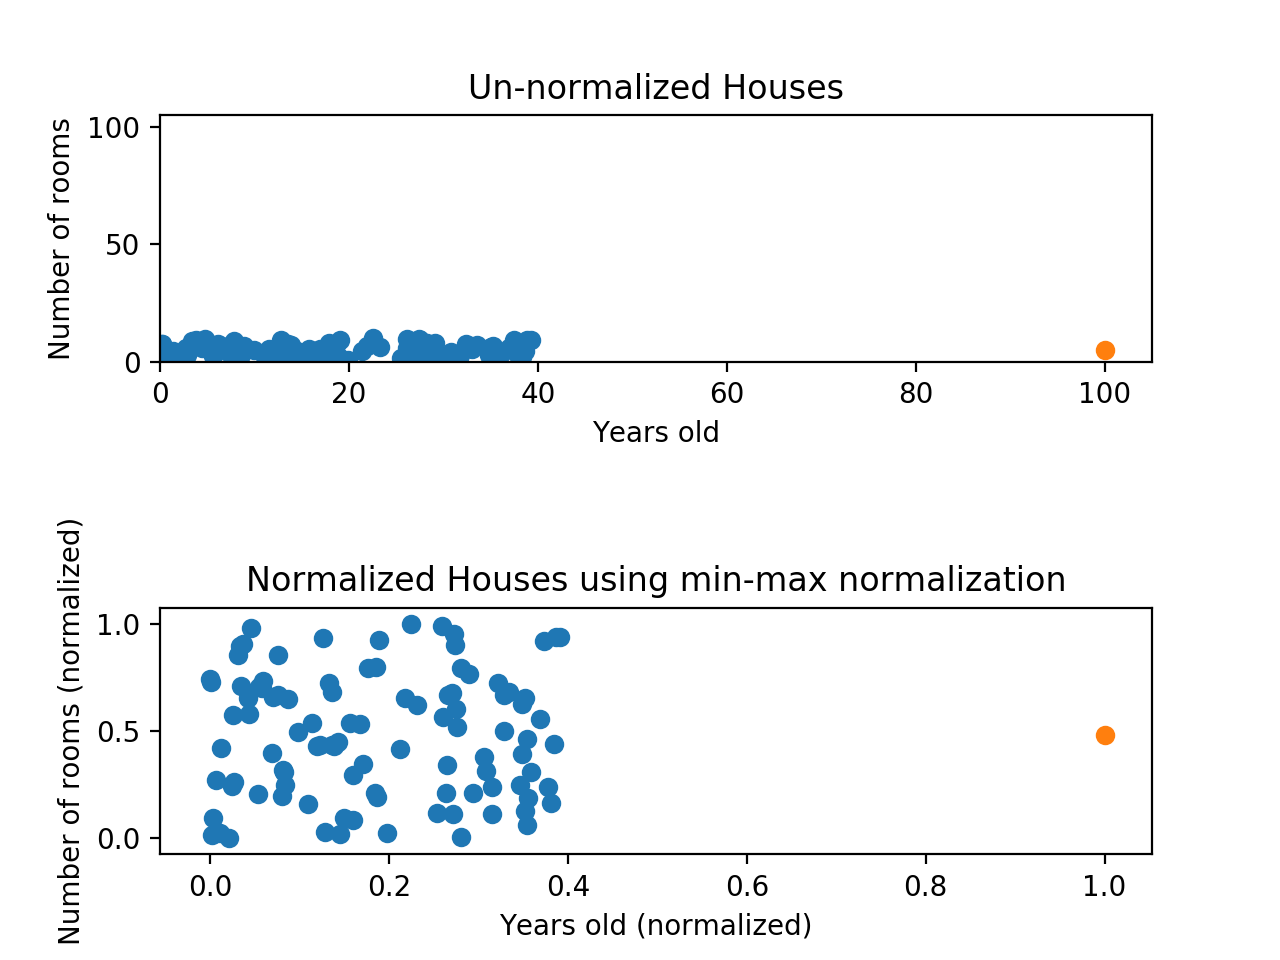
Min-Max Scaling, also known as standardization or feature scaling, transforms features by scaling them to a fixed range, typically between 0 and 1. The formula for Min-Max scaling is:
$X{normalized} = (X – X{min}) / (X{max} – X{min})$
Where $X$ is the original feature value, $X{min}$ is the minimum value of that feature in the dataset, and $X{max}$ is the maximum value. This method is particularly useful when the data does not follow a Gaussian distribution and when algorithms, like neural networks, expect input features to be within a specific boundary. For drone applications, Min-Max scaling can be effectively applied to sensor data such as battery voltage readings, altitude measurements, or light intensity values from cameras, where knowing the absolute minimum and maximum operational ranges is critical. It provides a straightforward way to represent all these features on a comparable, intuitive scale.
Z-Score Normalization for Statistical Consistency
Z-Score Normalization, also known as standardization, transforms data to have a mean of 0 and a standard deviation of 1. The formula is:
$X_{normalized} = (X – mu) / sigma$
Where $X$ is the original feature value, $mu$ is the mean of the feature, and $sigma$ is its standard deviation. This method is especially beneficial when the data has a Gaussian distribution or when algorithms assume normally distributed inputs, such as those used in some statistical modeling or principal component analysis (PCA) for dimensionality reduction. In drone tech, Z-score normalization is valuable for sensor data like IMU readings (accelerometer, gyroscope data) or GPS velocity components, which often exhibit natural variations around a mean. It is robust to the exact range of data and is less sensitive to outliers than Min-Max scaling, as it doesn’t compress all values into a rigid boundary defined by the extremes.
Robust Scaling for Outlier Resilience
Robust Scaling is a normalization technique that scales features using the interquartile range (IQR) and the median, rather than the mean/standard deviation or min/max. The formula typically involves:
$X_{normalized} = (X – Median) / IQR$
Where $Median$ is the median of the feature values, and $IQR$ is the interquartile range ($Q3 – Q1$, where $Q3$ is the third quartile and $Q1$ is the first quartile). This method is particularly useful when the dataset contains significant outliers, as the median and IQR are much less affected by extreme values compared to the mean and standard deviation or the absolute min/max. Given that drone sensor data can sometimes suffer from transient noise or erroneous readings (outliers), Robust Scaling offers a more stable normalization approach. For instance, in remote sensing, where atmospheric conditions or reflections might cause extreme values in spectral measurements, Robust Scaling can help preserve the integrity of the majority of the data without disproportionately shrinking the scale due to a few anomalous readings. It ensures that the bulk of the data remains well-represented without being skewed by a handful of unusual observations.
Practical Applications in Autonomous Flight and Remote Sensing
The theoretical underpinnings of data normalization find their most impactful expression in the advanced operational spheres of drone technology, particularly in achieving truly autonomous capabilities and extracting meaningful insights from remote sensing missions.
Stabilizing Autonomous Navigation and Obstacle Avoidance
Autonomous flight systems rely heavily on real-time interpretation of diverse sensor data for navigation and environmental perception. For a drone to autonomously follow a pre-planned route, maintain altitude, and avoid dynamic obstacles, it must integrate inputs from GPS, IMUs (accelerometers, gyroscopes, magnetometers), altimeters, and often vision-based or lidar-based obstacle detection systems. Each of these sensors produces data on different scales and with varying levels of noise.
For instance, GPS data provides latitude and longitude coordinates and altitude, while an IMU delivers angular velocities and linear accelerations, and a lidar sensor outputs distances to objects. Normalizing these disparate data streams ensures that the flight control algorithms can effectively fuse them, creating a consistent representation of the drone’s state and its surroundings. When all input features—from position offsets to angular rates and obstacle distances—are on a similar scale, the control system can make more accurate and timely adjustments. This prevents, for example, a large numerical value from a distant GPS reading from overpowering a critical, small-magnitude signal from an IMU indicating an impending roll. The result is significantly enhanced flight stability, more precise trajectory tracking, and reliable obstacle avoidance, even in complex or dynamic environments like urban canyons or dense forests.
Improving Data Fusion for Enhanced Situational Awareness
Data fusion is the process of combining data from multiple sensors to obtain a more complete and accurate understanding of a system’s state or environment than would be possible using individual sensors alone. In drones, this is crucial for building a robust model of the world around them. For example, simultaneously using visual data from cameras, depth information from lidar, and precise positioning from GPS can provide an incredibly rich situational awareness. However, effectively combining these diverse data types—pixel values, distance measurements, and geographical coordinates—is a non-trivial task.
Normalization plays a foundational role in enabling effective data fusion. By scaling all these varied inputs to a common range, normalization ensures that algorithms designed to merge these data streams can weigh each input appropriately. This prevents features with larger numerical ranges from dominating the fusion process. For instance, in object detection and tracking tasks, normalizing features extracted from images (e.g., pixel intensity, color histograms) alongside normalized lidar point cloud features (e.g., intensity, reflectivity, spatial coordinates) allows machine learning models to build more accurate and robust representations of objects. This improved data fusion capability leads to more reliable object identification, enhanced mapping precision, and a more comprehensive understanding of the operational environment, which are critical for advanced applications like search and rescue, infrastructure inspection, or autonomous delivery.
Standardizing Remote Sensing Datasets for Comparative Analysis
Remote sensing involves collecting data about an area from a distance, typically using spectral, thermal, or radar sensors mounted on drones. These applications range from agricultural monitoring and environmental assessment to geological surveys. A key aspect of remote sensing is the ability to compare data collected at different times, from different locations, or by different sensors.
However, raw remote sensing data is often influenced by various factors that can introduce inconsistencies. For example, atmospheric conditions (haze, cloud cover), solar illumination angles, sensor calibration variations, and topographic effects can all cause significant differences in recorded reflectance values, even for the same ground cover type. Normalization techniques are indispensable for standardizing these datasets. Methods such as radiometric calibration and atmospheric correction are forms of normalization that aim to remove these extrinsic effects, ensuring that the recorded values truly reflect the intrinsic properties of the surface being observed.
By normalizing spectral bands, for instance, researchers can compare vegetation health indices (like NDVI) calculated from imagery captured on different days or by different drones under varying conditions. This standardization allows for accurate change detection over time, robust classification of land cover types, and reliable quantitative analysis across broad geographical areas. Without normalization, comparisons would be skewed by environmental variability, leading to erroneous conclusions and hindering the scientific and practical utility of remote sensing data.
Challenges and Best Practices in Drone Data Normalization
While data normalization is indispensable for modern drone technology, its implementation is not without challenges. Effective normalization requires careful consideration of the specific data characteristics, the operational environment, and the ultimate goals of the drone application. Adhering to best practices can mitigate common pitfalls and maximize the benefits of this crucial preprocessing step.
Selecting the Appropriate Normalization Technique
The choice of normalization technique—Min-Max scaling, Z-score standardization, Robust scaling, or others—is not a one-size-fits-all decision. It hinges critically on the nature of the data and the requirements of the downstream algorithms. For instance, if sensor data like battery voltage or motor RPMs have well-defined minimum and maximum operational limits, and the exact range is important, Min-Max scaling might be appropriate. This method ensures all values are compressed within a known, consistent interval.
Conversely, for IMU data (accelerometer and gyroscope readings) that often approximate a normal distribution and where the presence of outliers from vibration or brief shocks is a concern, Z-score standardization is often preferred. It maintains the shape of the data’s distribution and handles outliers more gracefully than Min-Max scaling, as it normalizes based on the mean and standard deviation. If the data is known to contain significant, frequent outliers that could severely skew the mean and standard deviation, such as occasional erroneous lidar returns due to environmental interference, Robust scaling, which uses the median and interquartile range, offers superior resilience. Misapplying a technique can distort the data’s true relationships, leading to reduced model performance or unstable drone behavior. Therefore, a thorough understanding of the data’s statistical properties and the chosen algorithm’s sensitivities is paramount.
Handling Dynamic Environments and Real-time Data Streams
Drones operate in highly dynamic and unpredictable environments. This presents a unique challenge for data normalization, especially when dealing with real-time data streams. Traditional normalization techniques often rely on computing statistics (min/max, mean/std dev, median/IQR) from an entire, static dataset. However, in real-time drone operations, data arrives continuously, and the underlying distribution or range of values can shift.
For example, a drone flying from a brightly lit open field into a shaded forest will experience drastic changes in camera light intensity readings. Normalizing based on statistics derived from an initial, limited dataset might become obsolete as environmental conditions change. This can lead to “data drift,” where the normalized data no longer accurately reflects the current conditions, potentially causing AI models to perform poorly.
To address this, adaptive or online normalization techniques may be employed. These methods dynamically update the scaling parameters (e.g., mean, standard deviation) as new data arrives, often using moving averages or exponential smoothing to give more weight to recent observations. Implementing such adaptive strategies is complex and requires careful management of computational resources on board the drone, but it is essential for maintaining robust performance in continuously evolving operational scenarios, ensuring that autonomous flight systems remain stable and responsive.
Maintaining Data Integrity and Interpretability
While normalization is crucial for algorithmic performance, it inherently transforms the original data, which can sometimes complicate its interpretation. When data is scaled, the original units and magnitudes are lost, making it challenging to directly relate the normalized values back to their physical meaning without reverse transformation. This can be a significant concern for debugging, validation, and human oversight in safety-critical drone applications.
For example, if a normalized altitude reading falls below a certain threshold, it might trigger an emergency landing. However, without easy traceability to the original altitude value in meters, it’s harder for an operator to quickly understand the precise physical situation. Best practices involve meticulously documenting the normalization process, including the specific parameters (min/max, mean/std dev) used for each feature, and providing mechanisms for inverse transformation where original values need to be recovered for logging, analysis, or human-machine interaction. Furthermore, when designing models, it’s important to consider if the benefits of normalization outweigh the potential loss of immediate interpretability for specific features. In some cases, partial normalization or different scaling for different subsets of features might be a more effective strategy to balance algorithmic needs with operational clarity.