
In the rapidly evolving landscape of unmanned aerial vehicles (UAVs), commonly known as drones, technological advancements are constantly pushing the boundaries of what these devices can achieve. From intricate aerial maneuvers to sophisticated data collection, the underlying performance metrics are crucial. Among these, while often discussed in the realm of computing memory, a concept like “MT/s” — MegaTransfers per second — holds significant, albeit often overlooked, relevance to the core “Flight Technology” that powers every drone. Understanding MT/s provides a deeper insight into the real-time processing capabilities essential for a drone’s navigation, stabilization, sensor interpretation, and obstacle avoidance systems.
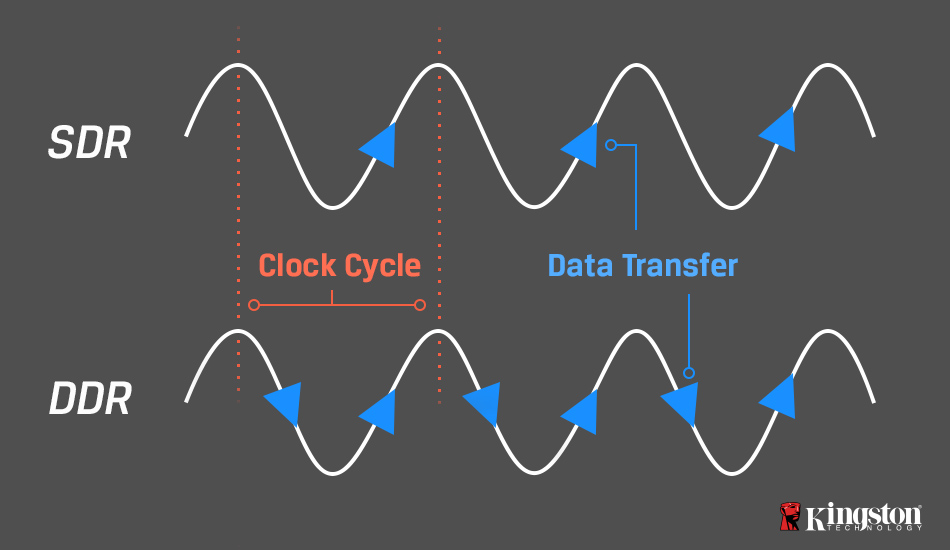
MT/s, or MegaTransfers per second, is a unit of measurement that quantifies the rate at which data is transferred between electronic components, most commonly referring to the speed of data transfer to and from memory (RAM) in digital systems. While a megabyte per second (MB/s) measures the total amount of data moved, MT/s specifically measures the number of discrete data transfer operations completed per second, irrespective of the data width of each transfer. In the context of drone flight technology, this metric directly impacts how quickly the flight controller, its onboard sensors, and other critical sub-systems can exchange and process information, which is paramount for stable, responsive, and autonomous flight.
The Fundamentals of Data Transfer in Flight Systems
At the heart of every drone lies its flight control system, a complex network of hardware and software designed to execute commands, maintain stability, and process a continuous stream of environmental data. The efficiency and speed of this system are directly tied to its data transfer capabilities. High MT/s values signify a more agile and responsive digital backbone, allowing the drone to react almost instantaneously to changes in its environment or pilot inputs.
Processors, Memory, and Buses
A drone’s flight controller typically comprises a microcontroller or microprocessor, volatile memory (RAM), non-volatile memory (flash storage), and various communication buses. The processor acts as the drone’s brain, executing the flight control algorithms. RAM serves as its short-term memory, holding data and instructions that the processor needs to access quickly. The speed at which the processor can fetch data from RAM is often measured in MT/s. A faster memory interface, indicated by a higher MT/s rate, means the processor spends less time waiting for data, leading to more efficient computation.
Communication buses (like SPI, I2C, UART, or more complex interconnects like PCIe in advanced systems) are the pathways through which different components — such as the Inertial Measurement Unit (IMU), GPS module, power management unit, and motor controllers — communicate with the main processor. While these buses have their own specific bandwidths and protocols, the overall system’s ability to rapidly ingest and disseminate data is bottlenecked by the slowest link, and often, the processor-to-memory transfer rate (MT/s) is a critical factor influencing the system’s ability to keep up with the demands of real-time flight. For instance, if sensor data is acquired at a high frequency, but the flight controller’s memory cannot transfer this data to the processor fast enough, critical processing delays can occur, compromising flight stability.
Real-Time Operating Systems and Data Latency
Modern drone flight controllers often run a Real-Time Operating System (RTOS) or a similar lightweight kernel that prioritizes time-critical tasks. These tasks include reading sensor data, executing control loops, and sending commands to Electronic Speed Controllers (ESCs) to adjust motor speeds. In such systems, latency — the delay between an event (like a sensor reading) and the system’s response — is a critical performance indicator. High MT/s contributes directly to reducing latency by ensuring that data required for these time-critical operations is available to the processor with minimal delay.
Consider the hundreds or thousands of times per second a flight controller needs to perform a “sense-compute-act” cycle. Each cycle involves reading data from accelerometers, gyroscopes, magnetometers, and barometers, transferring this data to memory, processing it through complex algorithms, and then issuing new motor commands. If the memory interface operates at a low MT/s, this entire cycle slows down, leading to a less stable flight, increased susceptibility to external disturbances (like wind gusts), and a less responsive feel for the pilot. In contrast, higher MT/s enables faster data throughput, tighter control loops, and ultimately, superior flight performance and precision.
MT/s and its Impact on Navigation & Stabilization
Precise navigation and robust stabilization are non-negotiable for any drone, whether it’s a recreational quadcopter or an industrial inspection UAV. The ability of a drone to maintain its attitude, altitude, and position accurately hinges entirely on the rapid and reliable processing of sensor data.
Sensor Data Fusion and IMU Performance
The IMU (Inertial Measurement Unit), comprising accelerometers and gyroscopes, is arguably the most critical component for flight stabilization. It measures the drone’s angular velocity and linear acceleration, providing the raw data needed to determine its orientation in space. High-performance IMUs can generate data at sampling rates of several kilohertz. For the flight controller to effectively use this data, it must be read, filtered, and fused with other sensor data (e.g., from magnetometers, barometers, GPS) in real-time.
This process, known as sensor fusion, involves complex mathematical algorithms that combine data from multiple sources to produce a more accurate and robust estimate of the drone’s state. The computational intensity of sensor fusion algorithms, coupled with the high sampling rates of modern sensors, places significant demands on the flight controller’s memory bandwidth. If the MT/s of the memory interface is insufficient, the flight controller might be forced to down-sample sensor data, leading to a less accurate and less responsive estimation of the drone’s attitude, or worse, introduce processing delays that result in instability. A high MT/s ensures that the full fidelity of sensor data can be utilized, leading to superior stabilization and smoother flight characteristics.
GPS and Positional Accuracy
While GPS (Global Positioning System) provides positional data at a much lower refresh rate than an IMU (typically 1-10 Hz), its data is still critical for navigation and waypoint following. In advanced navigation systems, GPS data is often fused with IMU data (Extended Kalman Filters are a common choice) to provide a more accurate and drift-free estimate of the drone’s position and velocity.
Even with lower refresh rates, the processing of GPS data, especially when combined with other sensors, contributes to the overall workload of the flight controller. Furthermore, as drones incorporate more advanced navigation features like RTK (Real-Time Kinematic) or PPK (Post-Processed Kinematic) GPS for centimeter-level accuracy, the volume and complexity of data exchange increase. These systems often require correction data streams to be processed alongside raw satellite data. A high MT/s ensures that the flight controller can efficiently handle these complex calculations, maintain tight synchronization, and integrate the precise positional data into the overall navigation solution without incurring performance penalties. This contributes to more accurate flight paths, precise hovering, and reliable waypoint navigation.
Enhancing Obstacle Avoidance and Autonomy
The ability of a drone to perceive its environment and react autonomously to obstacles or dynamic changes is a hallmark of advanced flight technology. These capabilities, fundamental to safer and more complex missions, are heavily dependent on high-speed data processing and transfer.
Vision Processing and LiDAR Integration
Modern drones are increasingly equipped with advanced perception sensors such as stereo cameras, time-of-flight (ToF) sensors, and LiDAR (Light Detection and Ranging) units. These sensors generate vast amounts of raw data (point clouds for LiDAR, depth maps and pixel data for cameras) that need to be processed in real-time to build a 3D model of the surrounding environment, detect obstacles, and identify safe flight paths.
Vision processing, in particular, is computationally intensive. Extracting features, performing object recognition, and calculating depth information from camera feeds requires powerful onboard processors and, crucially, very fast access to large blocks of memory. A high MT/s enables the rapid transfer of high-resolution image frames and sensor readings to the processor and its dedicated vision processing units (VPUs) or GPUs. Without sufficient memory bandwidth, processing delays can make real-time obstacle avoidance sluggish or unreliable. If the drone cannot process sensor data quickly enough to identify an approaching obstacle, its ability to react by braking or maneuvering away is severely compromised, potentially leading to collisions. High MT/s ensures that the drone can “see” and “think” fast enough to operate safely in complex environments.
AI and Machine Learning at the Edge
The cutting edge of drone technology involves the integration of Artificial Intelligence (AI) and Machine Learning (ML) algorithms for tasks like intelligent object tracking, autonomous decision-making, and sophisticated mapping. Running these complex AI models “at the edge” — directly on the drone itself rather than relying on cloud processing — demands significant onboard computational resources.
AI models, especially neural networks, involve millions or even billions of parameters and require massive parallel computations. The data required for these computations (e.g., input images, model weights, intermediate activations) must be constantly transferred to and from the processor’s memory. Higher MT/s rates are directly proportional to the speed at which these AI inferences can be made. This is critical for applications like “AI Follow Mode,” where the drone needs to identify and track a subject in real-time, or for autonomous inspection tasks where it needs to detect anomalies on structures. Without high MT/s, the drone’s AI capabilities would be bottlenecked, leading to slower reactions, reduced accuracy, and ultimately, diminished autonomous performance.

Future Implications for Drone Flight Technology
As drone technology continues to advance, the demand for higher MT/s will only intensify. Future drones will likely feature more sophisticated sensor arrays, more powerful edge AI capabilities, and increased autonomy, all of which rely on faster and more efficient data transfer within their flight systems. We can anticipate:
- Enhanced Sensor Fusion: Integration of an even wider array of sensors (e.g., hyperspectral cameras, advanced radar) will necessitate higher data throughput for comprehensive environmental awareness.
- True Autonomous Flight: Moving beyond programmed routes to truly adaptive and intelligent autonomous navigation in dynamic, unstructured environments will require real-time processing of vast amounts of sensor data and rapid execution of complex AI models, all underpinned by high MT/s.
- Miniaturization and Efficiency: While increasing performance, future designs will also aim for greater power efficiency. Optimized memory subsystems with high MT/s will allow for more processing capability within smaller, lighter, and more power-constrained drone platforms.
- Swarm Robotics: Coordinated drone operations, where multiple UAVs communicate and collaborate, will require not only robust external communication but also highly efficient internal data processing within each drone to maintain synchronization and execute complex maneuvers collaboratively.
In conclusion, while MT/s might seem like an abstract technical specification, its implications for drone flight technology are profound and far-reaching. It is a foundational metric that underpins the responsiveness, stability, precision, and autonomy of modern UAVs. As drones become more intelligent and capable, the relentless pursuit of higher MT/s in their core flight systems will remain a critical factor in unlocking their full potential.