
In the intricate world of drone technology and innovation, particularly within the realms of artificial intelligence, autonomous flight, and remote sensing, the concept of a “double negative” transcends its traditional grammatical definition to signify a crucial aspect of system design, data interpretation, and logical processing. Far from being a mere linguistic curiosity, a double negative in this technical context can refer to the redundant assertion of an absence, the logical negation of a negative condition, or the interplay of multiple “non-detection” events from disparate sensors. Understanding its implications is vital for developing robust, reliable, and truly intelligent autonomous systems. It is about how absence is confirmed, how complex logical states are managed, and how potential risks or opportunities might be obscured or revealed through such constructions.
The Concept of Double Negation in Autonomous Systems
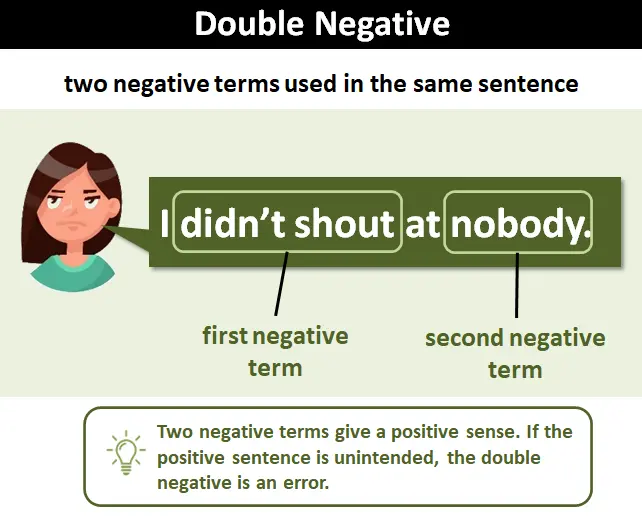
At its core, a double negative implies the cancellation of two negative statements to yield an affirmative meaning. Linguistically, “I don’t have no money” means “I have money.” In the sphere of tech and innovation, this translates into how autonomous systems and AI interpret and act upon information where the absence of a negative condition is reported, often from multiple sources or through nested logical operations. This isn’t always about a grammatical error, but rather a deliberate or emergent logical structure that needs careful consideration.
Linguistic Roots and Technical Parallels
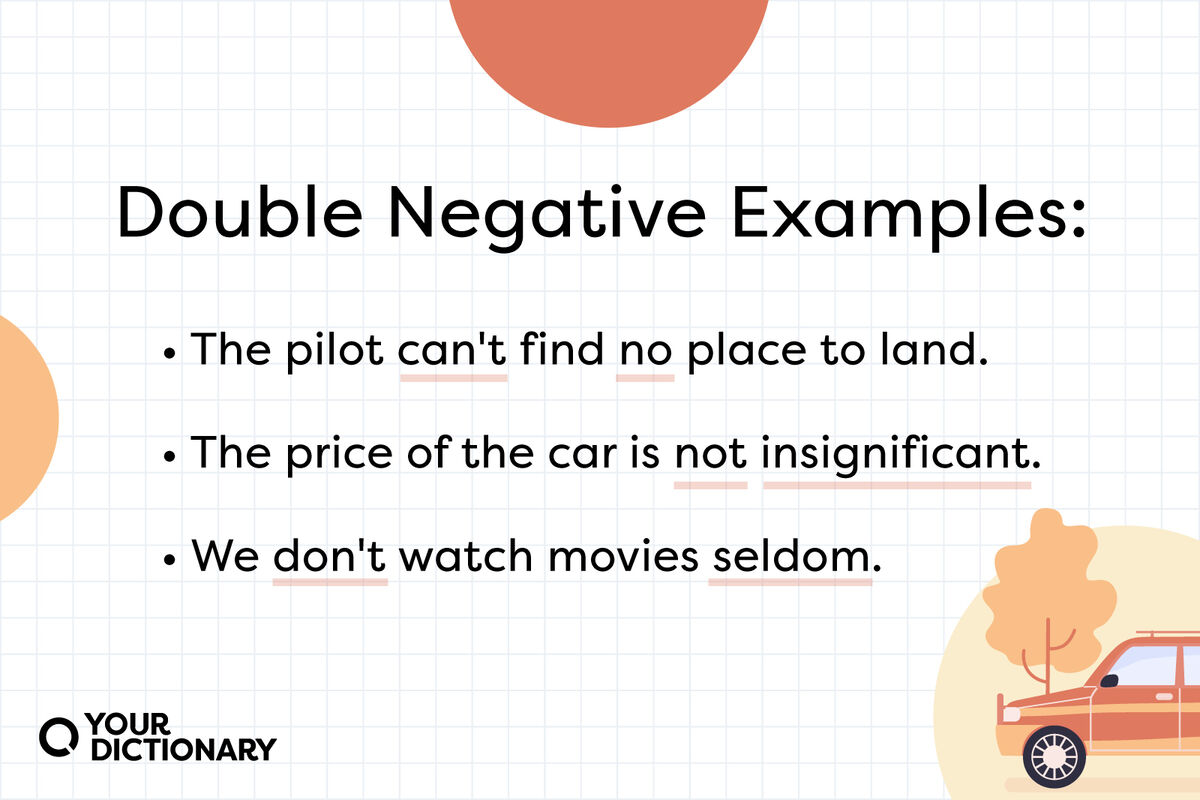
The grammatical concept of a double negative highlights a potential for ambiguity or, conversely, a form of emphatic affirmation. In technical systems, especially those driven by AI, this parallel emerges when processes are designed to confirm the non-existence of a problem or the absence of a threat. For instance, if an AI is programmed to identify “unsafe conditions,” and then another layer confirms “that condition is not unsafe,” we encounter a technical double negative. While the immediate outcome is an affirmation of safety, the underlying process and the certainty of that affirmation are critical. It begs the question: is it truly safe, or merely “not unsafe” based on limited or specific data points?
From Human Language to Machine Logic
For an AI system, every piece of input, every sensor reading, and every programmed rule contributes to a complex tapestry of decision-making. When engineers design the logic for autonomous flight or sophisticated mapping algorithms, they often use boolean expressions that can inherently create double negative scenarios. A common example in programming is NOT (NOT obstacle_detected). This simplifies to obstacle_detected, but the explicit double negation can arise from modular programming where one module asserts NOT A and another, higher-level module then evaluates NOT (result_of_first_module). Managing these constructs effectively is paramount to ensuring that the AI’s interpretation aligns with reality and desired operational outcomes.
Redundant Negative Feedback in AI & Sensors
One of the most common manifestations of a “double negative” in drone technology appears in sensor fusion and redundant system architectures designed for safety and reliability. Here, multiple sensors or diagnostic systems might independently report the absence of a particular state or condition.
Confirming Absence: A Double-Edged Sword
Consider an autonomous drone equipped with multiple obstacle avoidance sensors: lidar, radar, and computer vision. If the lidar reports “no obstacle detected,” and simultaneously the computer vision system analyzes its feed and concludes “no object present in trajectory,” this constitutes a form of redundant negative feedback. On the surface, this confirms a clear flight path, leading the AI to determine the path is “safe” or “not dangerous.” This “not (no obstacle)” effectively simplifies to “obstacle-free path.”
While redundancy is crucial for robust systems, ensuring that a “double negative” confirmation is genuinely robust requires deep insight into the capabilities and failure modes of each sensor. If both sensors are susceptible to the same type of environmental interference (e.g., dense fog affecting both optical and certain lidar systems), then their redundant “no detection” might not be a true confirmation of absence but rather a shared limitation leading to a false sense of security.
The “Not-Not” of Obstacle Avoidance and Safety Protocols
In practice, autonomous flight systems rely heavily on continuously evaluating “not unsafe” conditions. A drone’s flight controller might execute a command because it determines that “no critical system failure is present” (a negative condition) AND “no immediate environmental threat is detected” (another negative condition). When these two “no’s” are confirmed, the system proceeds. The robustness of this “not-not” logic lies in the independence and reliability of the checks. Each ‘not’ must be the result of a thorough, independent assessment. If, for instance, a diagnostic system reports system_status = OK (implicitly NOT FAILED), and a mission planner then evaluates IF (NOT system_status_is_FAILED), it creates a double negative logic for proceeding.
Challenges in Interpretation: False Positives from Double Negatives
The inherent challenge with relying on double negatives for decision-making is the potential for misinterpretation, leading to what could be analogous to a “false positive” in safety. If the system concludes “not (not safe)” and thereby determines “safe,” but one of the underlying “not” conditions was based on an incomplete or faulty detection, the resulting “safe” assessment is flawed. For example, if a vision system fails to detect a thin wire (it reports “no wire detected”), and a radar system also reports “no large object detected” (implicitly “no wire of this size detected”), the combined “not-not” could lead the drone to proceed, despite the presence of an unseen hazard. This emphasizes the need for diverse sensor modalities and advanced AI fusion algorithms that can identify and flag potentially ambiguous “non-detections.”
Logical Negation in AI Decision-Making and Control

Beyond sensor fusion, double negatives are integral to the logical constructs employed within AI algorithms themselves, influencing how autonomous systems plan, react, and learn.
Simplifying Complex Logic Trees
AI systems, particularly those governing autonomous flight, operate on vast and intricate decision trees or neural networks. Within these structures, complex boolean logic is frequently employed. A rule might state: IF NOT (is_collision_imminent) AND NOT (is_battery_critical), THEN continue_flight_path. Here, the AI is constantly evaluating the absence of negative conditions. While NOT (is_collision_imminent) directly asserts “no collision,” a more complex system might evaluate NOT (path_is_blocked_by_obstacle_AND_obstacle_is_unavoidable). The layers of negation can become deeply embedded, requiring meticulous design to ensure clarity and computational efficiency. Smart simplification of these logical expressions is crucial for real-time decision-making, where NOT (NOT A) becoming A can save precious milliseconds.
Programming for Robustness: Avoiding Ambiguity
To ensure robust decision-making, engineers actively work to minimize ambiguity arising from nested negations. This often involves transforming complex logical statements into simpler, equivalent forms that are easier for both humans to verify and for machines to process without error. Clear positive assertions (path_is_clear) are generally preferred over double negatives (NOT (path_is_blocked)). However, in certain state-machine designs or error-checking routines, the explicit evaluation of a double negative might be a deliberate design choice to confirm a state of normality or absence of anomaly from multiple perspectives. The challenge is ensuring that each NOT is robustly and independently verifiable.
Impact on Autonomous Flight Path Planning
In path planning, an autonomous drone’s AI evaluates potential routes by assessing what they are not. A path is deemed viable if it is NOT blocked, NOT restricted airspace, and NOT leading_to_critical_battery. Each of these ‘nots’ is derived from processing vast amounts of data—geospatial, environmental, and internal system diagnostics. The double negative comes into play when confirming that a non-problematic state exists. For instance, the system might confirm that “no airspace violation is detected” and “no terrain impediment is identified.” The AI then infers a positive, clear path, but the certainty of that positive is directly tied to the completeness and accuracy of the negative checks.
Double Negatives in Data Analysis for Remote Sensing & Mapping
The application of double negatives also extends to how drones collect and interpret data for mapping, environmental monitoring, and remote sensing. Here, identifying the absence of certain features or conditions can be as informative as identifying their presence.
Identifying What Isn’t There: A New Perspective
In remote sensing, analysis often focuses on detecting specific phenomena, like deforestation, crop disease, or urban expansion. However, a “double negative” approach can offer complementary insights. For example, instead of just mapping “deforested areas,” an AI might map “areas NOT undergoing deforestation.” This seemingly subtle shift in perspective can be crucial when combining datasets or confirming the efficacy of conservation efforts. An area is confirmed as “not deforested” if it does “not show signs of tree cover loss.” This is a more rigorous way of verifying a positive state (forest health) through negative observations.
Cross-Referencing Absence for Enhanced Accuracy
Imagine a scenario where an AI analyzes satellite imagery to detect changes in land use. One algorithm might detect “no new construction activity,” while another, using a different spectral band, detects “no significant change in vegetative index typically associated with construction.” By cross-referencing these two “non-detections” – a double negative confirmation – the AI gains higher confidence that an area has indeed remained stable. This method of using multiple, distinct negative confirmations strengthens the overall accuracy and reduces the likelihood of false positives in mapping and monitoring applications, providing a more robust affirmation of the status quo.
Mitigating the Risks and Harnessing the Potential
The technical interpretation of double negatives in advanced drone technology highlights both challenges and opportunities. While the linguistic roots suggest ambiguity, in engineered systems, they represent a method for rigorous confirmation of absence or a specific logical structure.
Redundancy vs. Redundancy Errors
The key to successful implementation of double negative logic is distinguishing between beneficial redundancy and dangerous redundancy errors. Beneficial redundancy occurs when independent systems confirm the absence of a negative condition, bolstering confidence. Dangerous redundancy errors arise when multiple systems fail to detect a condition due to common-mode failures or shared blind spots, leading to a false “not-not” positive. AI systems must be designed with diverse sensor modalities, robust data fusion algorithms, and comprehensive validation protocols to truly confirm the positive implications of a double negative.
Future Directions: AI’s Semantic Understanding
As AI capabilities advance, especially in natural language processing and semantic understanding, future drone systems might move towards more nuanced interpretations of complex logical states. This includes an AI that can not only process NOT (NOT A) but also understand the implications of two independent systems reporting “no problem.” This means a deeper contextual understanding, moving beyond simple boolean logic to a probabilistic assessment of certainty. The goal is to build AI that truly understands when “not not” means “yes” with absolute confidence, and when it merely indicates “lack of definitive negative evidence,” allowing for more informed and safer autonomous operations.