
BMW’s xDrive system, while primarily known for its groundbreaking application in automotive traction and stability, offers a profound case study in the engineering principles of dynamic stabilization and intelligent sensor integration – concepts fundamentally critical to the realm of flight technology. Understanding xDrive, therefore, transcends its terrestrial origins, providing valuable insights into the sophisticated control mechanisms that govern stability, agility, and responsiveness in complex, multi-axis systems, whether on ground or in the air. It’s a testament to how advanced engineering tackles the universal challenges of maintaining equilibrium and directed motion under varying conditions, making its operational philosophy highly relevant to disciplines such like autonomous flight, drone stabilization, and UAV navigation.
The Core Principles of Dynamic Stabilization
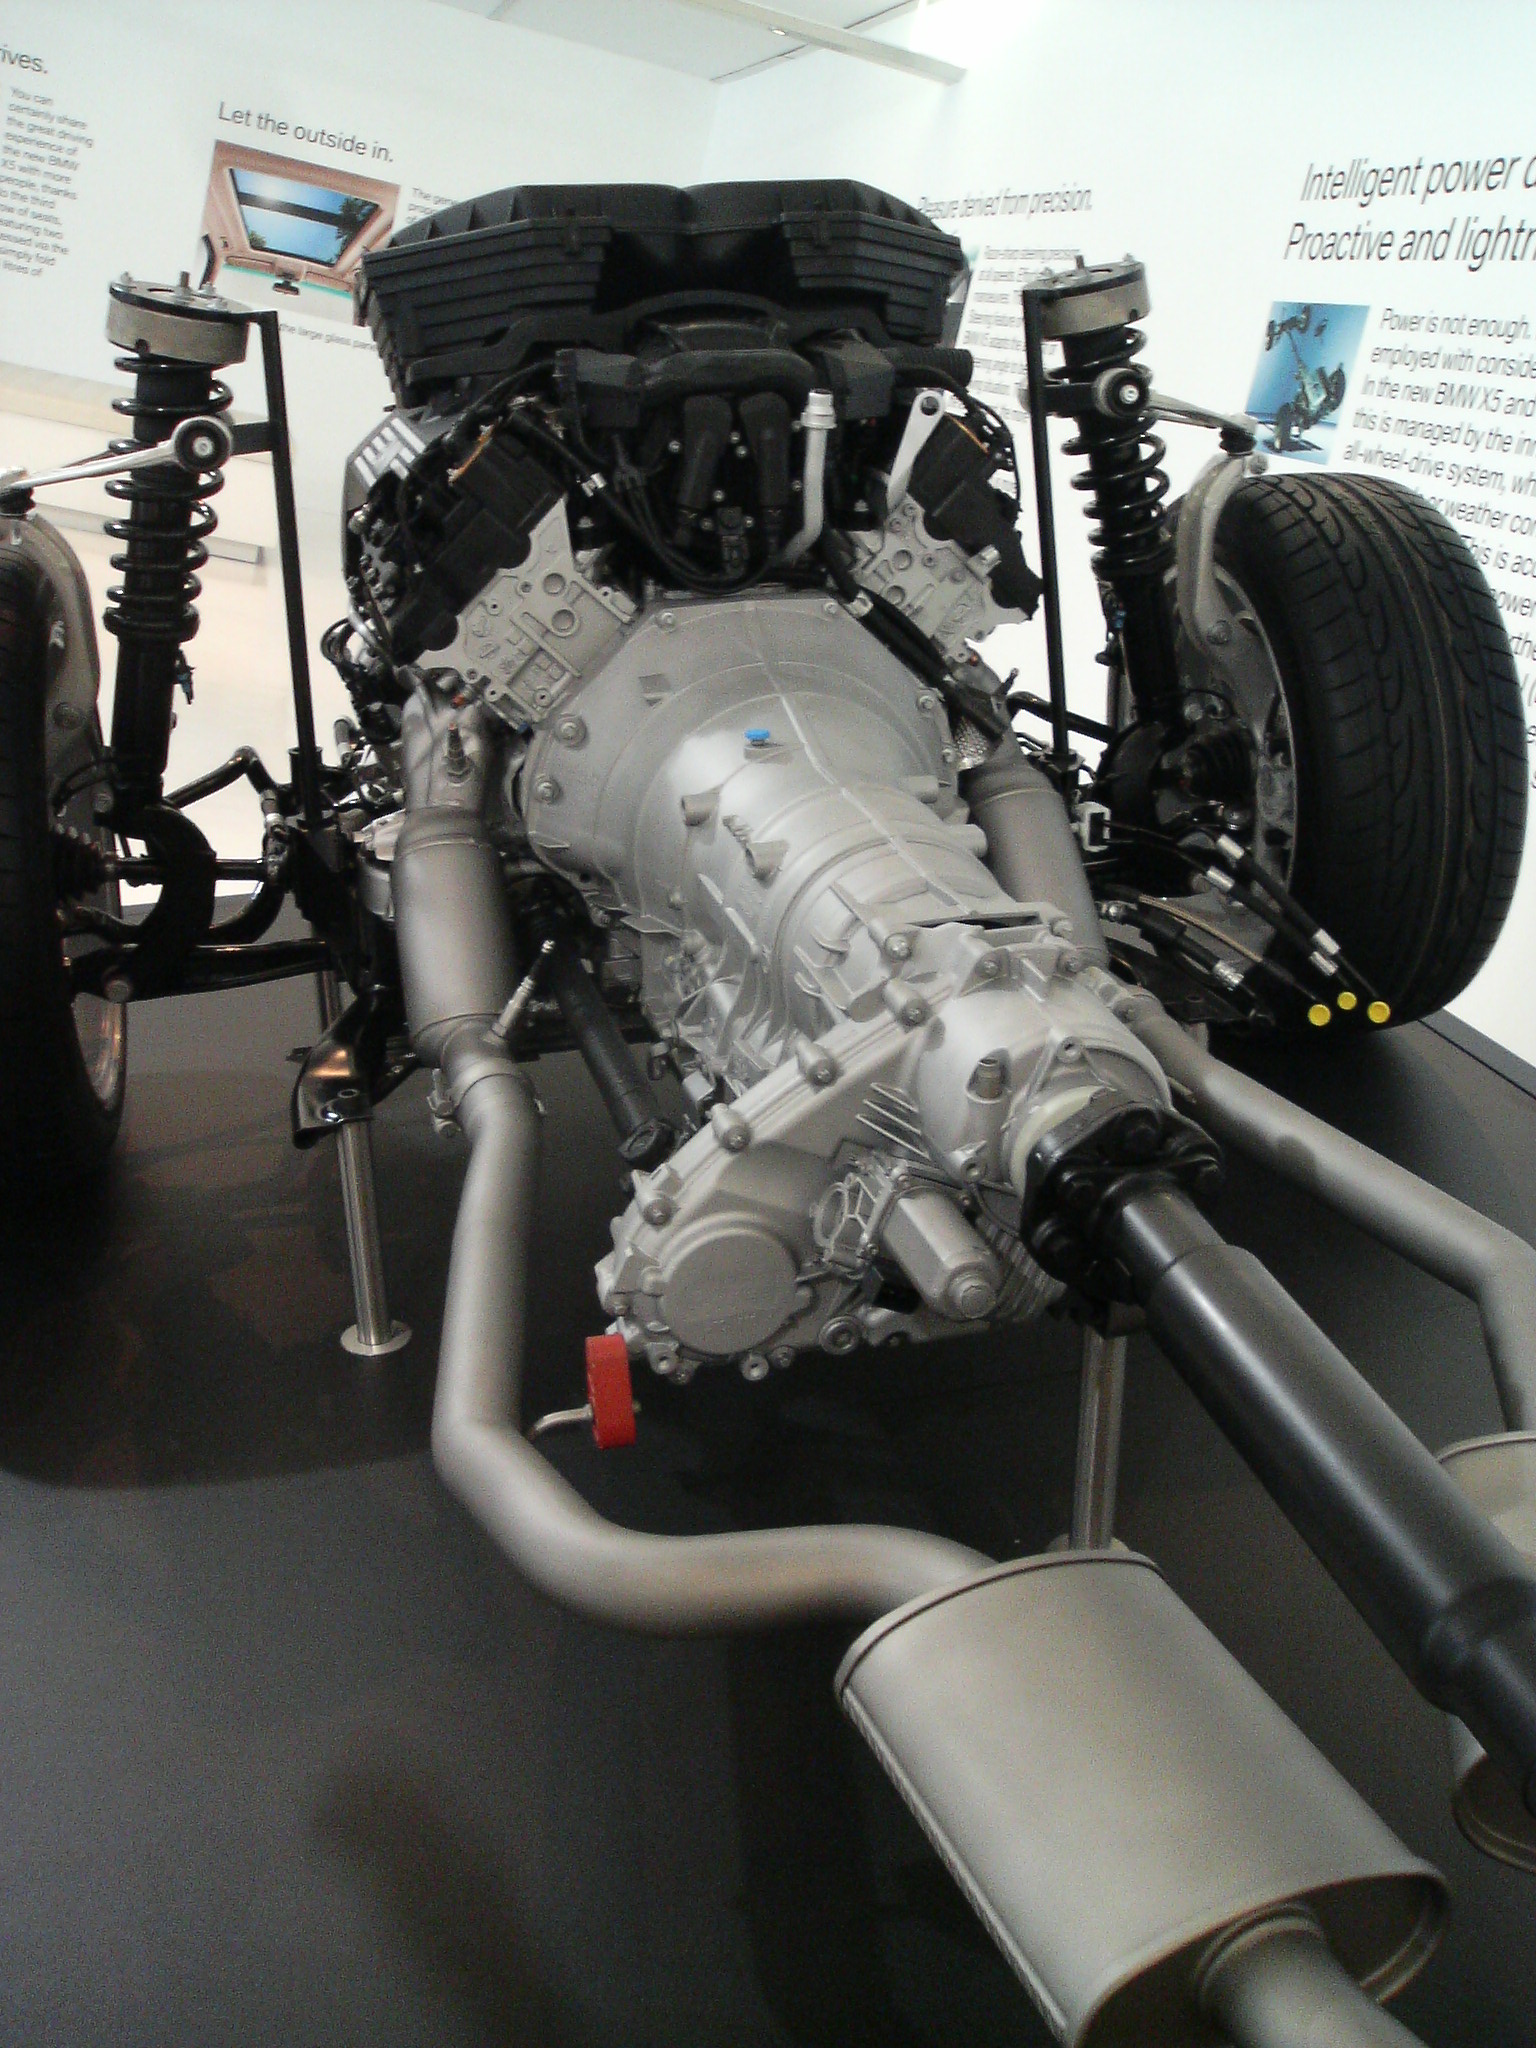
At its heart, BMW xDrive is an intelligent all-wheel-drive system engineered to optimize traction and driving dynamics in real-time. Its operational prowess stems from a sophisticated interplay of sensors, predictive algorithms, and rapid mechanical responses, all geared towards maintaining optimal stability and control. These are precisely the same foundational elements that underpin advanced stabilization systems in modern flight technology.
Sensor Fusion and Real-time Data Analysis
Like a high-performance drone constantly assessing its environment, xDrive relies on an intricate network of sensors. Wheel speed sensors, steering angle sensors, throttle position sensors, and yaw rate sensors continuously feed data to a central control unit. This stream of information provides a comprehensive, real-time snapshot of the vehicle’s dynamic state: is a wheel slipping? Is the vehicle oversteering or understeering? How much grip is available?
In flight technology, a similar, even more complex, sensor fusion process is vital. Inertial Measurement Units (IMUs) combining accelerometers, gyroscopes, and magnetometers provide critical data on orientation, angular velocity, and linear acceleration. Barometric altimeters, GPS receivers, and vision-based sensors add layers of environmental awareness. Just as xDrive processes ground-based inputs to understand traction, flight controllers synthesize airborne data to comprehend altitude, velocity, attitude, and external forces like wind shear. The ability to rapidly collect, process, and interpret this diverse data stream is paramount for both systems to make informed, instantaneous adjustments.
Predictive Traction Management
A key differentiator of xDrive is its proactive, rather than reactive, nature. It doesn’t wait for a wheel to spin to intervene; instead, it anticipates potential traction loss based on driver input and sensor data. For instance, if the steering wheel is turned sharply while accelerating, xDrive can predict that the outer wheels will soon require more torque to maintain stability and prevent understeer. It then pre-emptively shifts power distribution to the wheels that can best utilize it, often within milliseconds.
This predictive capability mirrors the advancements in autonomous flight and drone stabilization. Modern flight controllers don’t just react to a gust of wind; they can, to some extent, anticipate its effects and prepare compensatory actions. Through advanced algorithms and machine learning, UAVs are increasingly capable of predicting trajectory deviations based on environmental models and internal dynamic states, allowing for smoother, more efficient flight paths and more resilient stabilization against disturbances. The concept of anticipating and mitigating instability before it fully manifests is a shared, high-level engineering goal.
Analogies in Flight Technology: Ground to Air
The operational philosophy of xDrive, focused on dynamic power allocation and precise torque vectoring to maintain optimal grip and directional control, provides compelling analogies to how stabilization systems operate in flight.
Gyroscopic Stability and Yaw Control
In an xDrive-equipped vehicle, the system constantly monitors the vehicle’s yaw rate – its rotation around its vertical axis. If the vehicle begins to oversteer (the rear end sliding out), xDrive can rapidly direct more power to the front wheels and/or reduce power to the rear, helping to pull the vehicle back into line. Conversely, if it understeers, power can be shifted to the rear, aiding in rotation. This precise management of rotational forces is fundamental.
In multi-rotor flight technology, maintaining yaw stability is achieved through differential thrust from the propellers. To yaw left, the left-side propellers might slightly decrease speed while the right-side propellers increase speed, creating a torque imbalance that rotates the drone. Similarly, pitch and roll are managed by adjusting thrust across different sets of propellers. The core principle – applying corrective forces to counteract unwanted rotational motion – is directly analogous to xDrive’s torque vectoring for directional control. Both systems are effectively acting as sophisticated “electronic differentials” for distributing motive force to stabilize angular motion.
Adaptive Power Distribution
xDrive’s most celebrated feature is its ability to continuously and infinitely vary the power split between the front and rear axles, from 0:100 to 100:0. In normal conditions, it might send 40% of power to the front and 60% to the rear. But on a slippery patch, it can instantaneously send nearly all power to the wheels with traction. This adaptive distribution ensures that motive force is always applied where it is most effective, maximizing propulsion and stability.
Consider a multi-rotor drone in gusty winds. Its flight controller must constantly adjust the thrust of each individual motor to maintain a desired position and orientation. A strong side gust might require increased thrust from the motors on the windward side and decreased thrust on the leeward side to prevent being blown off course. This is an airborne form of adaptive power distribution, where “power” (thrust) is dynamically allocated across multiple “contact points” (propellers) to maintain stability and execute commanded movements. The ability to individually control and adapt motive force across multiple axes is a cornerstone of both xDrive and advanced flight stabilization.
Engineering for Extreme Conditions
Both xDrive and sophisticated flight technology are designed to perform reliably and safely under challenging and unpredictable conditions, pushing the boundaries of what integrated control systems can achieve.
Overcoming Slippage and Unstable Surfaces
The primary design goal of xDrive is to provide exceptional traction on low-grip surfaces like snow, ice, or gravel, and to enhance stability during dynamic maneuvers on dry pavement. It achieves this by intelligently managing wheel slip. If a wheel begins to spin excessively, xDrive can instantaneously apply the brake to that wheel, forcing the power to be redirected to the wheels that still have grip. This intelligent interaction between traction control and power distribution allows the vehicle to maintain momentum even when multiple wheels lose traction.
In flight, particularly with UAVs operating in complex environments, similar challenges arise. Turbulence, varying air densities, or even slight structural imbalances can introduce instability. The flight controller must actively counteract these disturbances, much like xDrive counteracts wheel slip. By rapidly adjusting individual motor speeds, the flight system “grips” the air, maintaining a stable platform and preventing uncontrolled drift or rotation. The concept of active compensation for external forces and dynamic surface interactions is a shared engineering challenge.
The Role of Integrated Control Units
The brain of the xDrive system is an incredibly fast and powerful electronic control unit (ECU). This ECU processes vast amounts of sensor data, runs complex algorithms, and sends commands to the transfer case (which manages power split), the engine, the transmission, and the braking system, all in fractions of a second. This holistic integration of various vehicle systems under a centralized, intelligent controller is what gives xDrive its seamless and effective operation.
In flight technology, the Flight Controller (FC) plays an identical role. It is the central nervous system, integrating data from IMUs, GPS, barometers, and potentially vision systems. It then computes necessary adjustments and commands individual Electronic Speed Controllers (ESCs) to alter motor speeds, controlling thrust, yaw, pitch, and roll. Furthermore, it manages navigation, waypoint following, and autonomous behaviors. The principle of a highly integrated, intelligent control unit orchestrating complex mechanical and electrical systems for dynamic stabilization is a direct parallel between xDrive and modern flight technology.
The Future of Integrated Control Systems
The evolution of systems like xDrive and advanced flight stabilization points towards a future where intelligent, adaptive control is paramount across all domains of motion and navigation.
AI and Machine Learning in Stabilization
BMW continues to refine xDrive with advancements in software and integration with other vehicle systems, moving towards even more predictive and personalized driving experiences. The trend is towards using artificial intelligence and machine learning to interpret more complex driving scenarios, learn driver preferences, and optimize system responses.
Similarly, in flight technology, AI and machine learning are revolutionizing stabilization. Adaptive flight controllers can learn the unique aerodynamic characteristics of a specific drone, compensate for wear and tear, and even predict optimal control inputs in novel environmental conditions. This allows for more robust autonomous flight, better performance in challenging weather, and more energy-efficient operations. The pursuit of systems that can learn, adapt, and make increasingly intelligent decisions autonomously is a shared frontier.
Cross-Platform Applicability of Advanced Dynamics
The core engineering lessons from BMW xDrive – encompassing rapid sensor data processing, predictive control, adaptive power distribution, and the seamless integration of diverse subsystems for dynamic stability – are not confined to automobiles. These principles are universally applicable to any system requiring precise control over motion and equilibrium in a dynamic environment. From advanced robotics navigating uneven terrain to sophisticated aerospace vehicles maintaining stability in extreme atmospheric conditions, the fundamental challenges and solutions are remarkably similar. xDrive serves as a powerful example of how robust, intelligent stabilization systems are engineered, providing a tangible model for understanding and developing the flight technologies of tomorrow.