
Cross Traffic Alert (CTA), a term traditionally associated with automotive safety systems, describes a crucial technology designed to detect approaching vehicles or obstacles from the side, particularly when a vehicle’s primary line of sight is obstructed. While its origins lie in ground vehicles, the concept of a Cross Traffic Alert system is profoundly relevant and increasingly critical for the safe and efficient operation of Unmanned Aerial Vehicles (UAVs), commonly known as drones. In the realm of flight technology, an aerial CTA system transcends simple obstacle detection, evolving into a sophisticated collision avoidance mechanism vital for maintaining airspace safety, especially as drone operations become more autonomous and complex.
Defining Cross Traffic Alert in UAV Operations
At its core, a Cross Traffic Alert system for UAVs aims to identify and warn the drone or its operator of potential collision threats originating from vectors perpendicular or oblique to the drone’s current flight path. Unlike forward-facing obstacle avoidance systems that primarily detect objects directly in front of the drone, an aerial CTA is designed to monitor a broader lateral perimeter, crucial for scenarios where other aerial vehicles, fixed structures, or unexpected environmental elements might intersect the drone’s trajectory.
Automotive Origins and Aerial Adaptation
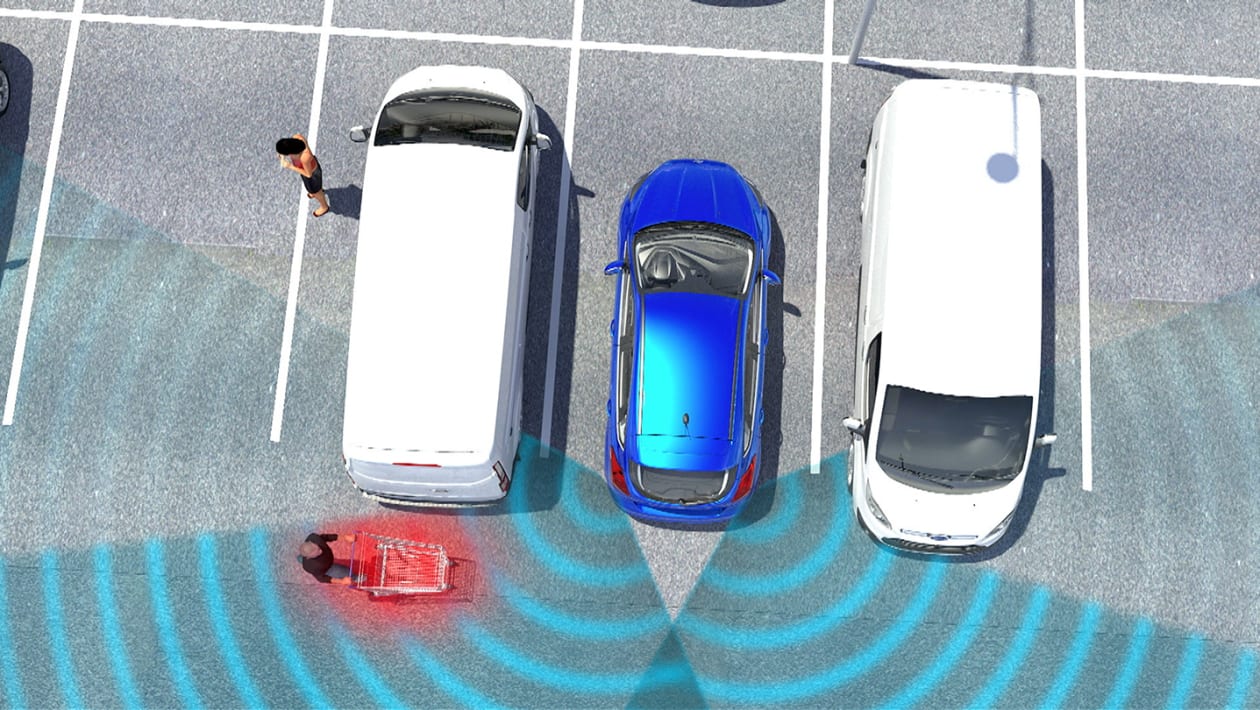
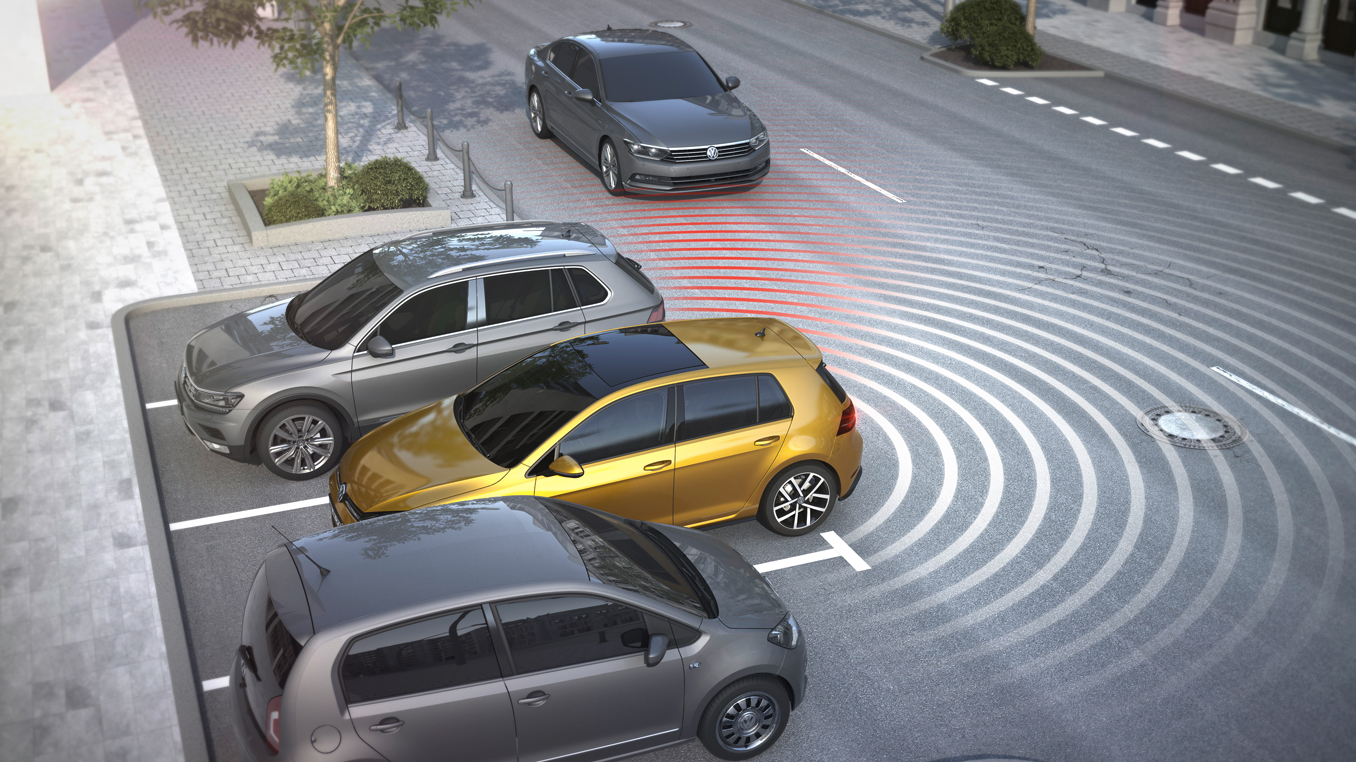
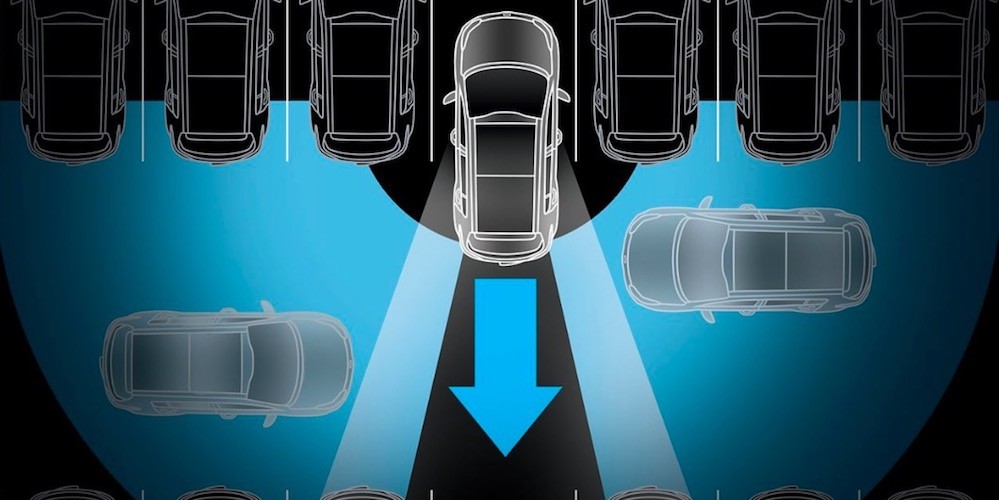
In automobiles, CTA systems are invaluable when reversing out of a parking space into oncoming traffic or navigating blind intersections. They typically utilize radar sensors mounted on the rear bumper to detect vehicles approaching from either side, alerting the driver with visual and auditory cues. The adaptation of this concept to drones presents unique challenges and expanded functionalities. Drones operate in three-dimensional space, often at varying speeds and altitudes, sharing airspace with diverse entities ranging from other drones and manned aircraft to birds and static structures like towers. Therefore, an aerial CTA must be far more dynamic, precise, and capable of processing complex environmental data in real-time. It moves beyond mere “alerting” to encompass sophisticated trajectory prediction and, increasingly, autonomous avoidance maneuvers.
Beyond Visual Line of Sight (BVLOS) Imperative
The necessity for robust Cross Traffic Alert systems in UAVs is underscored by the growing prevalence of Beyond Visual Line of Sight (BVLOS) operations. In BVLOS scenarios, the remote pilot cannot physically see the drone or its surrounding airspace, making reliance on onboard sensors and intelligent flight technology paramount. For applications such as long-range infrastructure inspection, package delivery, aerial mapping of vast areas, or emergency response, BVLOS capabilities unlock immense potential. However, they also introduce significant safety challenges, particularly concerning collision avoidance. An effective aerial CTA system provides the critical situational awareness necessary for drones to safely navigate complex, shared airspace autonomously, detecting unseen threats and ensuring compliance with air traffic regulations even when human oversight is limited.
Core Technologies Powering Aerial Cross Traffic Alert Systems
The development of sophisticated Cross Traffic Alert systems for drones relies heavily on the integration of multiple advanced flight technologies. These systems combine various sensors with powerful processing units and intelligent algorithms to perceive, interpret, and react to the drone’s dynamic environment.
Sensor Fusion: The Eyes and Ears of UAVs
No single sensor type can provide all the necessary data for comprehensive cross-traffic detection and avoidance. Therefore, aerial CTA systems employ sensor fusion, combining data from multiple modalities to create a robust and redundant environmental perception.
- Radar (mmWave, Short-Range): Millimeter-wave (mmWave) radar sensors are highly effective for detecting moving objects, including other drones or aircraft, at significant distances regardless of lighting or weather conditions (fog, smoke, light rain). Short-range radar can also be used for localized detection around the drone. They provide precise velocity and range data, crucial for predicting trajectories.
- Lidar (Light Detection and Ranging): Lidar systems emit laser pulses and measure the time it takes for them to return, creating a detailed 3D map of the drone’s surroundings. This is excellent for detecting both static obstacles (buildings, trees, power lines) and moving objects, providing high spatial resolution that complements radar’s velocity data. While effective, lidar can be impacted by heavy precipitation or dust.
- Vision Systems (Cameras, AI Object Recognition): High-resolution cameras, coupled with advanced Artificial Intelligence (AI) and machine learning algorithms, enable the drone to “see” and identify objects. Vision systems can classify objects (e.g., distinguishing between a bird, another drone, or a parachute), estimate their size, and track their movement. Stereo cameras can also provide depth perception. AI-powered object recognition significantly enhances the system’s ability to interpret complex visual scenes and prioritize threats.
- Ultrasonic Sensors: For very close-range obstacle detection, particularly during takeoff, landing, or confined space maneuvers, ultrasonic sensors provide reliable data. They are less effective at longer distances or for detecting fast-moving objects but offer excellent precision in immediate proximity.
- ADS-B In / FLARM: For detecting manned aircraft and equipped drones, Automatic Dependent Surveillance-Broadcast (ADS-B) In receivers (and similar technologies like FLARM, popular in general aviation and gliders) are critical. These systems receive positional data directly from other aircraft, providing precise location, altitude, speed, and trajectory information well in advance, even beyond sensor line-of-sight. Integrating ADS-B In data into an aerial CTA system offers a layer of cooperative awareness that significantly enhances safety.
Advanced Processing and Predictive Algorithms
Raw sensor data is meaningless without sophisticated processing. Dedicated onboard processors, often utilizing GPUs or specialized AI chips, are required to handle the immense data streams in real-time.
- Real-time Data Analysis: The system must continuously analyze data from all sensors, fusing it into a single, comprehensive environmental model. This involves filtering noise, synchronizing sensor inputs, and correlating detections.
- Trajectory Prediction: Based on the detected position, velocity, and heading of potential threats, predictive algorithms forecast their future path. This is vital for determining if an intersection with the drone’s own trajectory is probable and, if so, when and where the closest point of approach (CPA) will occur.
- Collision Risk Assessment: The system evaluates the probability and severity of a potential collision. Factors considered include distance to CPA, time to CPA (Tau), relative velocity, and the maneuverability limits of the drone itself. This assessment helps in prioritizing threats and determining the appropriate evasive action.
Applications and Scenarios for Drone Cross Traffic Alert
The implementation of advanced CTA systems profoundly impacts the utility and safety of drones across various industries.
Autonomous Navigation in Complex Environments
For drones operating autonomously in urban canyons, dense forests, or near industrial complexes, an aerial CTA system is indispensable. These environments often present dynamic obstacles and limited visibility. CTA ensures the drone can detect and react to unexpected intrusions, such as other drones, wildlife, or even moving vehicles on the ground, maintaining its programmed flight path while prioritizing safety.
Airspace Management and UTM Integration
As drone traffic increases, the development of Unmanned Aircraft System (UAS) Traffic Management (UTM) systems becomes crucial. Aerial CTA systems provide essential real-time data to UTM platforms, allowing for better situational awareness across the entire airspace. By continuously reporting detected threats and avoidance maneuvers, drones equipped with CTA contribute to a more holistic and predictive airspace picture, enabling better deconfliction strategies and enhancing overall airspace safety.
Enhanced Safety for Delivery and Inspection Drones
Drones performing package delivery or critical infrastructure inspections often fly pre-programmed routes. A cross-traffic alert system ensures that these operations can proceed safely, even if an unexpected aircraft, drone, or environmental factor deviates into their path. For sensitive operations like medical supply delivery, where mission success and safety are paramount, CTA systems offer an additional layer of reliability, preventing costly and dangerous mid-air incidents.
Swarm Robotics and Formation Flight
In applications involving multiple drones flying in close proximity (swarm robotics or formation flight), cross-traffic detection is not just about avoiding external threats but also about preventing collisions between the drones in the swarm. Sophisticated CTA algorithms enable cooperative collision avoidance, where drones communicate their intended maneuvers to each other, ensuring smooth and safe coordinated flight paths, even when performing complex maneuvers or adapting to unforeseen conditions.
Challenges and Future Directions
While current aerial CTA technology is advanced, ongoing research and development aim to overcome existing limitations and unlock even greater capabilities.
Miniaturization and Power Efficiency
Integrating multiple sophisticated sensors and powerful processing units onto small, lightweight drones presents a significant engineering challenge. Future developments will focus on further miniaturizing these components, reducing their power consumption, and optimizing their integration without compromising payload capacity or flight endurance. This will make advanced CTA accessible to a wider range of drone platforms.
Regulatory Frameworks and Standardization
For widespread adoption of BVLOS operations and complex drone missions, robust regulatory frameworks and standardized protocols for aerial CTA systems are essential. This includes establishing minimum performance standards, communication protocols for cooperative avoidance (e.g., drone-to-drone communication), and clear guidelines for how these systems interact with UTM infrastructure. Harmonization across national and international aviation authorities will be key.
AI and Machine Learning for Proactive Avoidance
The future of aerial CTA will heavily leverage advancements in Artificial Intelligence and machine learning. This includes developing more sophisticated neural networks that can not only detect and track objects but also predict their intent and anticipate complex, multi-object interactions. AI will enable drones to make more nuanced, proactive avoidance decisions, learning from past encounters and continuously improving their safety performance in increasingly dynamic and unpredictable environments. This shift towards truly intelligent, self-aware collision avoidance represents the pinnacle of flight technology for the next generation of autonomous aerial systems.