
In the intricate world of drone technology and innovation, where autonomous flight, sophisticated mapping, and real-time remote sensing are commonplace, the seamless transmission of data is not merely important—it is foundational. At the very heart of this data exchange lies a concept often taken for granted but critically essential: the datagram. Far from being an abstract networking term confined to server rooms, understanding the datagram is key to appreciating how drones communicate, process information, and execute complex tasks in dynamic environments. It represents a fundamental unit of data, a digital package dispatched across networks, enabling the intelligent operations we now expect from advanced unmanned aerial vehicles (UAVs).
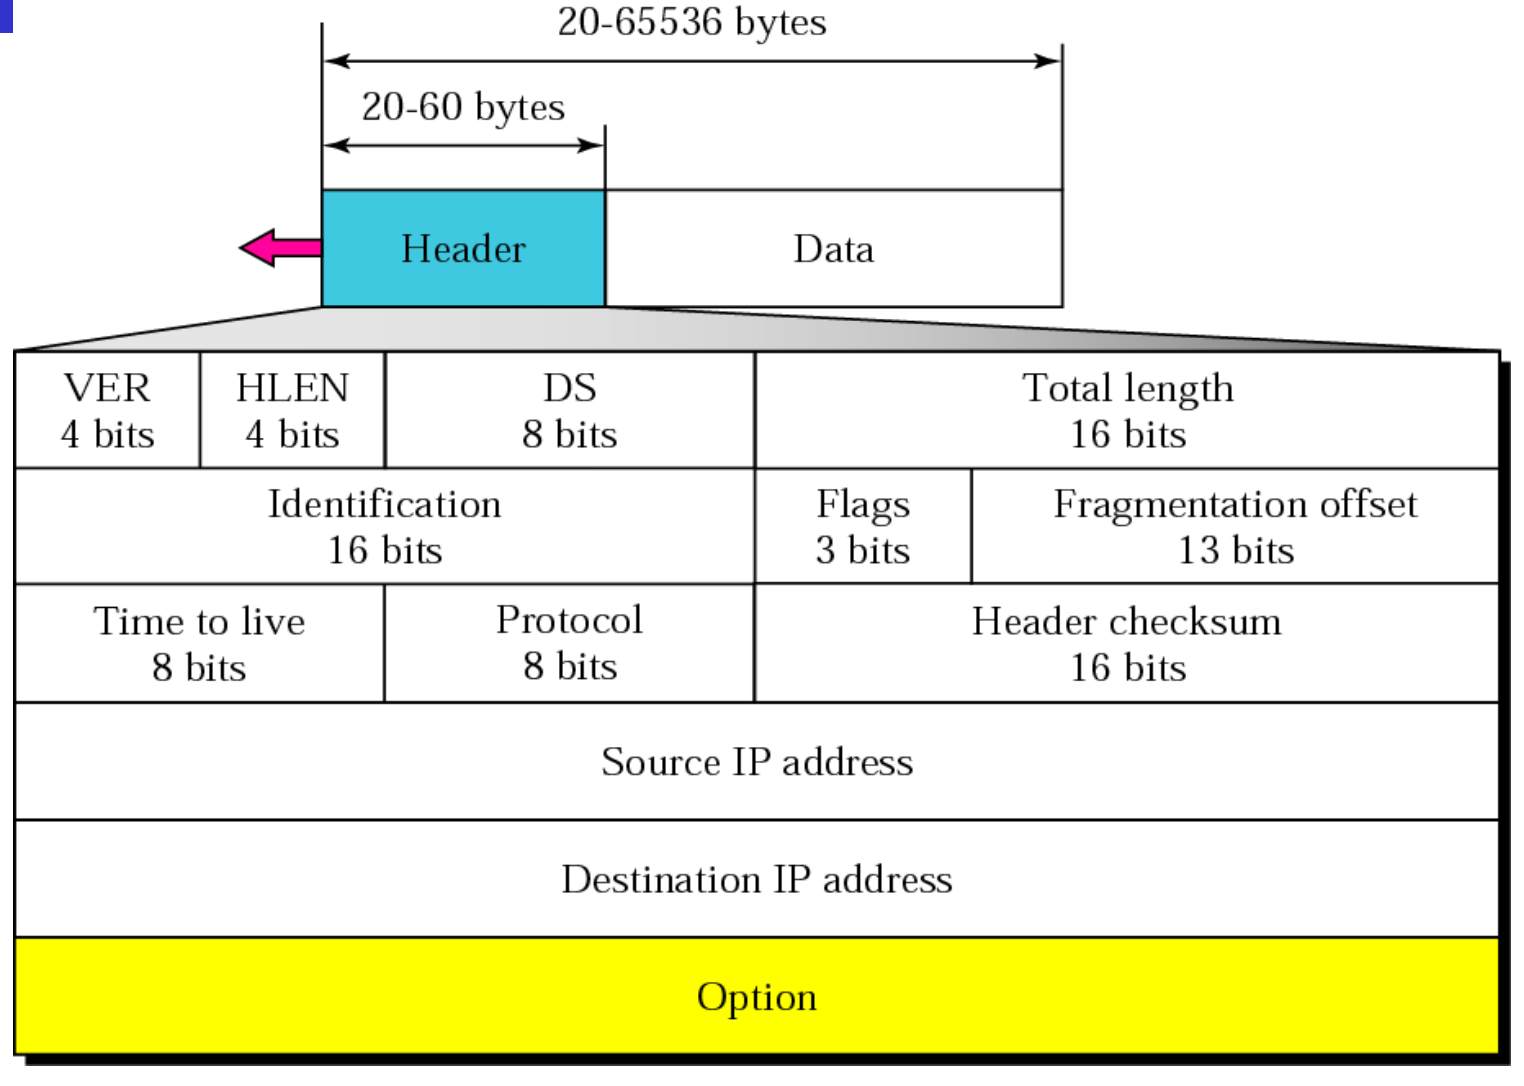
The Fundamental Nature of Datagrams
A datagram is, in essence, a self-contained, independent unit of data designed for transmission over a packet-switched network. Unlike a stream of continuous data, a datagram carries all the necessary information within itself to be routed from its source to its destination without relying on prior communication exchanges or dedicated connections between the two endpoints. This characteristic defines its unique advantages and challenges within the realm of high-tech applications like drone operation.
Connectionless and Independent
The defining feature of a datagram is its connectionless nature. This means that before sending a datagram, the sender and receiver do not establish a dedicated, persistent communication link, nor do they agree on a specific sequence for data delivery. Each datagram is treated as an individual entity, carrying its own source and destination addresses, along with the payload data. It’s akin to sending a letter through the postal service: each letter contains the full address and can be sent independently, without needing to inform the post office or the recipient beforehand that a letter is coming, or guaranteeing that it arrives in a specific order relative to other letters.
This independence grants significant flexibility and efficiency in certain scenarios. Networks can handle datagrams on a best-effort basis, meaning they attempt to deliver them but don’t guarantee arrival, order, or freedom from duplication. The routing of each datagram can occur dynamically, potentially taking different paths through the network depending on current traffic conditions, network congestion, or available routes. This adaptability is crucial for wireless drone communications, where network conditions can fluctuate rapidly.
The Trade-offs of Simplicity
While the simplicity and independence of datagrams offer significant benefits, particularly in terms of overhead and speed, they come with inherent trade-offs. The lack of a predefined connection or acknowledgment mechanism means that datagrams are inherently unreliable at the network layer. There are no built-in guarantees for:
- Delivery: A datagram might be lost due to network congestion, errors, or hardware failures, and the sender will not be notified.
- Order: Datagrams sent sequentially might arrive at their destination out of order because they could travel along different network paths.
- Duplication: A datagram might be duplicated in transit, and the recipient might receive multiple copies.
For many critical drone functions, such unreliability at the base layer would be unacceptable. However, this foundational concept forms the basis upon which higher-level protocols build reliability and ordered delivery when needed, by adding error checking, sequencing, and acknowledgment mechanisms.
Datagrams in Drone Communication Systems
The principles of datagrams are deeply embedded in the communication architectures that underpin modern drone technology. From the real-time transmission of sensor data to the intricate choreography of autonomous flight commands, datagrams facilitate the rapid and efficient exchange of information that makes these innovations possible.
Command & Control and Telemetry
In drone operations, command and control (C2) links are paramount. These links transmit critical instructions from a ground control station to the drone, such as flight path adjustments, altitude changes, or payload activation commands. Conversely, telemetry data—including GPS coordinates, battery status, altitude, speed, and sensor readings—flows from the drone back to the ground station. For many of these communications, especially those requiring rapid updates with minimal overhead, datagrams form the underlying transport mechanism.
For instance, small, frequent updates to a drone’s position in a swarm or minor adjustments to a flight trajectory can be efficiently sent as datagrams. While critical commands (like “land immediately”) might utilize higher-level protocols built on datagrams to ensure reliability, the efficiency of datagrams is exploited for non-critical, yet frequent, status updates. This approach minimizes latency and resource consumption, which are vital considerations for battery-powered aerial platforms.
Real-time Data Streaming for Remote Sensing and Mapping
Drones equipped for remote sensing and mapping tasks generate vast amounts of data, including high-resolution imagery, LiDAR scans, thermal readings, and multispectral data. Transmitting this data back to a ground station or an edge computing device often involves streaming, where speed and throughput are critical. While certain data streams might require guaranteed delivery for complete data integrity, many real-time applications prioritize speed.
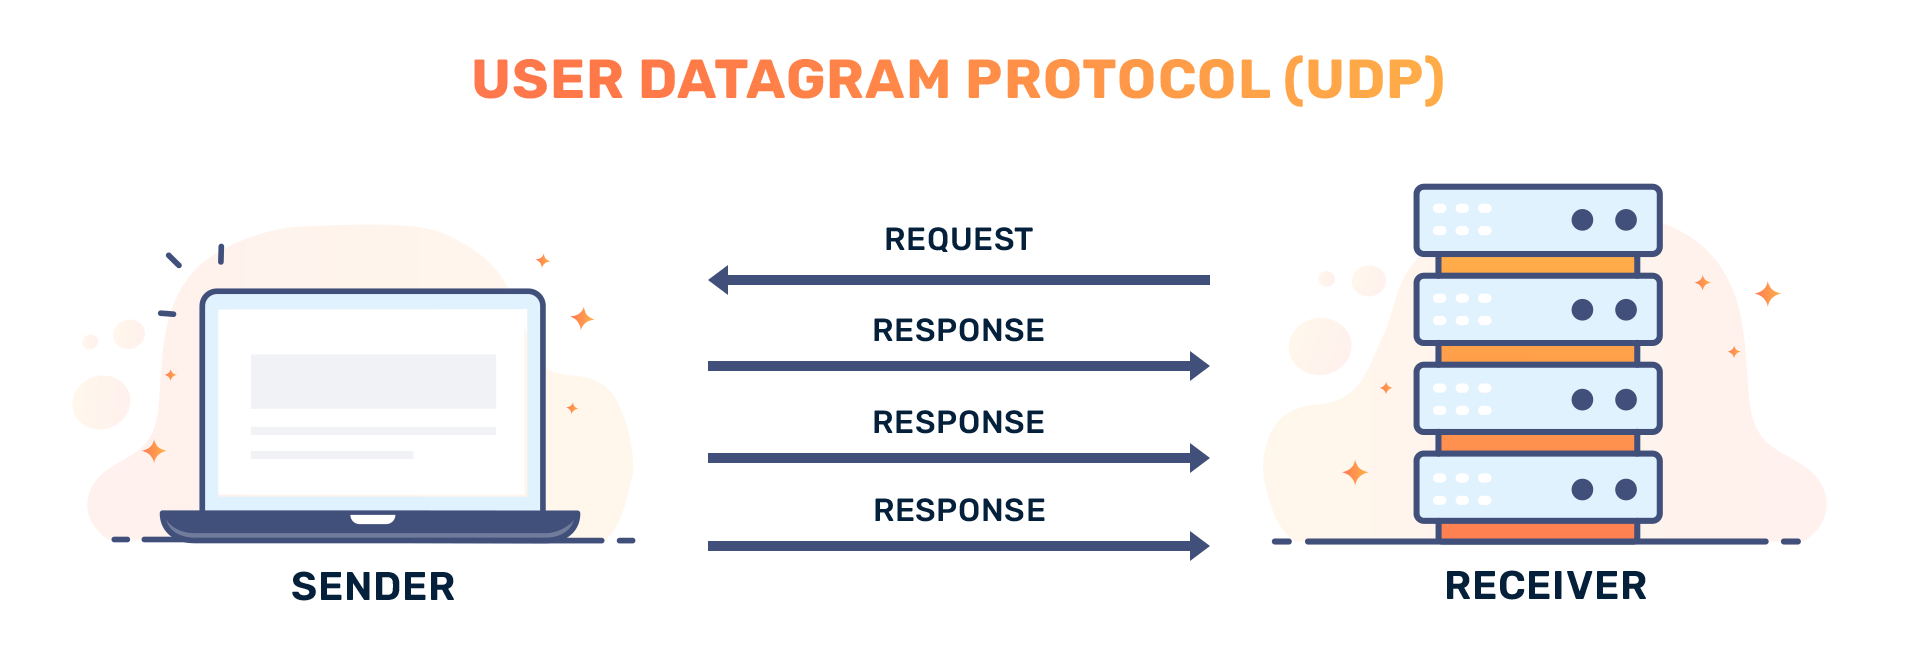
For example, when a drone is surveying a large area for quick assessment (e.g., agricultural monitoring for immediate problem detection), small losses in a continuous stream of image segments might be tolerable if it means faster overall data acquisition and initial processing. Datagrams, through protocols like UDP (User Datagram Protocol), are ideal for such scenarios, allowing for high-volume, low-latency transmission where occasional packet loss is less detrimental than delays introduced by retransmission mechanisms. This enables faster decision-making for applications like disaster response or dynamic environmental monitoring.
FPV and Low-Latency Applications
First-Person View (FPV) systems, though sometimes categorized under ‘Cameras & Imaging,’ are heavily reliant on the underlying communication technology for their defining characteristic: low-latency video transmission. The immersive experience of FPV racing or cinematic flying hinges on the pilot receiving video feedback with minimal delay. Here, the connectionless, best-effort nature of datagrams is a distinct advantage.
Video streams are inherently tolerant to some degree of packet loss. A lost datagram carrying a small portion of a video frame might result in a momentary glitch or pixelation, but retransmitting that lost data would introduce unacceptable delay, making real-time control impossible. Therefore, FPV systems typically utilize datagram-based protocols to prioritize speed over absolute fidelity, allowing pilots to react instantly to the drone’s perspective. This principle extends to other real-time control loops where immediate action is more critical than guaranteed data integrity for every single packet.
The Role of UDP and Higher-Level Protocols
While the concept of a datagram is fundamental, in practice, data transmission over networks involves various protocols that utilize or build upon datagrams. The User Datagram Protocol (UDP) is the most direct implementation of the datagram concept, widely used in drone applications.
UDP: Speed Over Reliability
UDP is a lightweight, connectionless transport layer protocol that provides a mechanism for applications to send datagrams over an IP network. It does not provide any reliability, flow control, or error recovery mechanisms. When an application sends data via UDP, it simply hands the datagram to the IP layer for delivery, with no guarantees.
This “fire and forget” approach is precisely why UDP, and by extension, datagrams, are so valuable in drone technology. For applications where low latency and high throughput are more critical than absolute reliability—such as live video streaming, real-time sensor updates, and certain types of command signaling—UDP is the protocol of choice. Its minimal overhead means less processing power and less bandwidth are consumed, both precious resources on an autonomous aerial platform. In a swarm of drones, for example, each drone might broadcast its position using UDP datagrams to its neighbors, allowing for rapid, decentralized awareness even if a few position updates are occasionally lost.
Building Reliability on Datagrams for Critical Operations
Despite the inherent unreliability of datagrams and UDP, many critical drone operations do require guaranteed delivery and ordered data. For these scenarios, higher-level protocols are built on top of the datagram foundation to introduce the necessary reliability. The Transmission Control Protocol (TCP), for example, provides reliable, ordered, and error-checked delivery of a stream of octets between applications running on hosts communicating via an IP network. TCP establishes a connection, segments data into datagrams, numbers them, acknowledges receipt, and retransmits lost packets.
For drones, this means that while telemetry might use UDP datagrams for speed, the critical firmware update or the precise execution of a pre-planned autonomous mission segment involving complex synchronization might utilize TCP or a custom reliable protocol. These protocols effectively encapsulate application data within datagrams but add a layer of intelligence that manages retransmissions, sequencing, and acknowledgments. The underlying datagram remains the transport unit, but the application gains the necessary assurances for critical functions, illustrating how innovation often involves stacking layers of functionality on top of fundamental building blocks.
Future Innovations and the Datagram Foundation
As drone technology continues to push the boundaries of autonomy, connectivity, and data processing, the underlying principles of datagram communication will remain pivotal, evolving with new networking paradigms.
5G and Drone Networking
The advent of 5G networks promises unprecedented bandwidth, ultra-low latency, and massive connectivity, all of which are transformative for drones. For drones operating beyond visual line of sight (BVLOS), transmitting high-definition sensor data for real-time analysis, or participating in complex coordinated operations, 5G will enable more efficient and reliable datagram transmission. The inherent low-latency characteristics of 5G align perfectly with the need for immediate data exchange that datagrams facilitate. This will allow for more sophisticated remote control, better real-time decision-making, and the expansion of drone services into new urban and rural environments.
Edge Computing and Distributed Drone Intelligence
The future of drone innovation points towards greater autonomy and distributed intelligence, often facilitated by edge computing. Instead of sending all raw data to a distant cloud server, drones can process information closer to the source (at the “edge” of the network), reducing latency and bandwidth requirements. Datagrams will play a critical role here, enabling rapid communication between drones themselves (for swarm intelligence), between a drone and an edge computing node (for immediate analytics), and for transmitting only processed insights back to a central server. This architecture relies on efficient, lightweight data exchange that datagrams inherently support, fostering more responsive and intelligent drone systems.

Swarm Robotics and Efficient Data Exchange
Swarm robotics, where multiple drones collaborate to achieve a common goal, is a major area of innovation. Coordinating these autonomous agents requires constant and efficient exchange of information—position, status, intent, and local sensor data. The connectionless, broadcast-friendly nature of datagrams, often facilitated by UDP, is an ideal mechanism for this high-frequency, many-to-many communication model. Each drone can broadcast its relevant state information as datagrams, allowing other drones in the swarm to quickly update their understanding of the collective environment without the overhead of establishing individual, persistent connections. This foundational element ensures that as drone swarms become more sophisticated, their communication backbone remains agile and scalable.
In conclusion, while “datagram” might sound like a purely theoretical networking concept, its practical implications are profoundly felt across the entire spectrum of drone technology and innovation. It is the invisible workhorse that enables real-time sensor data, responsive control, and the collaborative intelligence defining the next generation of autonomous flight. Understanding its fundamental properties—its independence, speed, and inherent trade-offs—is essential for anyone delving into the complexities and future potential of UAVs.