
Conditional statements are fundamental constructs in virtually every programming language, serving as the decision-making backbone for software applications. In the realm of drone technology and innovation, these statements are not just theoretical concepts; they are the critical enablers of autonomous flight, intelligent navigation, sophisticated data processing, and robust safety protocols. At their core, conditional statements allow a program to execute different blocks of code based on whether a specified condition evaluates to true or false. They imbue drones with the ability to perceive their environment, interpret data, and react intelligently without constant human intervention, transforming them from remote-controlled vehicles into autonomous, decision-making systems.
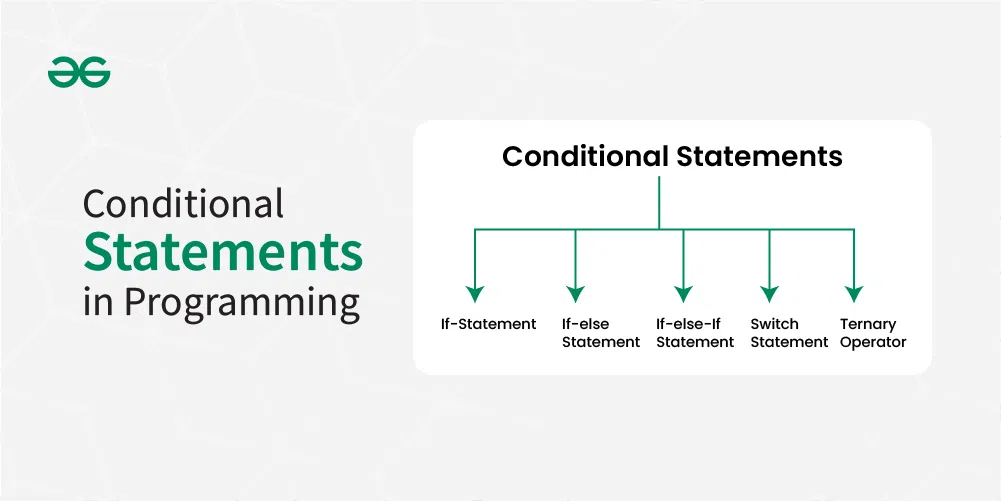
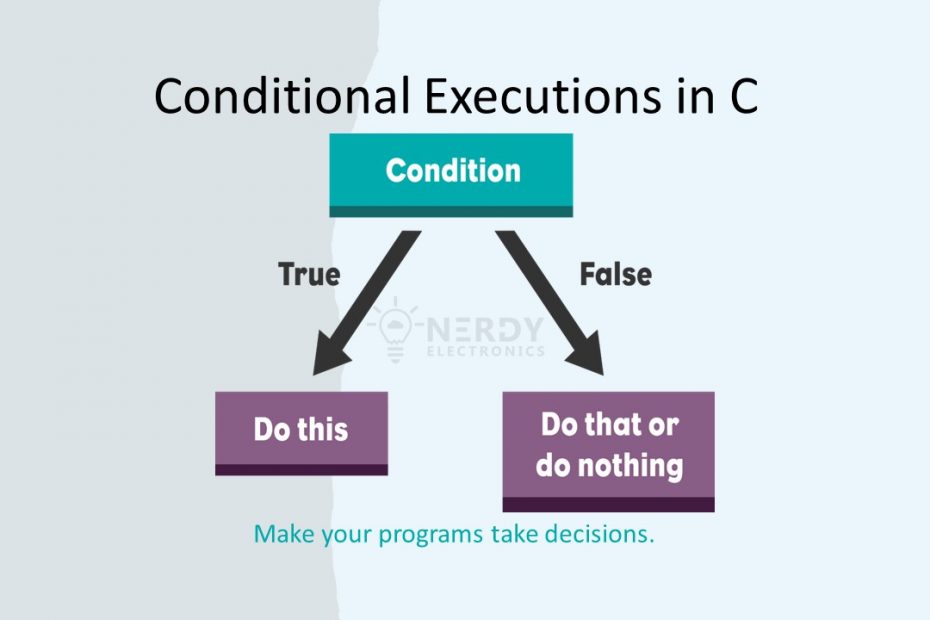
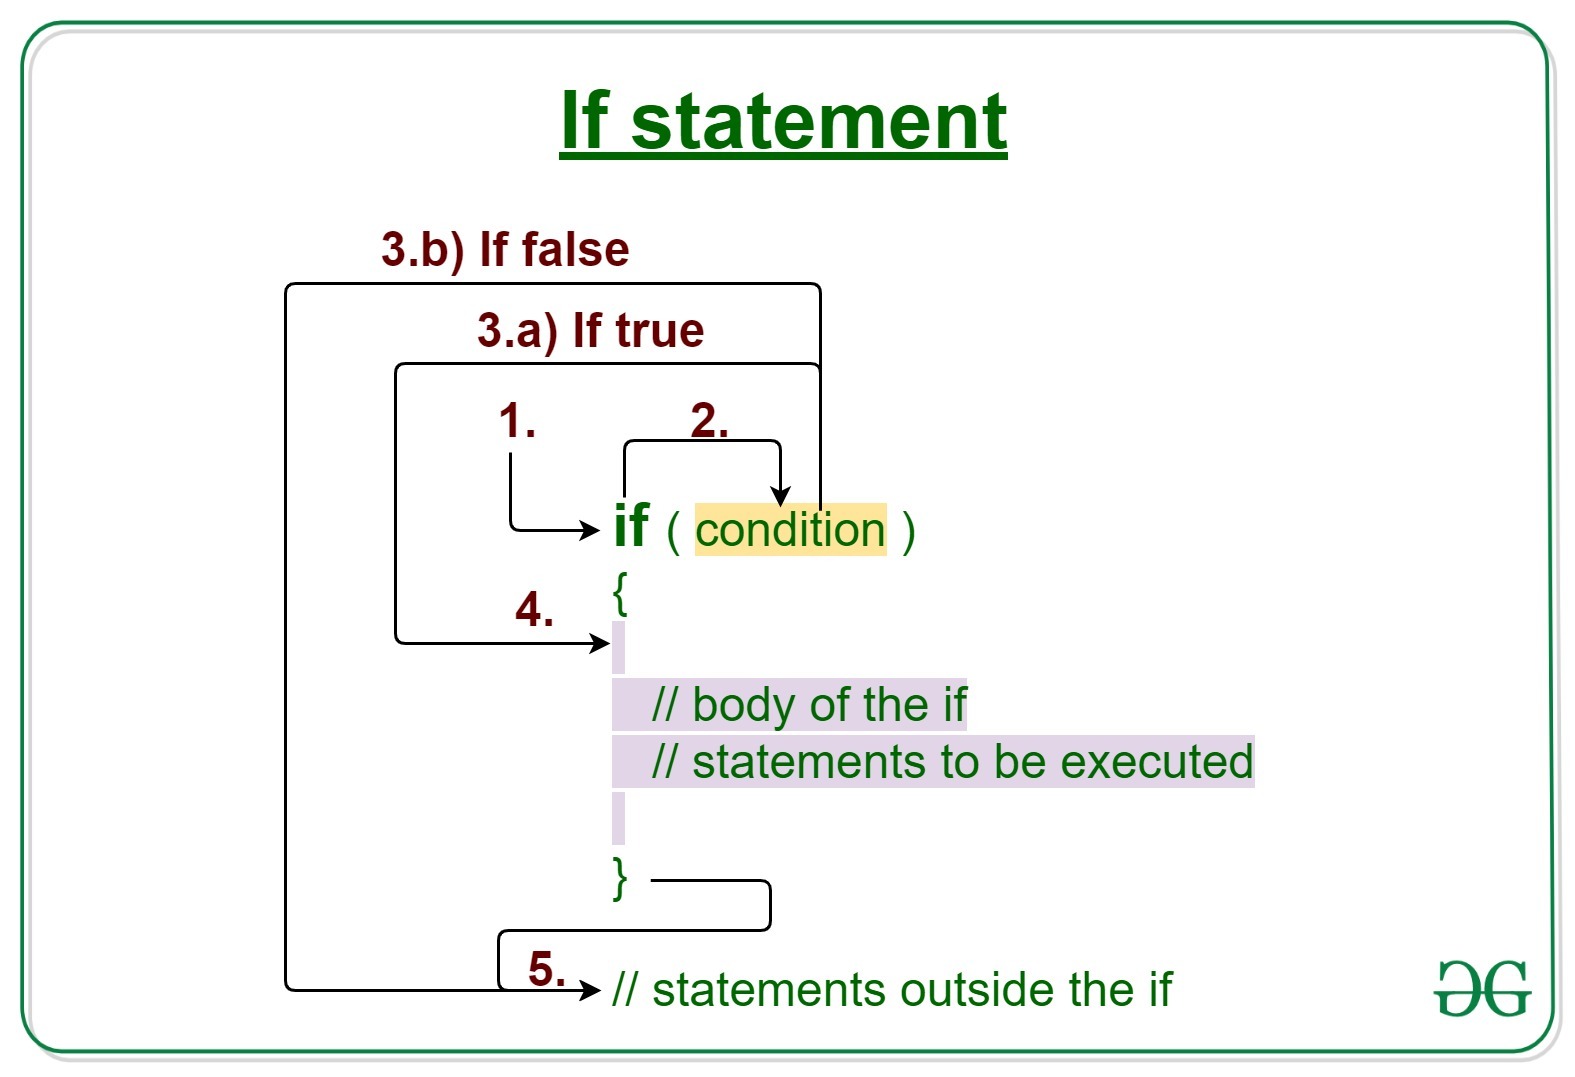
The most common forms of conditional statements are if, else if (or elif), and else. An if statement checks a condition; if it’s true, a specific set of instructions is carried out. If it’s false, the program can either proceed to the next instruction or check another condition using an else if statement. The else statement acts as a default, executing its block of code only if all preceding if and else if conditions prove false. This simple logical framework allows developers to script complex behavioral trees and sophisticated decision-making processes essential for the advanced capabilities seen in modern drones.
The Logic Gateways of Autonomous Flight
Autonomous flight, a cornerstone of drone innovation, relies heavily on conditional statements to navigate complex environments and execute predefined missions. Without the ability to make real-time decisions, a drone would merely follow a static, pre-programmed path, incapable of adapting to dynamic situations. Conditional logic provides the framework for these critical adaptations.
Basic Decision-Making in Drone Navigation
Consider a drone on a mapping mission. Its flight controller, powered by embedded software, constantly evaluates various parameters. A basic navigational decision might be: IF (battery_level < 20%) THEN (initiate_return_to_home_sequence). This simple conditional statement ensures the drone returns safely before power is completely depleted. Another vital decision involves obstacle avoidance: IF (front_sensor_detection == TRUE AND distance_to_obstacle < safe_threshold) THEN (initiate_evasive_maneuver) ELSE IF (alternative_path_clear == TRUE) THEN (divert_path) ELSE (hover_and_wait_for_operator_input). Here, a hierarchy of conditions dictates the drone’s reaction to an impending collision, demonstrating how else if and else clauses provide fallback options. Such logic is indispensable for drones operating in complex, unpredictable urban or natural environments.
Responding to Sensor Data
Modern drones are equipped with an array of sensors—GPS, accelerometers, gyroscopes, magnetometers, barometers, lidar, sonar, and vision cameras—each feeding vast amounts of data into the flight control system. Conditional statements are the interpreters of this data, enabling the drone to make sense of its surroundings. For instance, IF (GPS_signal_strength < minimum_threshold) THEN (switch_to_visual_inertial_navigation_system) ELSE (rely_on_GPS_for_positioning). This logic allows drones to seamlessly transition between navigation methods based on signal availability, maintaining precision even in GPS-denied environments. Similarly, IF (wind_speed > critical_limit AND current_altitude < safe_landing_altitude) THEN (initiate_emergency_landing_procedure) ELSE IF (wind_speed > acceptable_limit AND current_altitude > safe_landing_altitude) THEN (adjust_flight_parameters_for_stability_and_send_warning_to_operator). Such sophisticated sensor fusion and conditional responses are vital for operational safety and mission success.
Enabling Advanced Features: AI Follow Mode and Mapping
Beyond basic navigation, conditional statements underpin the more advanced, intelligent features that define drone innovation, such as AI Follow Mode and sophisticated mapping capabilities. These features require the drone to not just react, but to understand and predict, making conditional logic even more intricate.
Dynamic Target Tracking
AI Follow Mode, where a drone autonomously tracks a moving subject, is a prime example of complex conditional logic in action. The drone’s vision system continuously processes video feeds to identify and track the target. The core logic involves: IF (target_detected_in_frame == TRUE) THEN (calculate_target_position_and_velocity; adjust_drone_position_and_speed_to_maintain_optimal_distance) ELSE IF (target_temporarily_lost == TRUE AND search_timer < allowed_time) THEN (initiate_pattern_search_algorithm) ELSE (hover_and_await_new_target_or_operator_command). Within the adjust_drone_position_and_speed block, further nested conditional statements would fine-tune movements based on factors like target acceleration, obstacles in the drone’s path, or changes in lighting conditions affecting visual tracking. This dynamic interplay of conditions allows the drone to maintain cinematic shots while autonomously managing its flight path relative to the subject.
Data Collection and Analysis
For mapping and remote sensing applications, drones collect vast amounts of imagery and other sensor data. Conditional statements play a crucial role in optimizing this data collection and ensuring its quality. For example, in precision agriculture, a drone might be tasked with identifying areas of crop stress. The logic could involve: IF (spectral_signature_indicates_stress_level > threshold AND image_quality == high) THEN (mark_coordinates_for_further_analysis_and_apply_fertilizer_if_equipped) ELSE IF (spectral_signature_indicates_stress_level > threshold AND image_quality == low) THEN (re-fly_and_re-capture_area) ELSE (continue_mission_scan). This conditional approach ensures that actions are taken only when conditions are met and data quality is assured, leading to more efficient and accurate agricultural interventions or environmental monitoring. Advanced mapping algorithms also use conditionals to manage grid patterns, ensure overlapping images, and prevent data gaps: IF (current_position_within_survey_boundary == FALSE AND mission_complete == FALSE) THEN (adjust_path_to_stay_within_boundary) ELSE IF (current_position_within_survey_boundary == FALSE AND mission_complete == TRUE) THEN (initiate_return_to_home_sequence).
Safety, Reliability, and Error Handling
Innovation in drone technology also means prioritizing safety and reliability. Conditional statements are the bedrock of failsafe mechanisms and robust error handling, ensuring that drones can mitigate risks and respond gracefully to unexpected events or system failures.
Failsafe Protocols
Every advanced drone system incorporates multiple layers of failsafe protocols, all orchestrated by conditional logic. These protocols are designed to bring the drone to a safe state in critical situations. Examples include: IF (radio_link_lost_for > X_seconds) THEN (initiate_return_to_home_sequence_or_land_at_current_location). Another critical failsafe is power management: IF (motor_temperature > critical_limit AND flight_duration > safe_threshold) THEN (initiate_controlled_descent_and_shutdown). For redundant systems, conditions might dictate switching components: IF (primary_IMU_failure_detected == TRUE) THEN (switch_to_secondary_IMU). These conditional triggers are paramount for protecting the drone itself, its payload, and crucially, people and property on the ground.
System Diagnostics and Alerts
Conditional statements are also employed in continuous system diagnostics, monitoring the health and performance of various drone components. IF (propeller_speed_differential > acceptable_variance_threshold AND flight_mode == stabilized) THEN (log_propeller_imbalance_warning_and_notify_operator). This allows for proactive maintenance and prevents minor issues from escalating into critical failures. Furthermore, when anomalies are detected, conditional statements determine the appropriate alert level and action: IF (critical_system_error == TRUE) THEN (trigger_audible_alarm_and_force_landing) ELSE IF (minor_system_warning == TRUE) THEN (display_on_ground_station_and_log_for_review). This layered approach to diagnostics ensures operators are informed and can intervene effectively, or that the drone can autonomously manage lesser issues.
The Future of Drone Autonomy: Complex Conditional Hierarchies
As drone technology continues to evolve, the complexity and sophistication of conditional statements will grow, paving the way for even more advanced autonomous capabilities, including multi-agent collaboration and adaptive learning systems. The future of drone innovation hinges on increasingly intricate and dynamic decision-making trees.
Multi-Agent Collaboration
Consider a swarm of drones performing a complex task, such as search and rescue or large-scale construction. Their coordinated actions are governed by highly sophisticated conditional logic that enables them to communicate, share data, and adjust their behavior based on the status of other drones in the network. For instance: IF (drone_A_completes_its_assigned_area_scan == TRUE AND drone_B_available == TRUE) THEN (assign_drone_B_to_next_unscanned_sector) ELSE IF (drone_C_detects_a_hotspot == TRUE AND drone_D_equipped_with_extinguisher == TRUE) THEN (command_drone_D_to_hotspot_location_and_initiate_fire_suppression). These conditional hierarchies allow the swarm to operate as a single, intelligent entity, maximizing efficiency and effectiveness in complex missions.
Adaptive Learning Systems
The most innovative drone systems are moving towards incorporating machine learning and artificial intelligence, which themselves are built upon layers of conditional logic. While AI algorithms learn patterns, their operational deployment still relies on traditional conditional statements to trigger actions based on those learned patterns. For example, in an adaptive flight system: IF (AI_model_predicts_turbulence_ahead == TRUE AND current_flight_path_can_be_adjusted == TRUE) THEN (recalculate_smoother_flight_path) ELSE IF (AI_model_predicts_turbulence_ahead == TRUE AND no_alternative_path_available == TRUE) THEN (reduce_speed_and_increase_stabilization). These systems blend the predictive power of AI with the deterministic decision-making of conditional statements, allowing drones to learn from experience and adapt their behavior in real-time to optimize performance and safety. This continuous loop of sensing, evaluating conditions, acting, and learning represents the zenith of drone innovation driven by the humble yet powerful conditional statement.