
In the dynamic and rapidly evolving landscape of drone technology and innovation, rigorous scientific methodology is paramount for developing robust AI algorithms, perfecting autonomous flight, advancing mapping precision, and refining remote sensing capabilities. At the heart of such scientific rigor lies experimental design, and a critical component of effective design is the strategic use of “blocking variables.” Far from being a primary focus of an experiment, a blocking variable serves as a sophisticated tool to enhance the clarity and reliability of research findings by systematically accounting for factors that might otherwise obscure the true effects of interest.

The Core Concept of Blocking in Experimental Design
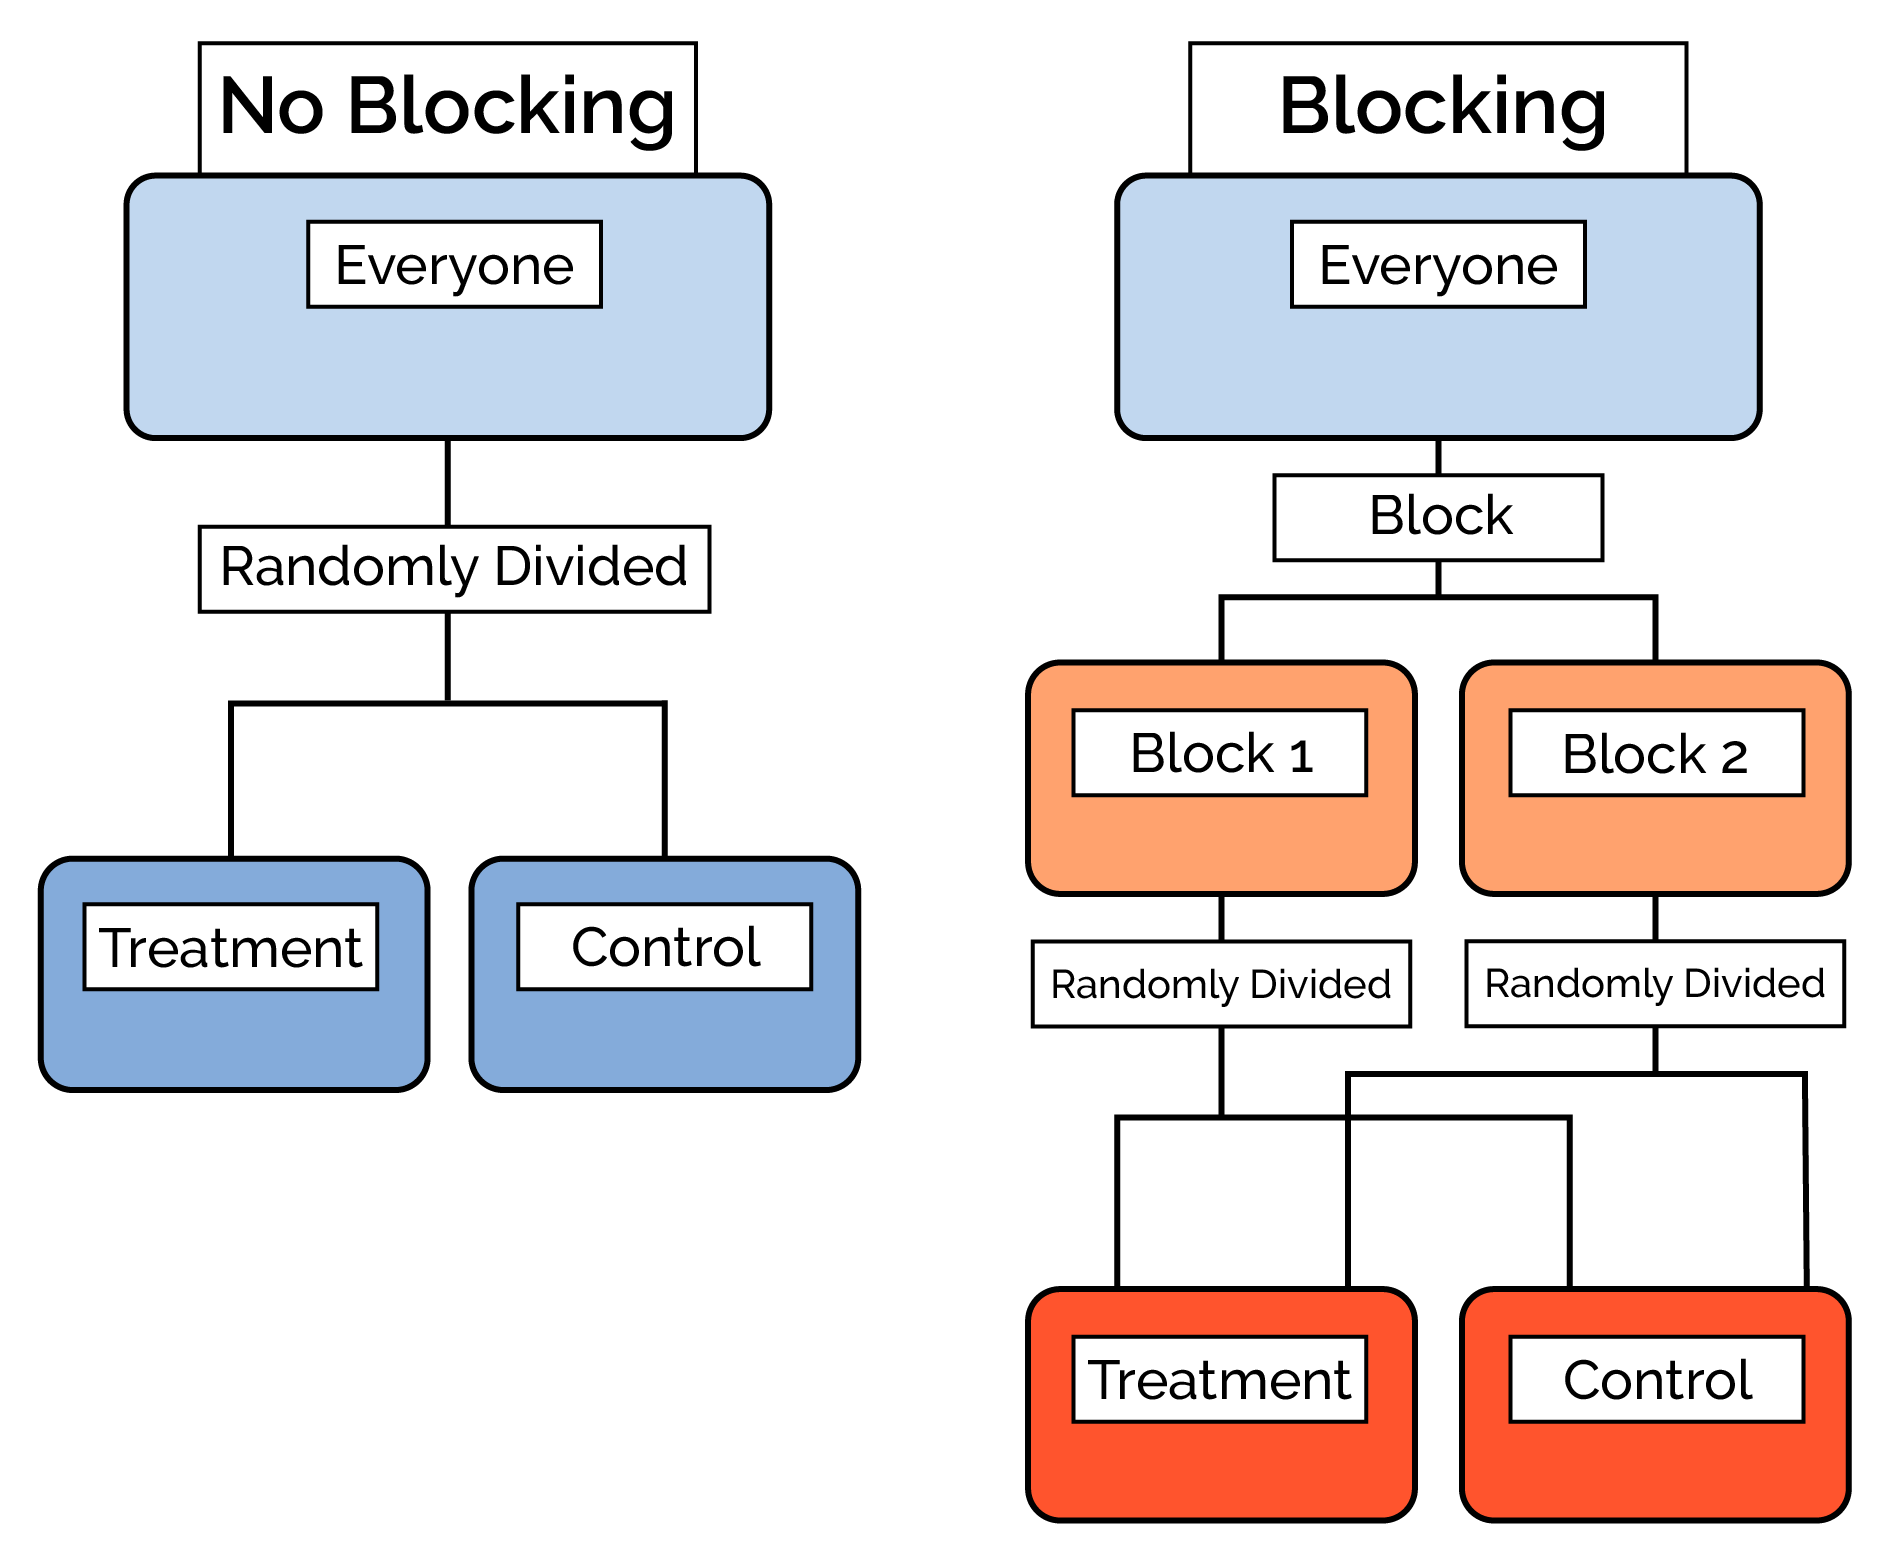
At its essence, a blocking variable is an extraneous factor that is not the primary independent variable being tested but is known or suspected to influence the dependent variable. In experimental design, blocking involves grouping experimental units (e.g., drone flight tests, sensor data collections) into homogeneous subsets, or “blocks,” based on the levels of this extraneous variable. The goal is not to study the effect of the blocking variable itself, but rather to minimize the variability it introduces into the experiment, thereby making it easier to detect the genuine effects of the variables under investigation.
Reducing Unwanted Variability
Imagine conducting an experiment to compare the accuracy of two different object detection algorithms for autonomous drone navigation. If this experiment were carried out across various environmental conditions—some flights on a clear, sunny day, others during overcast conditions, and still others at dusk—the variability in lighting could significantly impact the performance of both algorithms. If not accounted for, this environmental variability might be mistakenly attributed to differences between the algorithms, or worse, it might mask a real difference.
By treating “lighting conditions” as a blocking variable, researchers would ensure that each algorithm is tested under similar lighting conditions within each block. For instance, Block 1 might contain tests for both Algorithm A and Algorithm B under clear, sunny conditions. Block 2 would then contain tests for both under overcast conditions, and so on. This approach removes the influence of lighting conditions as a source of random error when comparing the algorithms, allowing for a more precise assessment of their inherent differences. It effectively isolates the treatment effect from the noise generated by a known, but uninteresting, nuisance factor.
Isolating True Effects
The ultimate aim of using blocking variables is to enhance statistical power—the ability of an experiment to detect a real effect if one exists. By reducing the “noise” or unexplained variance within the experimental data, blocking allows the “signal” (the effect of the primary independent variable) to stand out more clearly. This is particularly crucial in cutting-edge drone applications where differences in performance might be subtle but significant, such as minute improvements in GPS accuracy, slight enhancements in sensor fusion algorithms, or fractional increases in mapping resolution. Without blocking, these nuanced improvements might be drowned out by other uncontrolled factors, leading to inconclusive results or even erroneous conclusions.
Blocking Variables in Drone-Based Remote Sensing and Mapping
The application of blocking variables is profoundly relevant in drone-based remote sensing and mapping, where data collection is subject to a multitude of environmental and operational factors. Innovators developing new hyperspectral sensors, refining photogrammetry techniques, or creating advanced vegetation indices often rely on blocking to ensure their findings are robust and generalizable.
Environmental Factors as Blocking Variables
Consider an agricultural remote sensing project comparing the efficacy of two new drone-mounted multispectral sensors for detecting early signs of crop disease. Numerous environmental factors could influence sensor readings and the manifestation of disease symptoms:
- Time of Day: Sunlight angle and intensity change throughout the day, affecting illumination and spectral reflectance. Blocking by “time of day” ensures that comparisons between sensors are made under similar lighting, preventing diurnal variations from confounding the results.
- Weather Conditions: Cloud cover, ambient temperature, humidity, and even recent rainfall can alter vegetation spectral signatures and sensor performance. Researchers might block by “weather condition categories” (e.g., clear, partly cloudy, overcast) to control for these influences.
- Soil Type/Topography: Different soil compositions or variations in terrain elevation can impact crop growth and water retention, thereby affecting sensor readings. If the experiment spans diverse fields, “soil type” or “topographic zone” could serve as a blocking variable.
By carefully grouping sensor tests by these environmental blocks, researchers can isolate the true differences in performance between the new sensors, obtaining a clearer picture of their capabilities and limitations in real-world agricultural scenarios.
Equipment and Platform Homogenization
Beyond environmental influences, the equipment and platforms themselves can introduce variability. When developing or testing new mapping algorithms that process drone-collected imagery to generate 3D models or orthomosaics, the performance might be influenced by the specific drone platform or camera lens used.
- Drone Platform Model: Different drone models might have slightly varied flight characteristics, vibration profiles, or GPS receiver qualities. If an experiment needs to compare mapping software across different hardware, using “drone model” as a blocking variable ensures that each software is tested on each relevant drone platform, effectively controlling for platform-specific biases.
- Camera Lens/Sensor Unit: Even within the same camera model, individual lenses or sensor units can have subtle manufacturing variations. If an experiment involves multiple cameras or interchangeable lenses, “specific lens serial number” or “sensor unit ID” could be used as a blocking variable to account for these nuances, particularly when fine-tuning calibration parameters or assessing pixel-level accuracy.
This careful control allows innovators to precisely evaluate the performance of their mapping algorithms or remote sensing payloads, ensuring that observed differences are attributable to the innovation itself, not to uncontrolled variations in the data collection apparatus.
Enhancing AI and Autonomous Flight System Development
The development and validation of sophisticated AI capabilities and autonomous flight systems represent another critical domain where blocking variables are indispensable. When pushing the boundaries of machine learning for drone applications—such as AI follow mode, intelligent obstacle avoidance, or fully autonomous mission planning—rigorous testing is essential.
Testing AI Follow Modes
Consider the development of an advanced AI follow mode, designed to track moving subjects accurately. The performance of such an algorithm can be highly dependent on various factors unrelated to the core AI logic itself:
- Subject Characteristics: The size, speed, color, and texture of the subject being followed can all influence the AI’s detection and tracking accuracy. If the experiment aims to compare two different AI tracking algorithms, “subject type” (e.g., human runner, cyclist, small vehicle) would be an excellent blocking variable. Each algorithm would be tested tracking each subject type, ensuring that comparisons are fair and not skewed by an algorithm’s fortuitous performance on a particular subject.
- Background Clutter: The complexity of the environment behind the subject can also affect tracking. A subject moving against a clear sky is easier to track than one moving through dense foliage or an urban street. “Background environment” (e.g., open field, forest edge, urban street) could be used as a blocking variable, ensuring algorithms are benchmarked fairly across different levels of visual distraction.
- Lighting Conditions: As with remote sensing, varying light levels—bright sunlight, deep shadows, low light—can significantly impact computer vision algorithms. Blocking by “lighting conditions” ensures a comprehensive and unbiased assessment of the AI’s robustness.
Validating Autonomous Navigation Algorithms
For autonomous flight systems, testing the reliability and efficiency of new navigation algorithms is paramount. These algorithms often need to perform reliably across a spectrum of challenging conditions.
- Obstacle Density/Type: An algorithm’s ability to navigate an obstacle course might depend on the number, size, and nature of the obstacles. When comparing two new obstacle avoidance algorithms, “obstacle density level” (e.g., sparse, moderate, dense) or “obstacle type category” (e.g., trees, buildings, power lines) could be used as blocking variables. This ensures that each algorithm is evaluated fairly under identical obstacle challenges within each block.
- GPS Signal Availability/Interference: The integrity of GPS signals can vary significantly depending on location (e.g., open sky vs. urban canyons) or presence of jamming/spoofing attempts. “GPS signal quality environment” (e.g., strong, moderate, weak, simulated interference) could be a crucial blocking variable when testing navigation resilience or alternative positioning systems.
- Wind Conditions: Autonomous flight stability and energy consumption are directly affected by wind. When evaluating new flight control algorithms or energy-efficient flight paths, “wind speed category” (e.g., calm, light breeze, moderate wind) or “wind direction relative to flight path” could be used as blocking variables to account for these aerodynamic influences.
By carefully integrating blocking variables into their experimental designs, developers can gain clearer, more actionable insights into the true performance and limitations of their AI and autonomous systems, accelerating the pace of innovation and ensuring the safety and reliability of future drone operations.
Best Practices and Considerations for Drone Tech Innovators
While the concept of blocking is powerful, its effective implementation requires careful thought and strategic planning. Drone tech innovators must adopt best practices to maximize the benefits of this experimental design technique.
Identifying Potential Confounders
The first step is a thorough understanding of the experimental context and an educated guess about potential confounding factors. This often comes from preliminary studies, expert knowledge, or pilot experiments. For instance, before testing a new thermal camera for search and rescue, researchers might conduct reconnaissance flights to understand how ambient temperature, ground cover, and time of day affect heat signatures, thereby identifying these as potential blocking variables. Neglecting to identify a significant blocking variable can lead to reduced statistical power and potentially misleading conclusions, despite other aspects of the design being sound.
Designing Effective Blocks
Once identified, blocking variables must be incorporated into the experimental design logically. This means ensuring that each block is as homogeneous as possible with respect to the blocking variable, while allowing for the variation of the primary independent variable within each block. For example, if “drone operator experience” is a blocking variable for testing a new intuitive flight controller, each block would consist of operators with similar experience levels (e.g., Novice Block, Intermediate Block, Expert Block). Within each of these blocks, both the new and standard flight controllers would be tested by different operators from that specific experience level. This ensures a fair comparison, as any differences observed are less likely to be due to operator skill.

The Impact on Data Interpretation
The use of blocking variables fundamentally changes how data are analyzed and interpreted. Statistical analysis methods appropriate for blocked designs (e.g., analysis of variance with blocks as a factor) are necessary. The results will often show that the blocking variable accounts for a significant portion of the total variability, thereby reducing the error term and making the effects of the treatment variables clearer. Interpreters must remember that the block effect itself is typically not of primary interest; rather, it is a mechanism to sharpen the focus on the variables that are of interest.
In conclusion, as drone technology continues its rapid advancement, moving into more complex autonomous operations, sophisticated data acquisition, and intelligent decision-making, the reliance on rigorous experimental validation will only grow. Blocking variables are an indispensable tool in this validation process, enabling innovators to tease apart complex interactions, minimize experimental noise, and build a foundation of reliable knowledge. By embracing this fundamental principle of experimental design, the drone community can ensure that its innovations are not only ground-breaking but also thoroughly tested, robust, and truly effective in the real world.